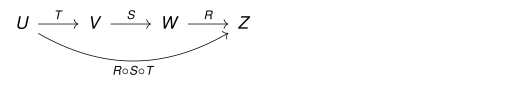Note to Student: In this section we will often use \(U\), \(V\) and \(W\) to denote subspaces of \(\RR ^n\), or any other finite-dimensional vector space,
such as those we study in Vector Spaces.
Let
\(U\),
\(V\) and
\(W\) be vector spaces, and let
\(T:U\rightarrow V\) and
\(S:V\rightarrow W\) be linear transformations. The
composition of
\(S\) and
\(T\) is the transformation
\(S\circ T:U\rightarrow W\) given
by
\[(S\circ T)(\vec {u})=S(T(\vec {u}))\]
Define
\[T:\RR ^2\rightarrow \RR ^2 \quad \text {by}\quad T\left (\begin{bmatrix}u_1\\u_2\end{bmatrix}\right )=\begin{bmatrix}u_1+u_2\\3u_1+3u_2\end{bmatrix}\]
\[S:\RR ^2\rightarrow \RR ^2 \quad \text {by}\quad S\left (\begin{bmatrix}v_1\\v_2\end{bmatrix}\right )=\begin{bmatrix}3v_1-v_2\\-3v_1+v_2\end{bmatrix}\]
(You should be able to verify that both transformations are linear.) Examine the effect of
\(S\circ T\) on vectors of
\(\RR ^2\).
From the
computational standpoint, the situation is simple.
\begin{align*} (S\circ T)\left (\begin{bmatrix}u_1\\u_2\end{bmatrix}\right )&=S\left (T\left (\begin{bmatrix}u_1\\u_2\end{bmatrix}\right )\right )=S\left (\begin{bmatrix}u_1+u_2\\3u_1+3u_2\end{bmatrix}\right )\\ &=\begin{bmatrix}3(u_1+u_2)-(3u_1+3u_2)\\-3(u_1+u_2)+(3u_1+3u_2)\end{bmatrix}\\ &=\vec {0} \end{align*}
This means that \(S\circ T\) maps all vectors of \(\RR ^2\) to \(\vec {0}\).
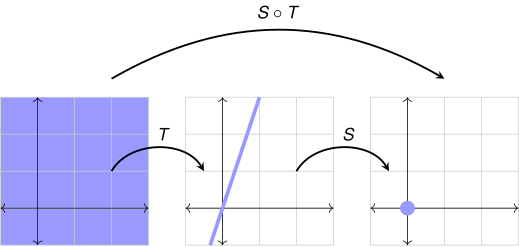
In addition to the computational approach, it is also useful to visualize what happens geometrically.
First, observe that
\[T\left (\begin{bmatrix}u_1\\u_2\end{bmatrix}\right )=\begin{bmatrix}u_1+u_2\\3u_1+3u_2\end{bmatrix}=(u_1+u_2)\begin{bmatrix}1\\3\end{bmatrix}\]
Therefore the image of any vector of
\(\RR ^2\) under
\(T\) lies on the line determined by the vector
\(\begin{bmatrix}1\\3\end{bmatrix}\).
Even though \(S\) is defined on all of \(\RR ^2\), we are only interested in the action of \(S\) on vectors along the line determined by \(\begin{bmatrix}1\\3\end{bmatrix}\). Our
computations showed that all such vectors map to \(\vec {0}\).
The actions of individual transformations, as well as the composite transformation are shown below.
The composition of two linear transformations is linear.
Let \(T:U\rightarrow V\) and \(S:V\rightarrow W\) be linear transformations. We will show that \(S\circ T\) is linear. For all vectors \(\vec {u}_1\) and \(\vec {u}_2\) of \(U\) and scalars \(a\) and \(b\) we have:
\begin{align*} (S\circ T)(a\vec {u}_1+b\vec {u}_2)&=S(T(a\vec {u}_1+b\vec {u}_2))\\ &=S(aT(\vec {u}_1)+bT(\vec {u}_2))\\ &=aS(T(\vec {u}_1))+bS(T(\vec {u}_2))\\ &=a(S\circ T)(\vec {u}_1)+b(S\circ T)(\vec {u}_2) \end{align*}
Composition of linear transformations is associative. In other words, for linear transformations
\(T\),
\(S\) and
\(R\)
We have \((R\circ S)\circ T=R\circ (S\circ T)\).
For all \(\vec {u}\) in \(U\) we have:
\begin{align*} ((R\circ S)\circ T)(\vec {u})&=(R\circ S)(T(\vec {u}))=R(S(T(\vec {u})))\\ &=R((S\circ T)(\vec {u}))=(R\circ (S\circ T))(\vec {u}) \end{align*}
Composition and Matrix Multiplication
In this section we will consider linear transformations of \(\RR ^n\) and their standard matrices.
Let
\(T:\RR ^n\rightarrow \RR ^m\) and
\(S:\RR ^m\rightarrow \RR ^p\) be linear transformations with standard matrices
\(M_T\) and
\(M_S\), respectively. Then the composite transformation
\(S\circ T:\RR ^n\rightarrow \RR ^p\) has a
standard matrix given by the product
\(M_SM_T\).
For all \(\vec {v}\) in \(\RR ^n\) we have:
\[(S\circ T)(\vec {v})=S(T(\vec {v}))=S(M_T\vec {v})=M_S(M_T\vec {v})=(M_SM_T)\vec {v}\]
In Example
2, we discussed a composite transformation
\(S\circ T:\RR ^2\rightarrow \RR ^2\) given by:
\[T\left (\begin{bmatrix}u_1\\u_2\end{bmatrix}\right )=\begin{bmatrix}u_1+u_2\\3u_1+3u_2\end{bmatrix}\quad \text {and} \quad S\left (\begin{bmatrix}v_1\\v_2\end{bmatrix}\right )=\begin{bmatrix}3v_1-v_2\\-3v_1+v_2\end{bmatrix}\]
Express
\(S\circ T\) as a matrix transformation.
The standard matrix for
\(T:\RR ^2\rightarrow \RR ^2\) is
\[\begin{bmatrix}1&1\\3&3\end{bmatrix}\]
and the standard matrix for
\(S:\RR ^2\rightarrow \RR ^2\) is
\[\begin{bmatrix}3&-1\\-3&1\end{bmatrix}\]
The standard matrix for
\(S\circ T\) is the product
\[\begin{bmatrix}3&-1\\-3&1\end{bmatrix}\begin{bmatrix}1&1\\3&3\end{bmatrix}=\begin{bmatrix}0&0\\0&0\end{bmatrix}\]
We conclude this section by revisiting the associative property of matrix multiplication. At the time matrix multiplication was
introduced, we skipped the cumbersome proof that for appropriately sized matrices \(A\), \(B\) and \(C\), we have \((AB)C=A(BC)\). (See Theorem ??.) We
are now in a position to prove this result with ease.
Every matrix induces a linear transformation. The product of two matrices can be interpreted as a composition of
transformations. Since function composition is associative, so is matrix multiplication. We formalize this observation as a
theorem.
Associativity of Matrix Multiplication Let
\(A\),
\(B\) and
\(C\) be matrices of appropriate dimensions so that the product
\((AB)C\) is defined.
Then
\[(AB)C=A(BC)\]
Define a linear transformation
\(T:\RR ^2\rightarrow \RR ^2\) by
\(T(\vec {v})=2\vec {v}\). In other words,
\(T\) doubles every vector in
\(\RR ^2\). Now define
\(S:\RR ^2\rightarrow \RR ^2\) by
\(S(\vec {v})=\frac {1}{2}\vec {v}\). What happens when we
compose these two transformations?
\[(S\circ T)(\vec {v})=S(T(\vec {v}))=S(2\vec {v})=\left (\frac {1}{2}\right )(2)\vec {v}=\vec {v}\]
\[(T\circ S)(\vec {v})=T(S(\vec {v}))=T(\frac {1}{2}\vec {v})=(2)\left (\frac {1}{2}\right )\vec {v}=\vec {v}\]
Both composite transformations return the original vector
\(\vec {v}\). In other words,
\(S\circ T=\id _{\RR ^2}\) and
\(T\circ S=\id _{\RR ^2}\). We say that
\(S\) is an
inverse of
\(T\), and
\(T\) is an
inverse of
\(S\).
Let
\(V\) and
\(W\) be vector spaces, and let
\(T:V\rightarrow W\) be a linear transformation. A transformation
\(S:W\rightarrow V\) that satisfies
\(S\circ T=\id _V\) and
\(T\circ S=\id _W\) is called an
inverse of
\(T\). If
\(T\)
has an inverse,
\(T\) is called
invertible.
Let
\(T:\RR ^2\rightarrow \RR ^2\) be a transformation defined by
\(T\left (\begin{bmatrix}x\\y\end{bmatrix}\right )=\begin{bmatrix}x+y\\x-y\end{bmatrix}\). (How would you verify that
\(T\) is linear?) Show that
\(S:\RR ^2\rightarrow \RR ^2\) given by
\(S\left (\begin{bmatrix}x\\y\end{bmatrix}\right )=\begin{bmatrix}0.5x+0.5y\\0.5x-0.5y\end{bmatrix}\) is an inverse of
\(T\).
We will
show that
\(S\circ T=\id _{\RR ^2}\).
\begin{align*} (S\circ T)\left (\begin{bmatrix}x\\y\end{bmatrix}\right )&=S\left (T\left (\begin{bmatrix}x\\y\end{bmatrix}\right )\right )=S\left (\begin{bmatrix}x+y\\x-y\end{bmatrix}\right )\\ &=\begin{bmatrix}0.5(x+y)+0.5(x-y)\\0.5(x+y)-0.5(x-y)\end{bmatrix} =\begin{bmatrix}x\\y\end{bmatrix} \end{align*}
We leave it to the reader to verify that \(T\circ S=\id _{\RR ^2}\).
Definition 13 does not specifically require an inverse \(S\) of a linear transformation \(T\) to be linear, but it turns out that the
requirement that \(S\circ T=\id _V\) and \(T\circ S=\id _W\) is sufficient to guarantee that \(S\) is linear.
Suppose
\(T:V\rightarrow W\) is an invertible linear transformation. Let
\(S\) be an inverse of
\(T\). Then
\(S\) is linear.
The proof of this result is left to the reader. (See Practice Problem ??)
Every linear transformation \(T:\RR ^n\rightarrow \RR ^m\) is a matrix transformation. (See Theorem ??.) If \(T\) has an inverse \(S\), then by Theorem
16, \(S\) is also a matrix transformation. Let \(M_T\) and \(M_S\) denote the standard matrices of \(T\) and \(S\), respectively. We see
that \(S\circ T=\id _{\RR ^n}\) and \(T\circ S=\id _{\RR ^m}\) if and only if \(M_SM_T=I_{n}\) and \(M_TM_S=I_{m}\). In other words, \(T\) and \(S\) are inverse transformations if and only if \(M_T\) and \(M_S\) are matrix
inverses.
Note that if \(S\) is an inverse of \(T\), then \(M_T\) and \(M_S\) are square matrices, and \(n=m\).
Let
\(T:\RR ^n\rightarrow \RR ^n\) be a linear transformation, and let
\(M\) be the standard matrix of
\(T\).
-
1.
- (Existence of Inverses.) \(T\) is invertible if and only if \(M\) is invertible. If \(T\) is invertible, then the inverse is induced by \(M^{-1}\).
-
2.
- (Uniqueness of Inverses.) If \(S\) is an inverse of \(T\), then \(S\) is unique.
Part 1 follows directly from the preceding discussion. Part 2 follows from uniqueness of matrix inverses. (Theorem ??.)
Please note that Theorem 18 is only applicable in the context of linear transformations of \(\RR ^n\) and their standard matrices. The
following example provides us with motivation to investigate inverses further, which we will do in Existence of the Inverse of a
Linear Transformation.
Let
\[V=\text {span}\left (\begin{bmatrix}1\\0\\0\end{bmatrix}, \begin{bmatrix}1\\1\\1\end{bmatrix}\right )\]
Define a linear transformation
\[T:V\rightarrow \RR ^2\]
by
\[T\left (\begin{bmatrix}1\\0\\0\end{bmatrix}\right )=\begin{bmatrix}1\\1\end{bmatrix}\quad \text {and} \quad T\left (\begin{bmatrix}1\\1\\1\end{bmatrix}\right )=\begin{bmatrix}0\\1\end{bmatrix}\]
Observe that
\(\left \{\begin{bmatrix}1\\0\\0\end{bmatrix}, \begin{bmatrix}1\\1\\1\end{bmatrix}\right \}\) is a basis of
\(V\) (why?). The information about the images of the basis vectors is sufficient to define a linear
transformation. This is because every vector
\(\vec {v}\) in
\(V\) can be expressed as a linear combination of the basis elements in a unique
way. The image,
\(T(\vec {v})\), can be found by applying the linearity properties. At this point we know what transformation
\(T\) does, but it is
still unclear what the matrix of this linear transformation is.
Geometrically speaking, the domain of \(T\) is a plane in \(\RR ^3\) and its codomain is \(\RR ^2\).
Does \(T\) have an inverse? We are not in a position to answer this question right now because Theorem 18 does not apply to this
situation.
Exploration highlights the necessity of further discussion of inverses and of matrices associated with linear
transformations. In Example ??, we will prove that \(T\) has an inverse, and in Example ??, we will address the issue of matrices
associated with \(T\) and its inverse.
Practice Problems
Let
\(T:\RR ^2\rightarrow \RR ^2\) and
\(S:\RR ^2\rightarrow \RR ^2\) be linear transformations with standard matrices
\[M_T=\begin{bmatrix}2&-4\\1&2\end{bmatrix}\quad \text {and}\quad M_S=\begin{bmatrix}1&-1\\2&1\end{bmatrix}\]
respectively. Describe the actions of
\(T\),
\(S\), and
\(S\circ T\) geometrically, as in Example
2.
Let
\(T:\RR ^3\rightarrow \RR ^2\) and
\(S:\RR ^2\rightarrow \RR ^2\) be linear transformations with standard matrices
\[M_T=\begin{bmatrix}1&0&-1\\2&1&0\end{bmatrix}\quad \text {and}\quad M_S=\begin{bmatrix}-1&2\\1&-2\end{bmatrix}\]
respectively. Describe the actions of
\(T\),
\(S\), and
\(S\circ T\) geometrically, as in Example
2.
Complete the Explanation of Example
14 by verifying that
\(T\circ S=\id _{\RR ^2}\).
Let
\(T:\RR ^2\rightarrow \RR ^2\) be a linear transformation given by
\[T\left (\begin{bmatrix}x\\y\end{bmatrix}\right )=\begin{bmatrix}2x-5y\\-x+3y\end{bmatrix}\]
Propose a candidate for the inverse of
\(T\) and verify your choice using Definition
13.
\[T^{-1}\left (\begin{bmatrix}x\\y\end{bmatrix}\right )=\begin{bmatrix}\answer {3}x+\answer {5}y\\x+\answer {2}y\end{bmatrix}\]
Explain why linear transformation
\(T:\RR ^2\rightarrow \RR ^2\) given by
\[T\left (\begin{bmatrix}x\\y\end{bmatrix}\right )=\begin{bmatrix}2x+2y\\-3x-3y\end{bmatrix}\]
does not have an inverse.
Suppose
\(T:U\rightarrow V\) and
\(S:V\rightarrow W\) are linear transformations with inverses
\(T'\) and
\(S'\) respectively. Prove that
\(T'\circ S'\) is the inverse of
\(S\circ T\).