Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
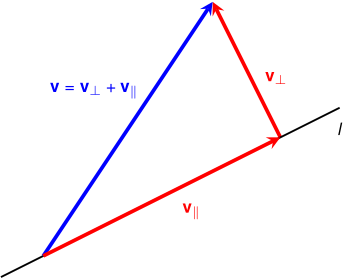
Given a line \(l\) and a vector \(\vec {v}\) emanating from a point on \(l\), it is sometimes convenient to express \(\vec {v}\) as the sum of a vector \(\vec {v}_{\parallel }\),
parallel to \(l\), and a vector \(\vec {v}_{\perp }\), perpendicular to \(l\). If you have taken a physics course, you may have seen a force
vector decomposed into the sum of two components: one parallel and one perpendicular to the direction of
motion.
Suppose \(\vec {d}\) is a direction vector for \(l\). Then \(\vec {v}_ {\parallel }=k\vec {d}\) for some scalar \(k\). Our goal is to find \(k\).
The vector \(\vec {v}_{\parallel }=\left (\frac {\vec {v}\dotp \vec {d}}{\norm {\vec {d}}^2}\right )\vec {d}\) is called the projection of \(\vec {v}\) onto \(\vec {d}\). In our discussion, \(\vec {d}\) is a direction vector for line \(l\). So, we can also say that \(\vec {v}_{\parallel }\) is the
projection of \(\vec {v}\) onto \(l\).
To find \(\vec {v}_{\perp }\), observe that \(\vec {v}_{\perp }=\vec {v}-\vec {v}_{\parallel }\).
Let \(\vec {v}\) be a vector, and let \(\vec {d}\) be a non-zero vector. The projection of \(\vec {v}\) onto \(\vec {d}\) is given by
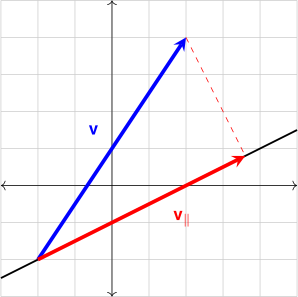
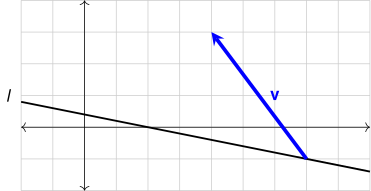
Find the projection of \(\vec {v}\), shown below, onto the line given by \(y=\frac {1}{2}x-1\).
We begin by finding vectors \(\vec {v}\) and \(\vec {d}\). The tail of \(\vec {v}\) is located at \((-2, -2)\), and the head of \(\vec {v}\) is at \((2, 4)\). Using the “head-tail" formula we
get
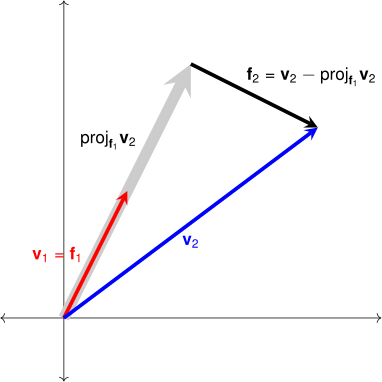
Given an arbitrary basis \(\{\vec {v}_1, \vec {v}_2\}\) of \(\RR ^2\), let’s start building our orthogonal basis, \(\{\vec {f}_1, \vec {f}_2\}\), by setting \(\vec {f}_1 = \vec {v}_1\). To find the next element of our orthogonal
basis, consider the orthogonal projection of \(\vec {v}_2\) onto \(\vec {f}_1\). (See the figure below.)
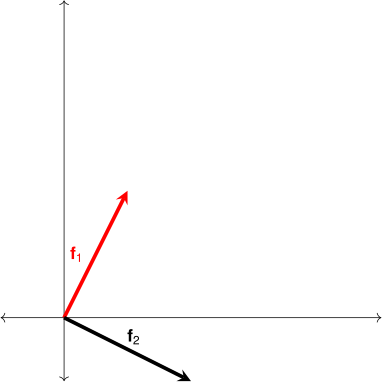
Next, let \(\vec {f}_2=\vec {v}_2-\mbox {proj}_{\vec {f}_1}\vec {v}_2\). Observe that \(\vec {f}_2\) is orthogonal to \(\vec {f}_1\) (See Theorem ?? of Orthogonality and Projections). This gives us an
orthogonal collection \(\mathcal {B}=\{\vec {f}_1,\vec {f}_2\}\). It is intuitively clear that \(\vec {f}_1\) and \(\vec {f}_2\) are linearly independent. Therefore \(\mathcal {B}\) is an orthogonal basis of
\(\RR ^2\).
The following exploration illustrates this process dynamically.
Choose an arbitrary basis \(\{\vec {v}_1, \vec {v}_2\}\) of \(\RR ^2\) by dragging the tips of vectors \(\vec {v}_1\) and \(\vec {v}_2\) to desired positions. Use the navigation
bar at the bottom of the interactive window to go through the steps of constructing an orthogonal basis of
\(\RR ^2\).
We can apply this process to any two-dimensional subset of \(\RR ^n\). The following exploration will guide you through the process of
constructing an orthogonal basis for a plane spanned by two arbitrary vectors in \(\RR ^3\).
Let \(W =\mbox {span}\left ({\bf v}_1,{\bf v}_2\right )\). \(W\) is a plane through the origin in \(\RR ^3\). Use the navigation bar at the bottom of the interactive window to go through
the steps of constructing an orthogonal basis for \(W\). RIGHT-CLICK and DRAG to rotate the image for a better
view.
In the next exploration, we take the process of constructing an orthogonal basis to the edge of the visual realm and construct
an orthogonal basis for \(\RR ^3\).
In the GeoGebra interactive below \(\{\vec {v}_1, \vec {v}_2, \vec {v}_3\}\) is a basis of \(\RR ^3\). Use check boxes to go through the steps for constructing
an orthogonal basis starting with the given basis. RIGHT-CLICK and DRAG to rotate the image for a better
view.
What we saw above are low-dimension examples of what is known as Gram Schmidt Orthogonalization.
Practice Problems
Find \(\mbox {proj}_{\vec {d}}\vec {v}\) if \(\vec {d}=\begin{bmatrix}-1\\3\end{bmatrix}\) and \(\vec {v}=\begin{bmatrix}1\\4\end{bmatrix}\).
Show that \(\mbox {proj}_{\vec {d}}\vec {v}\) does not depend on the length of \(\vec {d}\) by proving that \(\mbox {proj}_{\vec {d}}\vec {v}=\mbox {proj}_{k\vec {d}}\vec {v}\) for \(k\neq 0\). What does this result mean geometrically? Illustrate your
response with a diagram.
Find the projection of vector \(\vec {v}\) onto line \(l\). (If entering answers in decimal form, round to the nearest one hundredth.)
Convert the given basis \(\mathcal {B}\) of \(\RR ^2\) to an orthogonal basis by following the procedure described in this section with
\(\vec {v}_1=\begin{bmatrix}2\\ 1\end{bmatrix}\).
 Week 12