Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
Recall that a transformation \(T:\mathbb {R}^n\rightarrow \mathbb {R}^m\) is called a linear transformation if the following are true for all vectors \(\bf u\) and \(\bf v\) in \(\mathbb {R}^n\), and scalars \(k\).
Let \(V\) and \(W\) be vector spaces. A transformation \(T:V\rightarrow W\) is called a linear transformation if the following are true for all vectors \(\bf u\) and \(\bf v\) in \(V\),
and scalars \(k\).
Transformations that map vectors to their coordinate vectors with respect to some ordered basis will prove to be of great
importance. We will start by showing that such transformations are linear.
If \(V\) is a vector space, and \(\mathcal {B}=\{\vec {v}_1, \ldots ,\vec {v}_n\}\) is an ordered basis for \(V\) then any vector \(\vec {v}\) of \(V\) can be uniquely expressed as \(\vec {v}=a_1\vec {v}_1+\ldots +a_n\vec {v}_n\) for some scalars \(a_1, \ldots ,a_n\). Vector \([\vec {v}]_{\mathcal {B}}\)
in \(\RR ^n\) given by
is said to be the coordinate vector for \(\vec {v}\) with respect to the ordered basis \(\mathcal {B}\). (See Definition ??.)
It turns out that the transformation \(T:V\rightarrow \RR ^n\) defined by \(T(\vec {v})=[\vec {v}]_{\mathcal {B}}\) is linear. Before we prove linearity of \(T\), consider the following
example.
Let \(\mathcal {B}=\left \{\begin{bmatrix}1&0\\0&0\end{bmatrix}, \begin{bmatrix}0&1\\0&0\end{bmatrix}, \begin{bmatrix}0&0\\1&0\end{bmatrix}, \begin{bmatrix}0&0\\0&1\end{bmatrix}\right \}\) be an ordered basis for \(\mathbb {M}_{2,2}\). (You should do a quick mental check that \(\mathcal {B}\) is a legitimate basis.) Define \(T:\mathbb {M}_{2,2}\rightarrow \RR ^4\) by \(T(A)=[A]_{\mathcal {B}}\). Find \(T\left (\begin{bmatrix}-2&3\\1&-5\end{bmatrix}\right )\).
We need to
find the coordinate vector for \(\begin{bmatrix}-2&3\\1&-5\end{bmatrix}\) with respect to \(\mathcal {B}\).
Let \(V\) be an \(n\)-dimensional vector space, and let \(\mathcal {B}\) be an ordered basis for \(V\). Then \(T:V\rightarrow \RR ^n\) given by \(T(\vec {v})=[\vec {v}]_{\mathcal {B}}\) is a linear transformation.
First observe that Theorem ?? of Bases and Dimension of Abstract Vector Spaces guarantees that there is only one way to
represent each element of \(V\) as a linear combination of elements of \(\mathcal {B}\). Thus each element of \(V\) maps to exactly one element of \(\RR ^n\), as
long as the order in which elements of \(\mathcal {B}\) appear is taken into account. This proves that \(T\) is a function, or a transformation. We
will now prove that \(T\) is linear.
Let \(\vec {v}\) be an element of \(V\). We will first show that \(T(k\vec {v})=kT(\vec {v})\). Suppose \(\mathcal {B}=\{\vec {v}_1, \ldots ,\vec {v}_n\}\), then \(\vec {v}\) can be written as a unique linear combination:
We leave it to the reader to verify that \(T(\vec {v}+\vec {w})=T(\vec {v})+T(\vec {w})\). (See Practice Problem ??.)
Invertibility of Coordinate Mappings
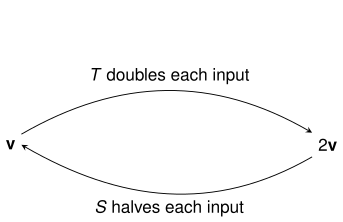
Consider a linear transformation \(T:\RR ^2\rightarrow \RR ^2\) that scales all input vectors by a factor of two, and a linear transformation \(S:\RR ^2\rightarrow \RR ^2\) that scales all
input vectors by a factor of one half. The composite functions \(S\circ T\) and \(T\circ S\) are both identity transformations. \(S\) and \(T\) are clearly inverses
of each other. Diagrammatically, we can represent \(T\) and \(S\) as follows:
This gives us a way of thinking about an inverse of \(T\) as a transformation that “undoes" the action of \(T\) by “reversing" the mapping
arrows. We will now use these intuitive ideas to understand which linear transformations are invertible and which are
not.
Given an arbitrary linear transformation \(T:V\rightarrow W\), “reversing the arrows" may not always result in a transformation. Recall that
transformations are functions. The figures below show two ways in which our attempt to “reverse" \(T\) may fail to produce a
function.
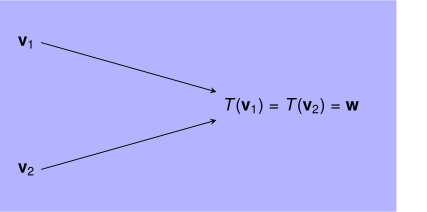
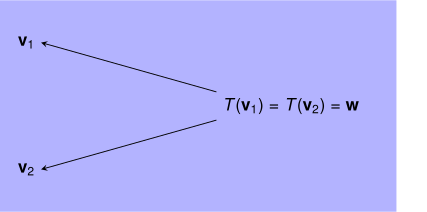
First, if two distinct vectors \(\vec {v}_1\) and \(\vec {v}_2\) map to the same vector \(\vec {w}\) in \(W\), then reversing the arrows gives us a mapping that is clearly not
a function.
Based on this diagram, it is reasonable to conjecture that for a transformation to be invertible, the transformation must be
such that each output is the image of exactly one input. Such transformations are called one-to-one.
One-to-One A linear transformation \(T:V\rightarrow W\) is one-to-one if
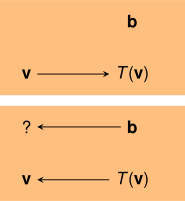
Second, observe that our definition of an inverse of \(T:V\rightarrow W\) requires that the domain of the inverse transformation be \(W\). (Definition ??,
Composition and Inverses of Linear Transformations) If there is a vector \(\vec {b}\) in \(W\) that is not an image of any vector in \(V\), then \(\vec {b}\) cannot
be in the domain of an inverse transformation.
The above figure makes a convincing case that for a transformation to be invertible every element of the codomain must have
something mapping to it. Transformations such that every element of the codomain is an image of some element of the
domain are called onto.
Onto A linear transformation \(T:V\rightarrow W\) is onto if for every element \(\vec {w}\) of \(W\), there exists an element \(\vec {v}\) of \(V\) such that \(T(\vec {v})=\vec {w}\).
Let \(V\) and \(W\) be vector spaces, and let \(T:V\rightarrow W\) be a linear transformation. Then \(T\) has an inverse if and only if \(T\) is one-to-one and onto.
We will first assume that \(T\) is one-to-one and onto, and show that there exists a transformation \(S:W\rightarrow V\) such that \(S\circ T=\id _V\) and \(T\circ S=\id _W\). Because \(T\) is
onto, for every \(\vec {w}\) in \(W\), there exists \(\vec {v}\) in \(V\) such that \(T(\vec {v})=\vec {w}\). Moreover, because \(T\) is one-to-one, vector \(\vec {v}\) is the only vector that maps to \(\vec {w}\). To
stress this, we will say that for every \(\vec {w}\), there exists \(\vec {v}_{\vec {w}}\) such that \(T(\vec {v}_{\vec {w}})=\vec {w}\). (Since every \(\vec {v}\) maps to exactly one \(\vec {w}\), this notation makes sense
for elements of \(V\) as well.) We can now define \(S:W\rightarrow V\) by \(S(\vec {w})=\vec {v}_{\vec {w}}\). Then
Let \(V\) be a vector space, and let \(\mathcal {B}\) be an ordered basis for \(V\). Then the linear transformation \(T:V\rightarrow \RR ^n\) given by \(T(\vec {v})=[\vec {v}]_{\mathcal {B}}\) is invertible.
We leave the proof of this result to the reader.
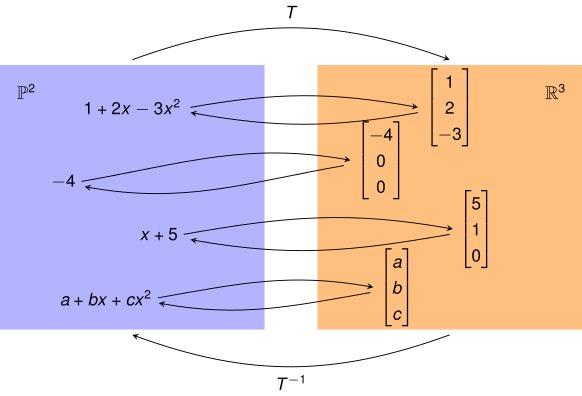
Recall that the set of all polynomials of degree \(2\) or less, together with polynomial addition and scalar multiplication, is a vector
space, denoted by \(\mathbb {P}^2\). Let \(\mathcal {B}=\{1, x, x^2\}\). You should do a quick mental check that \(\mathcal {B}\) is a basis of \(\mathbb {P}^2\).
Define a transformation \(T:\mathbb {P}^2\rightarrow \RR ^3\) by \(T(a+bx+cx^2)=\begin{bmatrix}a\\b\\c\end{bmatrix}\). In other words, \(T\) maps each element of \(\mathbb {P}^2\) to its coordinate vector with respect to the ordered basis
\(\mathcal {B}\).
The diagram below illustrates the actions of \(T\) and \(T^{-1}\) on several elements.
Coordinate Isomorphisms
Invertible linear transformations, such as the coordinate mapping, are useful because they preserve the structure of
interactions between elements as we move back and forth between two vector spaces, allowing us to answer questions about
one vector space in a different vector space. In particular, any question related to linear combinations can be addressed in
this fashion. This includes questions concerning linear independence, span, basis and dimension. Specifically, for coordinate
mappings, it is easy to see that the following property holds.
Let \(V\) be an \(n\)-dimensional vector space, and let \(T:V\rightarrow \RR ^n\) be the coordinate mapping with respect to some ordered basis \(\mathcal {B}\) of \(V\). Then the
set of vectors \(\{\vec {x}_1,\vec {x}_2,\dots ,\vec {x}_k\}\) of \(V\) is linearly independent if and only if the set \(\{T(\vec {x}_1),T(\vec {x}_2),\dots ,T(\vec {x}_k)\}\) is linearly independent in \(\RR ^n\).
Let \(V\) and \(W\) be vector spaces. If there exists an invertible linear transformation \(T:V\rightarrow W\) we say that \(V\) and \(W\) are isomorphic and write \(V\cong W\). The
invertible linear transformation \(T\) is called an isomorphism.
It is worth pointing out that if \(T:V\rightarrow W\) is an isomorphism, then \(T^{-1}:W\rightarrow V\), being linear and invertible, is also an isomorphism.
Because coordinate mappings are isomorphisms, we have the following fundamental result.
Every \(n\)-dimensional vector space is isomorphic to \(\RR ^n\).
Practice Problems
Recall that the set \(V\) of all symmetric \(2\times 2\) matrices is a subspace of \(\mathbb {M}_{2,2}\). In Example ?? of Bases and Dimension of Abstract Vector
Spaces we demonstrated that \(\mathcal {B} = \left \{ \begin{bmatrix} 1 & 0 \\ 0 & 0 \end{bmatrix}, \begin{bmatrix} 0 & 0 \\ 0 & 1 \end{bmatrix}, \begin{bmatrix} 0 & 1 \\ 1 & 0 \end{bmatrix} \right \}\) is a basis for \(V\). Define \(T:V\rightarrow \RR ^3\) by \(T(A)=[A]_{\mathcal {B}}\). Find \(T(I_2)\) and \(T\left (\begin{bmatrix}2&-3\\-3&1\end{bmatrix}\right )\).
Let \(V\) be a subspace of \(\RR ^3\) with a basis \(\mathcal {B}=\left \{\begin{bmatrix}2\\1\\-1\end{bmatrix}, \begin{bmatrix}0\\3\\2\end{bmatrix}\right \}\). Find the coordinate vector, \([\vec {v}]_{\mathcal {B}}\), for \(\vec {v}=\begin{bmatrix}4\\-1\\-4\end{bmatrix}\).
Verify that \(\mathcal {B}=\{x^{2}, x + 1, 1 - x - x^{2}\}\) is a basis for \(\mathbb {P}^2\). Define \(T:\mathbb {P}^2\rightarrow \RR ^3\) by \(T(p(x))=[p(x)]_{\mathcal {B}}\). Find \(T(0)\), \(T(x+1)\) and \(T(x^2-3x+1)\).
Let \(V\) and \(W\) be vector spaces, and let \(\mathcal {B}_V=\{\vec {v}_1, \vec {v}_2, \vec {v}_3, \vec {v}_4\}\) and \(\mathcal {B}_W=\{\vec {w}_1,\vec {w}_2, \vec {w}_3\}\) be ordered bases of \(V\) and \(W\), respectively. Suppose \(T:V\rightarrow W\) is a linear transformation such
that:
\[T(\vec {v}_1)=\vec {w}_2\]
\[T(\vec {v}_2)=2\vec {w}_1-3\vec {w}_2\]
\[T(\vec {v}_3)=\vec {w}_2+\vec {w}_3\]
\[T(\vec {v}_4)=-\vec {w}_1\]
If \(\vec {v}=-2\vec {v}_1+3\vec {v}_2-\vec {v}_4\), express \(T(\vec {v})\) as a linear combination of vectors of \(\mathcal {B}_W\).