Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
← LTR-0055/mainMatrices of Linear Transformations with Respect to Arbitrary Bases
Matrices of Linear Transformations with Respect to Arbitrary Bases
We know that every linear transformation from \(\RR ^n\) into \(\RR ^m\) is a matrix transformation (Theorem th:matlin). However, the matrix that
represents a linear transformation is tied to the basis we choose. So far we have only used the standard basis of \(\RR ^n\). What about
linear transformations between vector spaces other than \(\RR ^n\)? In this section we will learn to represent linear transformations
between arbitrary finite-dimensional vector spaces using matrices. To do so, we will use the fact that every
\(n\)-dimensional vector space is isomorphic to \(\RR ^n\). (Theorem th:ndimisotorn). What we do here will serve as yet another example of how
isomorphisms can be used to translate problems in one vector space to another, more convenient, vector
space.
You should verify that \(\tau \) is linear. (See Practice Problem prob:taulinear.)
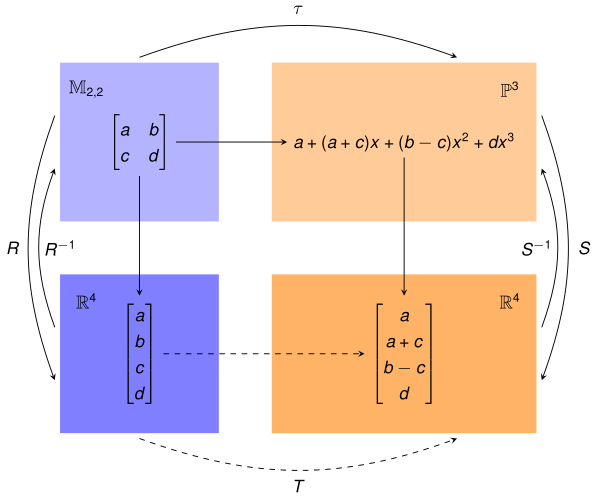
We will examine \(\tau \) in an effort to find a way to represent it with a matrix. The matrix we find will depend on our choice of bases.
We will choose bases that will make computations easier.
be our ordered bases of choice for \(\mathbb {M}_{2,2}\) and \(\mathbb {P}^3\), respectively.
Recall that a coordinate isomorphism maps a vector to its coordinate vector with respect to the given ordered basis (Theorem
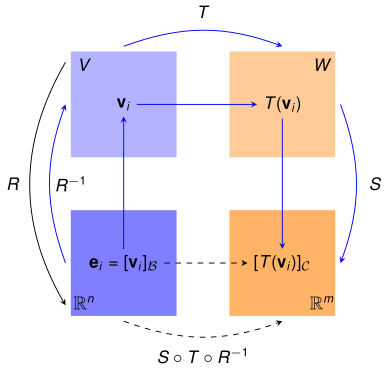
ex:coordmapiso). In the diagram below, let \(R\) and \(S\) be coordinate isomorphisms with respect to \(\mathcal {B}\) and \(\mathcal {C}\), respectively.
Observe that \(T=S\circ \tau \circ R^{-1}\). Because \(T\) is a composition of linear transformations, \(T\) itself is linear (Theorem th:complinear). Thus, we should be able to find
the standard matrix for \(T\). To do this, find the images of the standard unit vectors and use them to create the standard matrix \(A\)
for \(T\).
(You should mentally verify that \(T\) is linear.)
Our goal now is to find a matrix for \(T\) with respect to \(\mathcal {B}\) and \(\mathcal {C}\).
The information given in this problem is slightly different from the information in Exploration init:taumatrix. Instead of being given an
expression for the image of a generic vector of \(V\), we are only given the images of the two basis vectors of \(V\). But this information
is sufficient to determine the linear transformation.
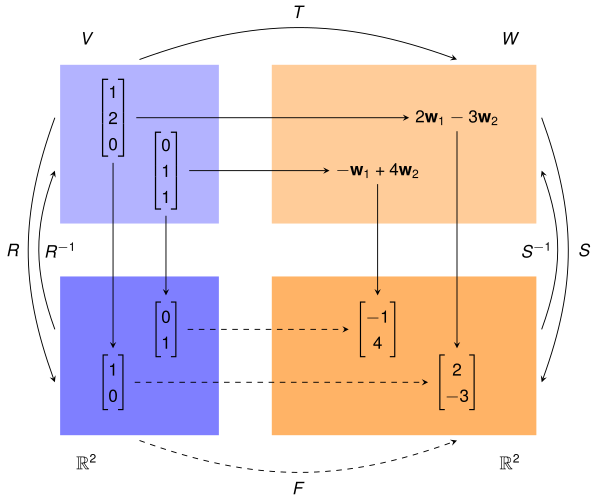
As before, we will map vectors of \(V\) and \(W\) to their coordinate vectors. Where are the coordinate vectors located?
1.
\([\vec {v}_1]_{\mathcal {B}}\) and \([\vec {v}_2]_{\mathcal {B}}\) are elements of \(\RR \), \(\RR ^2\), \(\RR ^3\)
2.
\([\vec {w}_1]_{\mathcal {C}}\) and \([\vec {w}_2]_{\mathcal {C}}\) are elements of \(\RR \), \(\RR ^2\), \(\RR ^3\)
Define \(F:\RR ^2\rightarrow \RR ^2\) by \(F=S\circ T\circ R^{-1}\). \(F\) is a linear transformation that maps \(\begin{bmatrix}1\\0\end{bmatrix}\) and \(\begin{bmatrix}0\\1\end{bmatrix}\) to \(\begin{bmatrix}2\\-3\end{bmatrix}\) and \(\begin{bmatrix}-1\\4\end{bmatrix}\), respectively. Thus, the standard matrix for \(F\)
is:
\[A=\begin{bmatrix}2&-1\\-3&4\end{bmatrix}\]
We say that \(A\) is a matrix for \(T\) with respect to \(\mathcal {B}\) and \(\mathcal {C}\).
Let’s take a look at what this matrix can do for us. Suppose we want to find the image of \(\vec {v}=2\vec {v}_1+\vec {v}_2\) under \(T\). We can compute this directly,
as follows:
Let \(V\) and \(W\) be vector spaces with ordered bases \(\mathcal {B}=\{\vec {v}_1, \vec {v}_2, \vec {v}_3\}\) and \(\mathcal {C}=\{\vec {w}_1, \vec {w}_2\}\), respectively. Define a linear transformation \(T:V\rightarrow W\) by
Find the matrix of \(T\) with respect to \(\mathcal {B}\) and \(\mathcal {C}\), and use it to find \(T(2\vec {v}_1-\vec {v}_2+3\vec {v}_3)\). Verify your answer by computing \(T(2\vec {v}_1-\vec {v}_2+3\vec {v}_3)\) directly.
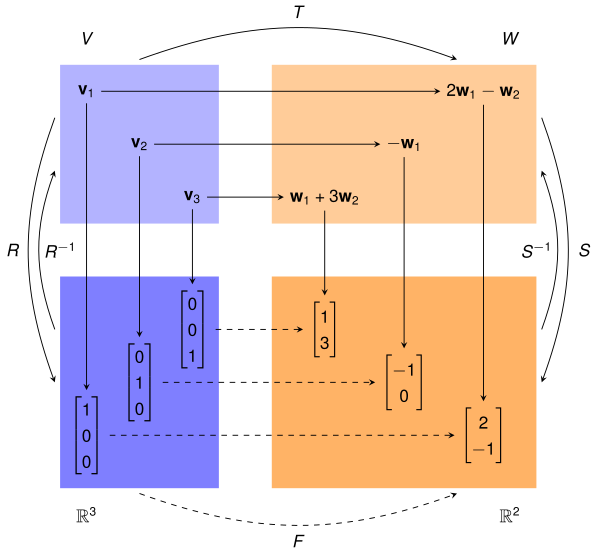
We start with a diagram:
Looking at the images of the standard unit vectors in \(\RR ^3\), we can construct the standard matrix \(A\) of \(T\) with respect to \(\mathcal {B}\) and
\(\mathcal {C}\).
\[A=\begin{bmatrix}2&-1&1\\-1&0&3\end{bmatrix}\]
Applying this matrix to the coordinate vector of \(2\vec {v}_1-\vec {v}_2+3\vec {v}_3\) we get
In this section we will formalize the process for finding the matrix of a linear transformation with respect to arbitrary bases that
we established through earlier examples.
Let \(V\) and \(W\) be vector spaces with ordered bases \(\mathcal {B}=\{\vec {v}_1, \vec {v}_2,\ldots ,\vec {v}_n\}\) and \(\mathcal {C}=\{\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_m\}\), respectively. Suppose \(T:V\rightarrow W\) is a linear transformation. Our goal is to find a
matrix for \(T\) with respect to \(\mathcal {B}\) and \(\mathcal {C}\).
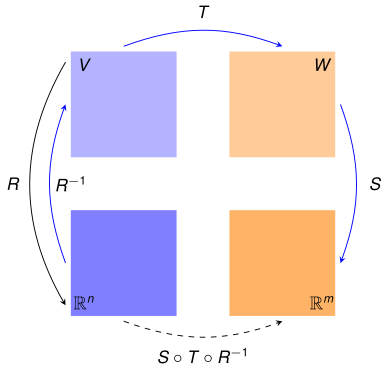
Observe that \(\text {dim}(V)=n=\text {dim}(\RR ^n)\) and \(\text {dim}(W)=m=\text {dim}(\RR ^m)\). Let \(R:V\rightarrow \RR ^n\) and \(S:W\rightarrow \RR ^m\) be coordinate isomorphisms defined by
We know that \(R\) is an isomorphism and \(R^{-1}\) exists. Consider the transformation
\[S\circ T\circ R^{-1}:\RR ^n\rightarrow \RR ^m\]
As a composition of linear transformation, \(S\circ T\circ R^{-1}\) is linear and thus has a standard matrix. To find it, we need to determine the
images of standard unit vectors \(\vec {e}_i\) under \(S\circ T\circ R^{-1}\). We have the following:
Vectors \([T(\vec {v}_i)]_{\mathcal {C}}\) will become the columns of the standard matrix. We summarize this discussion as a theorem.
Let \(V\) and \(W\) be finite-dimensional vector spaces with ordered bases \(\mathcal {B}=\{\vec {v}_1,\vec {v}_2,\ldots ,\vec {v}_n\}\) and \(\mathcal {C}\), respectively. Suppose \(T:V\rightarrow W\) is a linear
transformation.
Then \(A[\vec {v}]_{\mathcal {B}}=[T(\vec {v})]_{\mathcal {C}}\) for all vectors \(\vec {v}\) in \(V\).
Matrix \(A\) of Theorem 5 is called the matrix of \(T\) with respect to ordered bases \(\mathcal {B}\) and \(\mathcal {C}\).
In conclusion, observe how isomorphisms helped us solve the matrix of a linear transformation problem. The coordinate
mappings \(R\) and \(S\) are isomorphisms. This means that \(V\) and \(\RR ^n\) are isomorphic and have the same structural properties. The same
is true for \(W\) and \(\RR ^m\). In this abstract discussion, we do not know anything about the elements of \(V\) and \(W\), but isomorphisms allow us
to take a problem that we do not know much about and transform it to a familiar problem involving familiar
spaces.
The Inverse of a Linear Transformation and its Matrix
Let \(V\) and \(W\) be vector spaces. Suppose \(T:V\rightarrow W\) is an invertible linear transformation. This, of course, means that \(T\) is an isomorphism,
which means that
\[\mbox {dim}(V)=\mbox {dim}(W)\]
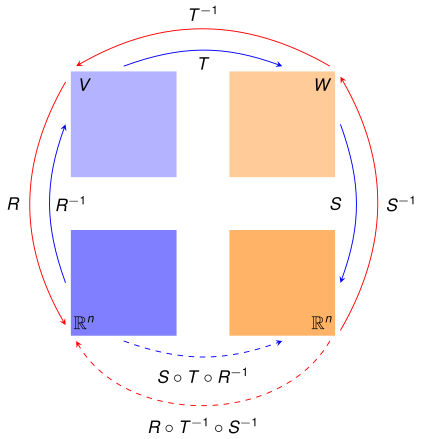
Let \(\mathcal {B}=\{\vec {v}_1, \vec {v}_2,\ldots ,\vec {v}_n\}\) and \(\mathcal {C}=\{\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_n\}\) be ordered bases of \(V\) and \(W\), respectively. We can find the matrix of \(T^{-1}\) with respect to \(\mathcal {C}\) and \(\mathcal {B}\) by finding the standard
matrix of the linear transformation \(R\circ T^{-1}\circ S^{-1}:\RR ^n\rightarrow \RR ^n\).
Observe that \(R\circ T^{-1}\circ S^{-1}\) is the inverse of \(S\circ T\circ R^{-1}\). So, if \(A\) is the standard matrix of \(S\circ T\circ R^{-1}\), then \(A^{-1}\) is the standard matrix of \(R\circ T^{-1}\circ S^{-1}\). Thus, \(A^{-1}\) is the matrix of \(T^{-1}\) with
respect to \(\mathcal {C}\) and \(\mathcal {B}\).
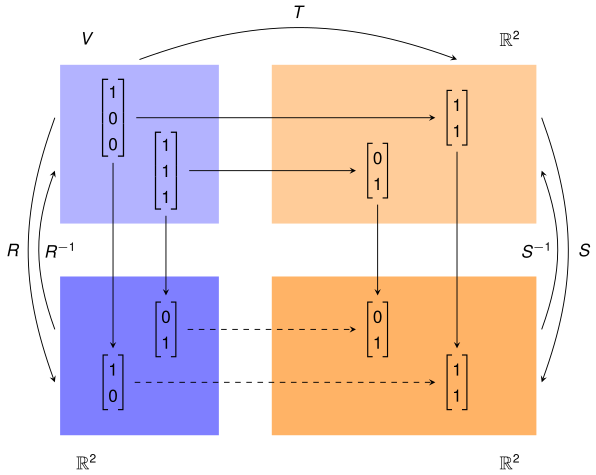
Conclude that \(T\) is invertible by finding the matrix of \(T^{-1}\) with respect to ordered bases \(\mathcal {C}=\left \{\begin{bmatrix}1\\0\end{bmatrix},\begin{bmatrix}0\\1\end{bmatrix}\right \}\) of \(\RR ^2\), and \(\mathcal {B}=\left \{\begin{bmatrix}1\\0\\0\end{bmatrix}, \begin{bmatrix}1\\1\\1\end{bmatrix}\right \}\) of \(V\).
Consider the
diagram:
This gives us the matrix of \(T\) with respect to \(\mathcal {B}\) and \(\mathcal {C}\):
Let \(V\) and \(W\) be vector spaces with ordered bases \(\mathcal {B}=\{\vec {v}_1, \vec {v}_2\}\) and \(\mathcal {C}=\{\vec {w}_1, \vec {w}_2, \vec {w}_3\}\), respectively. Define a linear transformation \(T:V\rightarrow W\) by
Find the matrix \(A\) of \(T\) with respect to \(\mathcal {B}\) and \(\mathcal {C}\), and use it to find \(T(-\vec {v}_1-3\vec {v}_2)\). Verify your answer by computing \(T(-\vec {v}_1-3\vec {v}_2)\) directly.
Show that \(\begin{bmatrix}-1\\3\\2\end{bmatrix}, \begin{bmatrix}2\\4\\1\end{bmatrix}\) lie in \(W\) by expressing them as linear combinations of \(\vec {w}_1\) and \(\vec {w}_2\).