Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
We start by reviewing the definition of a function.
Let \(V\) and \(W\) be sets. A function\(f\) from \(V\) into \(W\), denoted by
\[f:V\rightarrow W\]
assigns to each element \(x\) of \(V\), a single element \(y=f(x)\) of \(W\).
The set \(V\) is called the domain of \(f\), and the set \(W\) is called the codomain.
If \(y=f(x)\), we say that \(x\)maps to\(y\), and \(y\) is the image of \(x\).
The collection of images of all points of \(V\) is called the image of \(V\) under \(f\), or the image of \(f\). (It is also known as the range of \(f\).)
In algebra and calculus you worked with functions \(f:\RR \rightarrow \RR \) whose domain and codomain were each the set of all real numbers. In
linear algebra, we call our functions transformations. The domain and codomain of a transformation are vector
spaces.
In this exercise we will introduce a very special type of transformation by contrasting the effects of two transformations on
vectors of \(\RR ^2\). We will see that some transformations have “nice" properties, while others do not. Define \(T_1\) and \(T_2\) as
follows:
\[T_1:\RR ^2\rightarrow \RR ^2\]
\[T_1\left (\begin{bmatrix} x\\ y \end{bmatrix}\right )=\begin{bmatrix} x-y\\ x \end{bmatrix}\]
\[T_2:\RR ^2\rightarrow \RR ^2\]
\[T_2\left (\begin{bmatrix} x\\ y \end{bmatrix}\right )=\begin{bmatrix} -x+y+1\\ y-2 \end{bmatrix}\]
Each of these transformations takes a vector in \(\RR ^2\), and maps it to another vector in \(\RR ^2\). To see if you understand
how these transformations are defined, see if you can determine what these transformations do to the vector
\(\begin{bmatrix} 4\\ 3 \end{bmatrix}\).
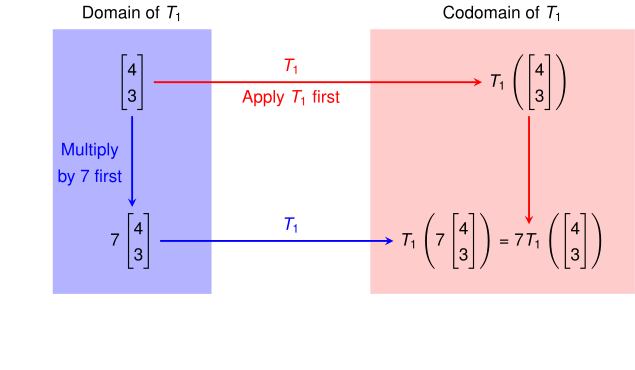
Observe that multiplying the original vector by \(7\), then applying \(T_1\), has the same effect as applying \(T_1\) to the original vector, then
multiplying the image by \(7\). In other words,
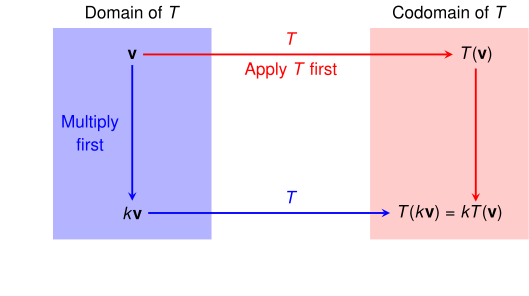
There is nothing special about the number \(7\), and it is not hard to prove that for any scalar \(k\) and vector \(\vec {u}\) of \(\RR ^2\), \(T_1\) satisfies
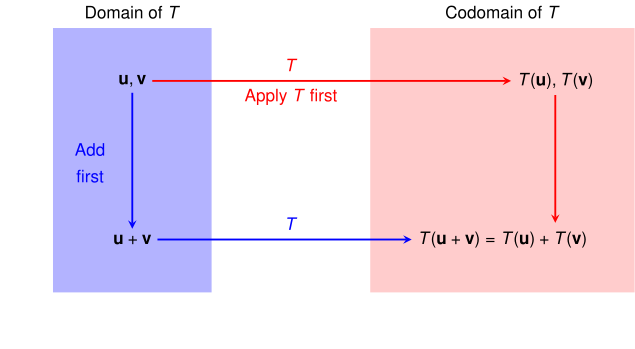
We leave it to the reader to illustrate this property with a specific example (see Practice Problem prob:sum). We will show that \(T_1\) satisfies
(lin2) in general.
Let \(\vec {u}=\begin{bmatrix} u_1\\ u_2 \end{bmatrix}\) and \(\vec {v}=\begin{bmatrix} v_1\\ v_2 \end{bmatrix}\), then
It turns out that \(T_2\) fails to satisfy this property. Can you prove that this is the case? Remember that to prove that a
property DOES NOT hold, it suffices to find a counter-example. See if you can find vectors \(\vec {u}\) and \(\vec {v}\) such that
Transformations satisfying (lin1) and (lin2), like \(T_1\), are called linear transformations. Transformations like \(T_2\) are not linear. You have
already encountered several linear transformations in the form of matrix transformations in sections Matrix Transformations
and Geometric Transformations of the Plane.
A transformation \(T:\RR ^n\rightarrow \RR ^m\) is called a linear transformation if the following are true for all vectors \(\vec {u}\) and \(\vec {v}\) in \(\RR ^n\), and scalars \(k\).
item:lintransfirstb Observe that \(\begin{bmatrix}1\\1\end{bmatrix}=\begin{bmatrix}1\\2\end{bmatrix}+\begin{bmatrix}0\\-1\end{bmatrix}\). By (eq:lintranscombinedprop) we have:
In Example ex:lintransfirst we were given the images of two vectors, \(\begin{bmatrix}1\\2\end{bmatrix}\) and \(\begin{bmatrix}0\\-1\end{bmatrix}\), under a linear transformation \(T\). Based on this information, we
were able to determine the images of two additional vectors: \(\begin{bmatrix}2\\5\end{bmatrix}\) and \(\begin{bmatrix}1\\1\end{bmatrix}\). The reason we were able to determine \(T\left (\begin{bmatrix}2\\5\end{bmatrix}\right )\) and \(T\left (\begin{bmatrix}1\\1\end{bmatrix}\right )\) is because \(\begin{bmatrix}2\\5\end{bmatrix}\)
and \(\begin{bmatrix}1\\1\end{bmatrix}\) can be written as unique linear combinations of \(\begin{bmatrix}1\\2\end{bmatrix}\) and \(\begin{bmatrix}0\\-1\end{bmatrix}\).
Can every vector of \(\RR ^2\) be written as a linear combination of \(\begin{bmatrix}1\\2\end{bmatrix}\) and \(\begin{bmatrix}0\\-1\end{bmatrix}\)?
Yes No
Is the information provided in Example ex:lintransfirst sufficient to determine the image of every vector in \(\RR ^2\) under \(T\)?
Yes No
Suppose \(T:\RR ^2\rightarrow \RR ^2\) is a transformation such that
Since \(\begin{bmatrix} 6\\ 5 \end{bmatrix}\neq \begin{bmatrix} 2\\ -4 \end{bmatrix}\) we conclude that transformation \(T\) is not linear.
In Exploration init:lintransintro we introduced a transformation \(T_2\) which turned out to be non-linear. It took some work to show that \(T_2\) is not linear.
The following theorem would have made our work easier.
Let \(T:\RR ^n\rightarrow \RR ^m\) be a linear transformation. Then
1.
\(T(\vec {0})=\vec {0}\). In other words, linear transformations map the zero vector to the zero vector.
2.
\(T\) maps any line in \(\RR ^n\) to a line (or the zero vector) in \(\RR ^m\).
To prove part item:zerotozero, let \(\vec {v}\) be any vector in \(\RR ^n\). By linearity of \(T\), we have:
Since \(T_2(\vec {0})\neq \vec {0}\), \(T_2\) is not linear.
Linear Transformations Induced by Matrices
Recall that a transformation \(T:\RR ^n\rightarrow \RR ^m\) defined by \(T(\vec {v})=A\vec {v}\), where \(A\) is some \(m\times n\) matrix, is called a matrix transformation (or transformation induced
by \(A\)). As we had discovered in Matrix Transformations, all matrix transformations are linear. We now formalize this result as a
theorem.
Let \(A\) be an \(m\times n\) matrix. Define \(T:\RR ^n\rightarrow \RR ^m\) by \(T(\vec {v})=A\vec {v}\). Then \(T\) is a linear transformation.
Let \(\vec {u}\) and \(\vec {v}\) be vectors in \(\RR ^n\), and let \(k\) be a scalar. By properties of matrix multiplication we have:
1\(A\) is a \(3\times 2\) matrix, so for the expression \(T(\vec {x})=A\vec {x}\) to make sense, \(\vec {x}\) has to be a \(2\times 1\) vector. Thus, the domain of \(T\) is \(\RR ^2\) (\(n=2\)). The product \(A\vec {x}\) is a \(3\times 1\) vector.
The codomain of \(T\) is \(\RR ^3\) (\(m=3\)).
2 By Definition 1, the image of \(T\) consists of images of all individual vectors in \(\RR ^2\) under \(T\). Every vector \(\vec {v}\) in \(\RR ^2\) can be written as \(\vec {v}=a\vec {i}+b\vec {j}\) for
some real numbers \(a\) and \(b\). Consider the image of \(\vec {v}\)
This shows that the range, or the image, of \(T\) consists of all linear combinations of the columns of \(A\). In other words, the image of
\(T\) is the span of vectors \(\begin{bmatrix}2\\1\\0\end{bmatrix}\) and \(\begin{bmatrix}0\\4\\1\end{bmatrix}\). The two vectors are not scalar multiples of each other, therefore they span a plane in \(\RR ^3\).
Let \(T:\RR ^n\rightarrow \RR ^m\) be a linear transformation induced by
This shows that the image of every vector in \(\RR ^3\) is a scalar multiple of \(\begin{bmatrix}1\\-2\end{bmatrix}\). This means that the image of \(T\) is a line in
\(\RR ^2\).
Linear Transformations of Subspaces of \(\RR ^n\)
Definition 2 defines a linear transformation as a map from \(\RR ^n\) into \(\RR ^m\). We will now make this definition more general by allowing the
domain and the codomain of the transformation to be subspaces of \(\RR ^n\) and \(\RR ^m\). Eventually, a linear transformation will be defined as
a mapping between vector spaces.
Let \(V\) and \(W\) be subspaces of \(\RR ^n\) and \(\RR ^m\). A transformation \(T:V\rightarrow W\) is called a linear transformation if the following are true for all vectors \(\vec {u}\) and
\(\vec {v}\) in \(V\), and scalars \(k\).
\[T(k\vec {u})= kT(\vec {u})\]
\[T(\vec {u}+\vec {v})= T(\vec {u})+T(\vec {v})\]
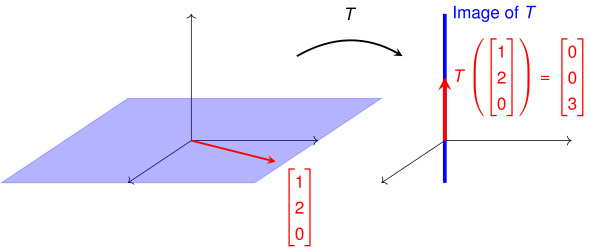
Let \(V\) be a subspace of \(\RR ^3\) consisting of all vectors in the \(xy\)-plane. Let \(W\) be a subspace of \(\RR ^3\) consisting of all vectors along the \(z\)-axis.
(Do a quick verification that \(V\) and \(W\) are subspaces of \(\RR ^3\).) Define a transformation \(T:V\rightarrow W\) by
Verification of the fact that \(T\left (k\begin{bmatrix}a_1\\b_1\\0\end{bmatrix}\right )=kT\left (\begin{bmatrix}a_1\\b_1\\0\end{bmatrix}\right )\) is similar, and we omit the details.
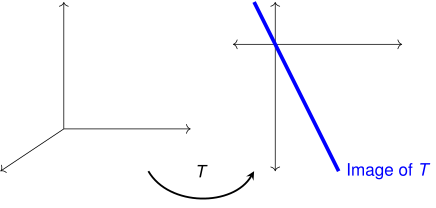
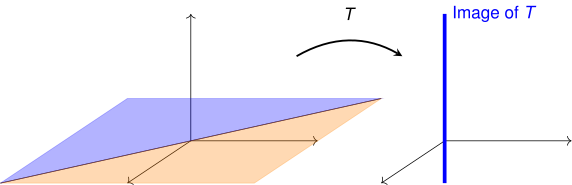
We have shown that \(T\) is a linear transformation. \(T\) maps all vectors in the \(xy\)-plane to the \(z\)-axis. The following diagram helps us
visualize the action of \(T\) on a specific vector.
We can investigate further. Recall that \(T\) is defined by
\[T_1\left (\begin{bmatrix} x\\ y \end{bmatrix}\right )=\begin{bmatrix} x-y\\ x \end{bmatrix}\]
(See Exploration ) Use vectors \(\begin{bmatrix}3\\4\end{bmatrix}\) and \(\begin{bmatrix}-2\\1\end{bmatrix}\) to illustrate that \(T_1(\vec {u}+\vec {v}) = T_1(\vec {u})+T_1(\vec {v})\).
Define \(T_2\) as follows
\[T_2:\RR ^2\rightarrow \RR ^2\]
\[T_2\left (\begin{bmatrix} x\\ y \end{bmatrix}\right )=\begin{bmatrix} -x+y+1\\ y-2 \end{bmatrix}\]
(See Exploration )
Use a counter-example to prove that \(T_2(\vec {u}+\vec {v}) \neq T_2(\vec {u})+T_2(\vec {v})\)
Suppose \(T:\RR ^{10}\rightarrow \RR ^2\) is a linear transformation such that \(T(\vec {u})=\begin{bmatrix}2\\-1\end{bmatrix}\) and \(T(\vec {v})=\begin{bmatrix}-5\\3\end{bmatrix}\). Find the image of \(3\vec {u}-\vec {v}\).
Let \(\vec {u}\) be a fixed non-zero vector. Define \(T_{\vec {u}}:\RR ^2\rightarrow \RR ^2\), by \(T_{\vec {u}}(\vec {x})=\vec {u}-\vec {x}\).
1.
Describe the effect of this transformation by sketching \(\bf x\) and \(T_{\vec {u}}({\bf x})\) for at least four vectors \(\bf x\) and a fixed vector \(\vec {u}\) of your
choice.
2.
Is \(T_{\vec {u}}\) a linear transformation?
Define \(P_{xy}:\RR ^3\rightarrow \RR ^2\), by \(P_{xy}\left (\begin{bmatrix} x\\ y\\ z \end{bmatrix} \right )=\begin{bmatrix} x\\ y\\ 0 \end{bmatrix}\). This transformation is called an orthogonal projection onto the \(xy\)-plane. Show that \(P_{xy}\) is a linear transformation.
Suppose a linear transformation \(T:\RR ^3\rightarrow \RR ^3\) maps \(\bf i\) to \(\begin{bmatrix}2\\-1\\0\end{bmatrix}\), \(\bf j\) to \(\begin{bmatrix}-2\\4\\1\end{bmatrix}\), and \(\bf k\) to \(\begin{bmatrix}3\\0\\-5\end{bmatrix}\). Find the image of \(\begin{bmatrix}1\\1\\-2\end{bmatrix}\) under \(T\).