Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
At several places in this course it has been valuable to restrict ourselves to square matrices, and we do so again when
discussing eigenvalues and eigenvectors.
In Theorem th:matrixtran, we proved that any \(n \times n\) matrix induces a linear transformation from \(\RR ^n\) to itself. For our first few examples, let us
consider the case \(n = 2\).
Let \(A=\begin{bmatrix} 2& 1\\ 1&2 \end{bmatrix}\). The following interactive helps us to visualize the matrix transformation associated with \(A\). Given a vector \(\vec {x}\) in \(\RR ^2\) (left panel),
its image, \(A\vec {x}\), is also in \(\RR ^2\) (right panel). Drag the head of the vector \(\vec {x}\) to see its image.
What do you observe about the relationship between vectors along the red line \(y=-x\) and their images?
For many vectors \(\vec {x}\) of \(\RR ^2\), \(A\vec {x}\) does not point in the same direction as \(\vec {x}\) but if we look at the vectors along the line \(y=-x\), we notice that the
transformation does not seem to affect their magnitude and direction. Such vectors are sometimes called fixed vectors of \(A\). For
example \(\begin{bmatrix}1\\-1\end{bmatrix}\) is a fixed vector.
What do you observe about the relationship between vectors along the blue line \(y=x\) and their images?
We observe that the magnitudes of these vectors are changed by the transformation, but the direction in which the vectors
point is unchanged.
In Exploration init:eignintro we found that the images of vectors \(\begin{bmatrix}1\\1\end{bmatrix}\) and \(\begin{bmatrix}-1\\1\end{bmatrix}\) stay parallel to the original vectors under the linear transformation
induced by matrix \(A\). Such vectors are examples of eigenvectors of \(A\).
In general, any nonzero vector whose image under a matrix transformation is parallel to the original vector is
called an eigenvector of the matrix that induced the transformation. The following definition captures this idea
algebraically.
Let \(A\) be an \(n \times n\) matrix. We say that a non-zero vector \(\vec {x}\) is an eigenvector of \(A\) if
\[A\vec {x} = \lambda \vec {x}\]
for some scalar \(\lambda \). We say that \(\lambda \) is an eigenvalue of \(A\) associated with the eigenvector \(\vec {x}\).
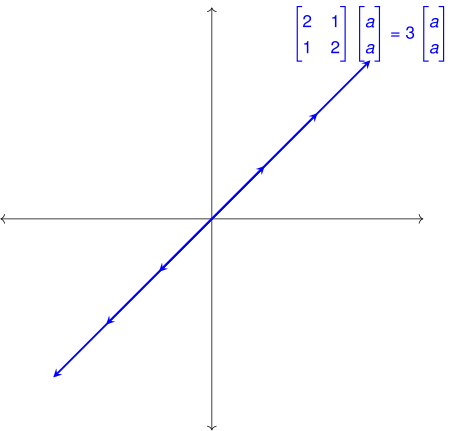
Let’s revisit Exploration init:eignintro in light of Definition def:eigen. In the exploration, we observed visually that vectors parallel to \(\begin{bmatrix} 1\\ 1 \end{bmatrix}\) were
eigenvectors associated with \(A=\begin{bmatrix} 2& 1\\ 1&2 \end{bmatrix}\), as these vectors changed length but remained parallel to the original vector under the linear
transformation induced by \(A\). To verify this algebraically, observe that all vectors parallel to \(\begin{bmatrix} 1\\ 1 \end{bmatrix}\) can be written in the form \(\begin{bmatrix} a\\ a \end{bmatrix}\), \((a\neq 0)\). We
compute
\[\begin{bmatrix} 2& 1\\ 1&2 \end{bmatrix} \begin{bmatrix} a\\ a \end{bmatrix} = \begin{bmatrix} 3a\\ 3a \end{bmatrix}= 3 \begin{bmatrix} a\\ a \end{bmatrix}\]
This shows that any non-zero scalar multiple of \(\begin{bmatrix} 1\\ 1 \end{bmatrix}\) is an eigenvector of \(A\) which has a corresponding eigenvalue of
3.
Fixed vectors of Exploration init:eignintro are also eigenvectors. For example,
This shows that \(\begin{bmatrix} 1\\ -1 \end{bmatrix}\) is a fixed vector and an eigenvector of \(A\) which has a corresponding eigenvalue of \(1\).
The above discussion leads us to the following result.
If \(\vec {x}\) is an eigenvector of matrix \(A\) and \(\lambda \) is the corresponding eigenvalue, then every non-zero scalar multiple of \(\vec {x}\) is also an
eigenvector of \(A\) and \(\lambda \) is the corresponding eigenvalue.
A couple of finer points of Definition def:eigen require clarification.
The definition requires that eigenvectors be non-zero. Imagine what would happen if we allowed \(\vec {x}=\vec {0}\) to be an
eigenvector of \(A\). Clearly \(A\vec {0}=\lambda \vec {0}\) for all scalars \(\lambda \). This means that every number would be an eigenvalue of every matrix.
Because eigenvalues are supposed to capture certain information about the matrix, allowing every number to
be an eigenvalue of every matrix would defeat the purpose.
Until now, we had talked about eigenvectors as vectors whose images under a matrix transformation are
parallel to the original vectors. But the algebraic definition allows non-zero vectors that map to zero to be
considered eigenvectors. (What would an eigenvalue of such an eigenvector be?) The zero vector has no
direction, so we cannot say that the image of such an eigenvector is parallel to the original vector. Example ex:eigen
will illustrate this point.
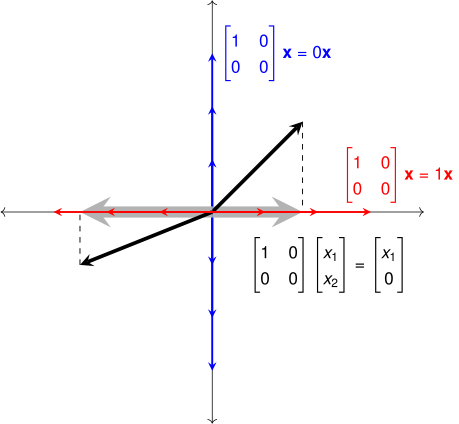
Let \(P=\begin{bmatrix} 1& 0\\ 0&0\end{bmatrix}\). Note that \(P\) takes a vector in \(\RR ^2\) and projects it onto the \(x\)-axis, as we learned in Practice Problem prob:standardmatrix3. Which vectors in \(\RR ^2\) would
be the eigenvectors, and what are the corresponding eigenvalues?
Since \(P\vec {x}\) is the projection of \(\vec {x}\) onto the \(x\)-axis, in many cases \(P\vec {x}\)
and \(\vec {x}\) are not parallel. Notice, however, that all of the red vectors located along the \(x\)-axis in the diagram are fixed by \(P\). So, for
any of the red vectors we have \(P\vec {x}=\vec {x}=1\vec {x}\), which means that each of the red vectors is an eigenvector of \(P\) with the corresponding
eigenvalue of \(1\).
The blue vectors along the y-axis are also eigenvectors. To see this, note that each of the blue vectors is of the form \(\vec {x}=\begin{bmatrix}0\\x_2\end{bmatrix}\). But
then
So each of the blue vectors is an eigenvector of \(P\) with the corresponding eigenvalue of \(0\).
Let \(A=\begin{bmatrix}1&6\\1&0\end{bmatrix}\). The GeoGebra interactive below shows vector \(\vec {x}\), and its image, \(A\vec {x}\) in the same coordinate plane. (Move the head of \(\vec {x}\) to see
the effect of \(A\) on different vectors.)
Note that vectors \(\vec {x}_1=\begin{bmatrix}3\\1\end{bmatrix}\) and \(\vec {x}_2=\begin{bmatrix}-2\\1\end{bmatrix}\) (and their scalar multiples) remain positioned along the same lines even as they change magnitude
and direction. This indicates that \(\vec {x}_1\) and \(\vec {x}_2\), along with all of their scalar multiples, are eigenvectors of \(A\). What are the eigenvalues
associated with these eigenvectors?
Eigenvalue associated with \(\vec {x}_1\) is \(\lambda _1=\answer {3}\).
Eigenvalue associated with \(\vec {x}_2\) is \(\lambda _2=\answer {-2}\).
A natural question is this: does every square matrix have eigenvalues and eigenvectors? We will see later that the answer to
this question is “yes", provided that we permit eigenvalues and entries of eigenvectors to be complex numbers. The next
example illustrates this.
Let \(M=\begin{bmatrix} \frac {\sqrt {2}}{2} & -\frac {\sqrt {2}}{2}\\ \frac {\sqrt {2}}{2} & \frac {\sqrt {2}}{2} \end{bmatrix}\). Note that \(M\) takes any vector \(\vec {x}\) in \(\RR ^2\) and rotates it \(45^{\circ }\), as we saw in Example ex: rotate45.
Since \(M\) rotates every vector in \(\RR ^2\), every nonzero vector changes direction, so there are no eigenvectors in the plane. It turns out
that \(M\) does have eigenvectors and eigenvalues, but in order to find them we need to work with vectors whose entries are
complex numbers. Since these vectors are not in \(\RR ^2\), we cannot see them.
To follow the computation below, you need to recall that the imaginary unit \(i\) is defined by \(i^2=-1\).
Consider the vector \(\begin{bmatrix} \frac {\sqrt {2}}{2}\\ \frac {\sqrt {2}}{2} i \end{bmatrix}\). We compute:
so \(\begin{bmatrix} \frac {\sqrt {2}}{2}\\ \frac {\sqrt {2}}{2} i \end{bmatrix}\) is an eigenvector of \(M\). Its corresponding eigenvalue is \(\frac {\sqrt {2}}{2}-\frac {\sqrt {2}}{2}i\).
We will continue to work with complex numbers as we study eigenvalues and eigenvectors.
Why All the Fuss About Eigenvalues and Eigenvectors?
The first in-depth study of eigenvalues can probably be attributed to Fourier as he studied partial differential equations early in
the nineteenth century, and in particular when he studied what is known as the heat equation. [Trefethen and Embree] By the
twentieth century mathematicians understood the connections between differential equations and eigenvalues.
Systems of differential equations are often best represented by matrices, especially in the context of using
computers to find numerical solutions. Most algorithms to solve these systems work by iterating some process, and
eigenvalues along with their corresponding eigenvectors indicate what will happen to such a process after many
repetitions.
The most famous modern example of a large-scale eigenvalue problem is the Google PageRank algorithm, which helped set
Google apart from its competitors as a search engine. Some of the relevant mathematics can be learned by working through
the paper, “The $25,000,000,000 Eigenvector, The Linear Algebra Behind Google”, by Kurt Bryan and Tanya Leise.
Show that \(\begin{bmatrix} 1\\1\\1 \end{bmatrix}\) is an eigenvector of \(C\). What is its corresponding eigenvalue? \(\answer {4}\)
Show that \(\begin{bmatrix} 1\\-1\\0 \end{bmatrix}\) is an eigenvector of \(C\). What is its corresponding eigenvalue? \(\answer {1}\)
Show that \(\begin{bmatrix} 1\\1\\-2 \end{bmatrix}\) is an eigenvector of \(C\). What is its corresponding eigenvalue? \(\answer {1}\)
Let \(Q=\begin{bmatrix} 0& 0\\ 0&1\end{bmatrix}\). Note that \(Q\) takes any vector in \(\RR ^2\) and projects it onto the \(y\)-axis. Which vectors in \(\RR ^2\) would be eigenvectors, and what are the
corresponding eigenvalues?
Returning to Example 7, let \(M=\begin{bmatrix} \frac {\sqrt {2}}{2} & -\frac {\sqrt {2}}{2}\\ \frac {\sqrt {2}}{2} & \frac {\sqrt {2}}{2} \end{bmatrix}\). Show that \(\begin{bmatrix} \frac {\sqrt {2}}{2}\\ -\frac {\sqrt {2}}{2} i \end{bmatrix}\) is an eigenvector of \(M\). What is its corresponding eigenvalue?
Please enter an exact answer; no decimal approximations. To enter square roots, click inside the answer box, then use the
“Math Editor" button that appears at the top of your XIMERA window.
Arguing geometrically, identify the linear transformation whose standard matrix has eigenvalues \(\lambda _1=1\) and \(\lambda _2=-1\).
Vertical Shear Horizontal Shear Counterclockwise Rotation through a \(90^\circ \) angleReflection About the line \(y=mx\)Horizontal Stretch Vertical
Stretch
Let \(A=\begin{bmatrix} 3&0&0\\0&3&0\\0&0&3\end{bmatrix}\). Can you find an eigenvector and its corresponding eigenvalue? Can you find another “eigenpair”? Can you find all of
the eigenvectors of \(A\)?
The rotation matrix in Example 7 has complex eigenvectors and eigenvalues. Think geometrically to find an example of a
(non-identity) rotation matrix with real eigenvectors and eigenvalues.
Enter degree measure between 0 and 360.
Answer: Rotation through \(\answer {180}\) degrees.
Can an eigenvalue have multiple eigenvectors associated with it?
Yes No
Can an eigenvector have multiple eigenvalues associated with it?
Yes No
Prove that if \(\vec {x}\) is an eigenvector of matrix \(A\) and \(\lambda \) is the corresponding eigenvalue, then every non-zero scalar multiple of \(\vec {x}\) is also
an eigenvector of \(A\) and \(\lambda \) is the corresponding eigenvalue. (Theorem 2)
Bibliography
[Trefethen and Embree] Trefethen, Lloyd and Embree, Mark, Spectra and Pseudospectra, Princeton University Press, 2005, p.
5-6