Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
When studying vectors, the two main operations we have learned about are vector addition and scalar multiplication. Both are
involved in the important concept of a linear combination of vectors.
A vector \(\vec {v}\) is said to be a linear combination of vectors \(\vec {v}_1, \vec {v}_2,\ldots , \vec {v}_n\) if
For example, \(\begin{bmatrix} -4\\9\\-10\\-1\end{bmatrix}\) is a linear combination of \(\begin{bmatrix} -1\\3\\-3\\0\end{bmatrix}\), \(\begin{bmatrix} 2\\0\\1\\4\end{bmatrix}\) and \(\begin{bmatrix} 0\\1\\-1\\1\end{bmatrix}\) because
In this section we will focus on vectors in \(\RR ^2\) and \(\RR ^3\).
Visualizing Linear Combinations in \(\RR ^2\) and \(\RR ^3\)
Let’s start by visualizing linear combinations of two vectors in \(\RR ^2\).
Answer the questions below using the GeoGebra interactive. To use the interactive, you can
1.
Change vectors \(\vec {v}\) and \(\vec {w}\) by dragging the tips of these vectors.
2.
Change the coefficients \(k_1\) and \(k_2\) of the linear combination by using sliders.
1.
Let \(\vec {w}=\begin{bmatrix}1\\2\end{bmatrix}\) and \(\vec {v}=\begin{bmatrix}1\\-1\end{bmatrix}\). Find \(k_1\) and \(k_2\) such that \(k_1\vec {w}+k_2\vec {v}=\begin{bmatrix}4\\-1\end{bmatrix}\)
\[k_1=\answer {1},\quad k_2=\answer {3}\]
2.
Let \(\vec {w}=\begin{bmatrix}1\\2\end{bmatrix}\) and \(\vec {v}=\begin{bmatrix}-2\\0\end{bmatrix}\). Find \(k_1\) and \(k_2\) such that \(k_1\vec {w}+k_2\vec {v}=\begin{bmatrix}3\\-2\end{bmatrix}\)
\[k_1=\answer {-1},\quad k_2=\answer {-2}\]
3.
Use the same vectors \(\vec {w}\) and \(\vec {v}\) as in the previous part. Do you think it is possible to express any vector in \(\RR ^2\) as a linear
combination of \(\vec {w}\) and \(\vec {v}\)? Yes, No
4.
Let \(\vec {w}=\begin{bmatrix}4\\2\end{bmatrix}\) and \(\vec {v}=\begin{bmatrix}-2\\-1\end{bmatrix}\). Do you think it is possible to express any vector in \(\RR ^2\) as a linear combination of \(\vec {w}\) and \(\vec {v}\)? Yes, No
Visualizing linear combinations of vectors in \(\RR ^3\) is more difficult than doing so in \(\RR ^2\). The following Exploration will help you do
this.
We will start by visualizing linear combinations of two vectors, \(\vec {u}\) and \(\vec {v}\), in \(\RR ^3\). To use the interactive below, define vectors \(\vec {u}\) and \(\vec {v}\).
Use sliders to change the coefficients \(k_1\) and \(k_2\) of the linear combination. You will see the linear combination \(k_1\vec {u}+k_2\vec {v}\) as the pink vector
along the diagonal of the parallelogram determined by \(\vec {u}\) and \(\vec {v}\).
RIGHT-CLICK and DRAG the left panel to rotate the image.
We will now consider three vectors. Define vectors \(\vec {u}\), \(\vec {v}\) and \(\vec {w}\). Use sliders to change the coefficients \(k_1, k_2\) and \(k_3\) of the linear
combination. The linear combination \(k_1\vec {u}+k_2\vec {v}+k_3\vec {w}\) is shown as the pink vector along the diagonal of the parallelepiped.
RIGHT-CLICK and DRAG the left panel to rotate the image.
Geometry of Linear Combinations
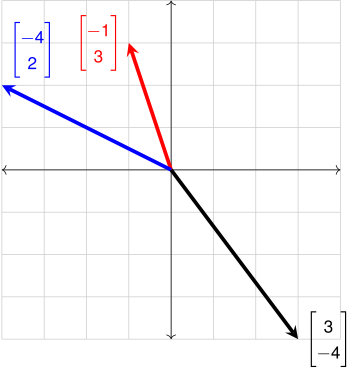
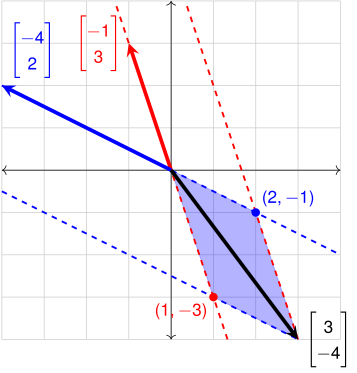
Use geometry to express \(\begin{bmatrix}3\\-4\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}-1\\3\end{bmatrix}\) and \(\begin{bmatrix}-4\\2\end{bmatrix}\).
We are looking for \(\begin{bmatrix}3\\-4\end{bmatrix}\) to be the diagonal of a parallelogram determined by scalar multiples of \(\begin{bmatrix}-1\\3\end{bmatrix}\) and \(\begin{bmatrix}-4\\2\end{bmatrix}\).
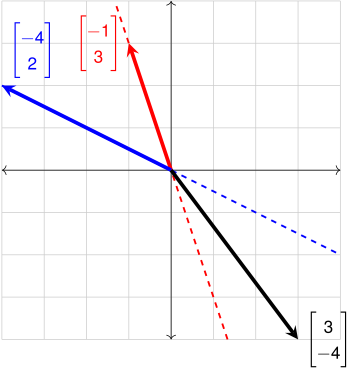
Because a scalar multiple of a vector can point in the same direction as the vector or in the opposite direction, we will start by
drawing straight lines determined by the two vectors.
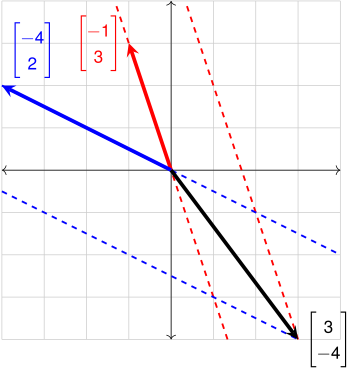
The two lines that we drew will contain the sides of the parallelogram we are looking for. To find the other two sides we will
draw lines parallel to \(\begin{bmatrix}-1\\3\end{bmatrix}\) and \(\begin{bmatrix}-4\\2\end{bmatrix}\) through the head of vector \(\begin{bmatrix}3\\-4\end{bmatrix}\).
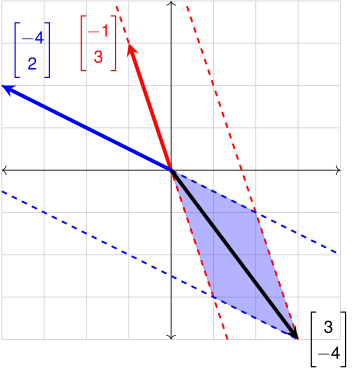
Now the parallelogram is clearly visible.
The last remaining task is to identify the sides of the parallelogram as scalar multiples of \(\begin{bmatrix}-1\\3\end{bmatrix}\) and \(\begin{bmatrix}-4\\2\end{bmatrix}\). Observe that vectors \(\begin{bmatrix}1\\-3\end{bmatrix}\) and \(\begin{bmatrix}2\\-1\end{bmatrix}\)
determine the parallelogram.
Vector \(\begin{bmatrix}2\\-1\end{bmatrix}\) is half the length of \(\begin{bmatrix}-4\\2\end{bmatrix}\) and points in the opposite direction, while the vector \(\begin{bmatrix}1\\-3\end{bmatrix}\) is the same length as \(\begin{bmatrix}-1\\3\end{bmatrix}\) and also points in the
opposite direction.
We write \(\begin{bmatrix}3\\-4\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}-1\\3\end{bmatrix}\) and \(\begin{bmatrix}-4\\2\end{bmatrix}\) as follows
The method we used in Example 4 to express the given vector as a linear combination of two other vectors is sufficiently
useful that we summarize the steps.
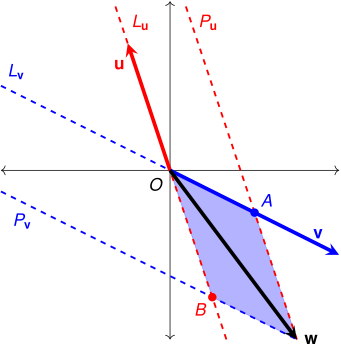
Given two non-collinear vectors \(\vec {u}\) and \(\vec {v}\) in \(\RR ^2\), and a vector \(\vec {w}\), we can express \(\vec {w}\) as a linear combination of \(\vec {u}\) and \(\vec {v}\) as
follows:
1.
Draw lines \(L_{\vec {u}}\) and \(L_{\vec {v}}\) determined by \(\vec {u}\) and \(\vec {v}\), respectively.
2.
Through the head of vector \(\vec {w}\), draw lines \(P_{\vec {u}}\) and \(P_{\vec {v}}\), parallel to \(L_{\vec {u}}\) and \(L_{\vec {v}}\), respectively.
3.
Let \(A\) be the point of intersection of \(P_{\vec {u}}\) and \(L_{\vec {v}}\).
4.
Let \(B\) be the point of intersection of \(P_{\vec {v}}\) and \(L_{\vec {u}}\).
5.
Let \(O\) denote the origin. Then \(\overrightarrow {OA}=k_1\vec {v}\) and \(\overrightarrow {OB}=k_2\vec {u}\) for some scalars \(k_1\) and \(k_2\).
6.
We have \(\vec {w}=k_2\vec {u}+k_1\vec {v}\).
This GeoGebra interactive will allow you to go through the steps given in Procedure 6 for a combination of vectors of your
choice. To use the interactive
1.
Enter components of vectors \(\vec {u}\) and \(\vec {v}\).
2.
Enter components of vector \(\vec {w}\) that you want to express as a linear combination of \(\vec {u}\) and \(\vec {v}\).
3.
Use the navigation bar to go through the steps of Procedure 6
From Geometry to Algebra of Linear Combinations
One of the stipulations in Procedure 6 is that vectors \(\vec {u}\) and \(\vec {v}\) should be non-collinear. You can use the interactive in Exploration
to investigate what happens when \(\vec {u}\) and \(\vec {v}\) are collinear. The following example examines what happens from a geometric as
well as an algebraic standpoint.
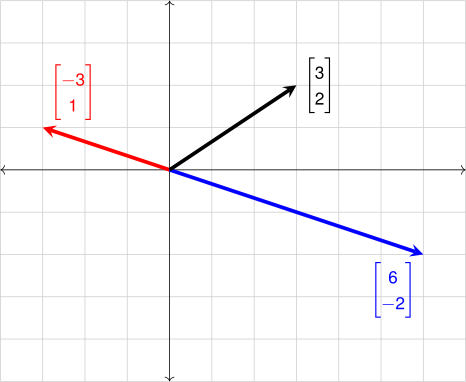
Can the vector \(\begin{bmatrix}3\\2\end{bmatrix}\) be written as a linear combination of vectors \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\)?
We will start with a geometric approach.
Observe that \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\) are scalar multiples of each other and lie on the same line.
A linear combination of \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\) has the form:
This shows that all linear combinations of \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\) will be scalar multiples of \(\begin{bmatrix}-3\\1\end{bmatrix}\), and therefore lie on the same line
as \(\begin{bmatrix}-3\\1\end{bmatrix}\). Since \(\begin{bmatrix}3\\2\end{bmatrix}\) does not lie on the line determined by \(\begin{bmatrix}-3\\1\end{bmatrix}\) it cannot be expressed as a linear combination of \(\begin{bmatrix}-3\\1\end{bmatrix}\) and
\(\begin{bmatrix}6\\-2\end{bmatrix}\).
We can also address this question algebraically. To express \(\begin{bmatrix}3\\2\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\), we need to solve the
equation.
When you try to solve this system, you will find that the system is inconsistent. Thus, \(\begin{bmatrix}3\\2\end{bmatrix}\) cannot be written as a linear
combination of \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\).
We know that there is no way to express \(\begin{bmatrix}3\\2\end{bmatrix}\) as a linear combination of vectors \(\begin{bmatrix}-3\\1\end{bmatrix}\) and \(\begin{bmatrix}6\\-2\end{bmatrix}\). What would happen if we tried to apply
Procedure 6 to these vectors? You can use the GeoGebra interactive in Exploration to find out.
Express \(\begin{bmatrix}2\\4\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}2\\1\end{bmatrix}\) and \(\begin{bmatrix}2\\-2\end{bmatrix}\). Interpret your results geometrically.
This amounts to solving a system of linear equations
\begin{align*} 2a+2b&=2\\ a-2b&=4 \end{align*}
Use your favorite method to solve this system. (Hint: adding the second equation to the first will work well for this system.) You
will find that \(a=2\) and \(b=-1\). Now we can write \(\begin{bmatrix}2\\4\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}2\\1\end{bmatrix}\) and \(\begin{bmatrix}2\\-2\end{bmatrix}\) as follows:
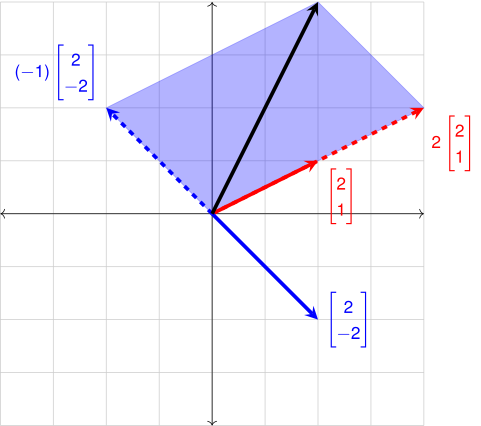
Geometrically speaking, this means that the vector \(\begin{bmatrix}2\\4\end{bmatrix}\) is the diagonal of the parallelogram determined by \(2\begin{bmatrix}2\\1\end{bmatrix}\) and \((-1)\begin{bmatrix}2\\-2\end{bmatrix}\). The original
vectors \(\begin{bmatrix}2\\1\end{bmatrix}\) and \(\begin{bmatrix}2\\-2\end{bmatrix}\) are shown below together with the parallelogram and its diagonal.
If possible, express \(\begin{bmatrix}7\\4\\-5\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}1\\-2\\1\end{bmatrix}\) and \(\begin{bmatrix}3\\0\\-1\end{bmatrix}\).
We are looking for coefficients \(a\) and \(b\) such that
We conclude that \(\begin{bmatrix}7\\4\\-5\end{bmatrix}\) is a linear combination of \(\begin{bmatrix}1\\-2\\1\end{bmatrix}\) and \(\begin{bmatrix}3\\0\\-1\end{bmatrix}\), and write:
Set up a system of equations that can be used to express \(\begin{bmatrix}2\\-1\\3\\0\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}1\\0\\4\\-2\end{bmatrix}\), \(\begin{bmatrix}-2\\-1\\1\\-1\end{bmatrix}\), \(\begin{bmatrix}0\\4\\-3\\1\end{bmatrix}\) and \(\begin{bmatrix}1\\1\\-1\\4\end{bmatrix}\), or to determine that such a
combination does not exist. Do not solve the system.
We are looking for \(x_1\), \(x_2\), \(x_3\) and \(x_4\) such that
Solve a system of linear equations to express \(\begin{bmatrix}-1\\7\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}1\\2\end{bmatrix}\) and \(\begin{bmatrix}-1\\1\end{bmatrix}\).
Use Procedure 6 to express \(\begin{bmatrix}-3\\0\end{bmatrix}\) as a linear combination of \(\begin{bmatrix}2\\4\end{bmatrix}\) and \(\begin{bmatrix}-1\\1\end{bmatrix}\).
Use two different approaches (algebraic and geometric) to explain why the vector \(\begin{bmatrix}5\\1\end{bmatrix}\) cannot be expressed as a linear
combination of vectors \(\begin{bmatrix}2\\-1\end{bmatrix}\) and \(\begin{bmatrix}-4\\2\end{bmatrix}\).
We have seen Procedure 6 applied to vectors in \(\RR ^2\). The same process can, in certain cases be applied to vectors in \(\RR ^3\). Follow
the steps in Procedure 6 to express one vector as a linear combination of two given vectors.
The following GeoGebra interactive shows vectors \({\bf u}=\begin{bmatrix}3\\0\\-1\end{bmatrix}\), \({\bf v}=\begin{bmatrix}1\\-2\\1\end{bmatrix}\) and \({\bf w}=\begin{bmatrix}7\\4\\-5\end{bmatrix}\). Use the navigation bar to click through the construction steps.
RIGHT-CLICK and DRAG to rotate the image.
1.
Can \(\vec {w}\) be expressed as a linear combination of \(\vec {u}\) and \(\vec {v}\)?
No, because \(\vec {w}\) is not between \(\vec {u}\) and \(\vec {v}\).Yes, because all three
vectors are in the same plane. Yes, because all three vectors are in the same plane, AND \(\vec {u}\) and \(\vec {v}\) are not collinear.
2.
Use the navigation bar at the bottom of the interactive window to view construction steps of Procedure 6 applied to
vectors \(\vec {u}\), \(\vec {v}\) and \(\vec {w}\). (Right-click and drag to rotate the image.) Use the final image to express \(\bf w\) as a linear combination of \(\bf v\)
(blue) and \(\bf u\) (red).
The following GeoGebra interactive shows vectors \({\bf v}=\begin{bmatrix}1\\-2\\1\end{bmatrix}\), \({\bf u}=\begin{bmatrix}3\\0\\-1\end{bmatrix}\), and \({\bf w}=\begin{bmatrix}7\\4\\0\end{bmatrix}\). RIGHT-CLICK and DRAG to rotate the image. Use geometry to
explain why \(\bf w\) cannot be expressed as a linear combination of \(\bf v\) and \(\bf u\).
We can also show that \(\bf w\) is not a linear combination of \(\bf v\) and \(\bf u\) algebraically by attempting to solve a system of equations
corresponding to