Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
A scalar is a quantity that has size, often called magnitude, but no direction. For example, temperature, mass and speed are
scalars. In this course, scalars will typically be real numbers, but we will also see complex numbers on a few
occasions.
A vector has magnitude and direction. For example, velocity is a vector because it tells us how fast the object is traveling and
also the direction of travel.
If an object is traveling along a number line, the direction of travel is given by the sign of its velocity (positive or negative),
while the speed is given by the absolute value of the velocity. If the object is traveling in a plane or in space, direction of travel
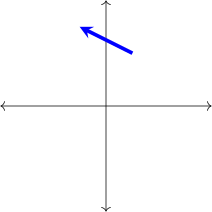
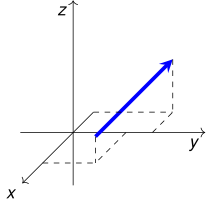
can be described by an arrow, while the speed can be represented by the length of the arrow. Graphically speaking, vectors in
\(\RR ^2\) and \(\RR ^3\) look like this:
A vector can be denoted by a lower-case letter with an arrow over the top (like this: \(\overrightarrow {u}\) ), or a bold lower-case letter (like this:
\(\vec {u}\)).
The magnitude, or length, of a vector is denoted by double absolute value brackets. For example, the magnitude of \(\vec {u}\), is
denoted by \(\norm {\vec {u}}\). A vector of zero length and no direction is called the zero vector. We denote the zero vector by \(\overrightarrow {0}\) or \(\vec {0}\). Going
forward, we will use the terms magnitude of a vector and length of a vector interchangeably.
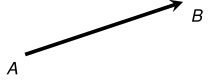
Sometimes it is convenient to refer to a vector by naming the endpoints of the arrow. In the figure below, point \(A\) is the tail, and
point \(B\) is the head of the vector.
We refer to this vector as \(\overrightarrow {AB}\).
Vectors in Standard Position
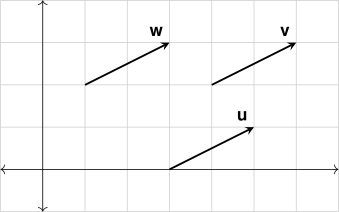
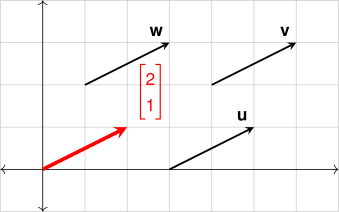
Vectors that point in the same direction and have the same length are said to be equivalent. For example, vectors \(\vec {u}\), \(\vec {v}\) and \(\vec {w}\) in the
figure below are equivalent. We write \(\vec {u}=\vec {v}=\vec {w}\).
For the purpose of developing standard, convenient notation, we observe that every vector is equivalent to some vector
whose tail is at the origin. Vectors with tails at the origin are said to be in standard position. We will refer to each vector in
standard position by the coordinates of its head. For example, a vector in standard position whose head is located at the point \((2, 1)\)
will be referred to as \(\begin{bmatrix}2\\1\end{bmatrix}\).
Vectors \(\vec {u}, \vec {v}\) and \(\vec {w}\) in the figure are equivalent to vector \(\begin{bmatrix}2\\1\end{bmatrix}\). We write \(\vec {u}=\vec {v}=\vec {w}=\begin{bmatrix}2\\1\end{bmatrix}\). Number \(2\) is called the first component of the vector (or the
\(x\)-component) while number \(1\) is the second component (or the \(y\)-component). The form \(\begin{bmatrix}2\\1\end{bmatrix}\) is called the component
form.
Vector \(\begin{bmatrix}2\\1\end{bmatrix}\) is an example of a column vector. Occasionally, we will find that representing this vector as a row vector\([2, 1]\) is more
convenient.
Column (or row) representation of vectors in component form allows us to go beyond the physical and geometric definition,
and think of vectors more abstractly as arrays of numbers.
Our next goal is to find a process for writing any vector in the coordinate plane in component form.
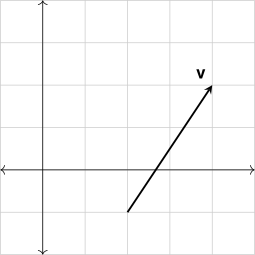
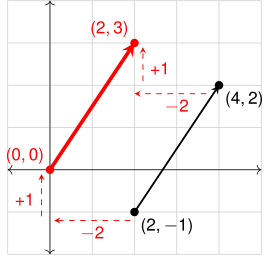
Consider vector \(\vec {v}\) shown below. We will express \(\vec {v}\) in component form.
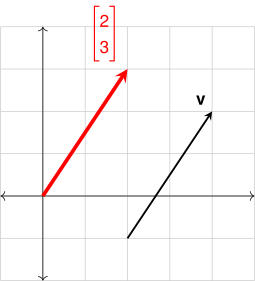
Note that the vector has a “run" of \(2\) and a “rise" of \(3\). If we construct a vector with tail at the origin, a “run" of \(2\) and a “rise" of \(3\), we
will have a vector in standard position equivalent to vector \(\vec {v}\).
The component form for the vector we constructed is \(\begin{bmatrix}2\\3\end{bmatrix}\). This gives us \(\vec {v}=\begin{bmatrix}2\\3\end{bmatrix}\).
The approach we used in Example 1 is applicable to
specific vectors that can easily be visualized. What we need now is an algebraic approach that can be generalized to higher
dimensions and more abstract situations.
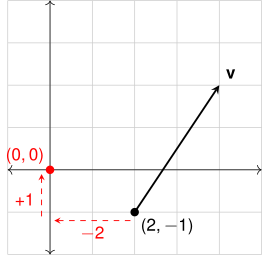
Let’s return to vector \(\vec {v}\) of Example 1. Suppose we were to slide vector \(\vec {v}\) into standard position. Consider what would happen to
the tail of \(\vec {v}\) as we do so.
What happens to the tail of the vector has to happen to the head
We subtracted \(2\) from the \(x\)-coordinate and added \(1\) to the \(y\)-coordinate of the tail. To find the new location of the head we subtract \(2\)
from the \(x\)-coordinate of the head, and add \(1\) to the \(y\)-coordinate of the head. This gives us \((4-2, 2+1)\). So, the new location of the head is \((2, 3)\),
and \(\vec {v}=\begin{bmatrix}2\\3\end{bmatrix}\).
If you look back at what we did you will find that the components of \(\vec {v}\) were computed by subtracting the coordinates of the tail
from the coordinates of the head
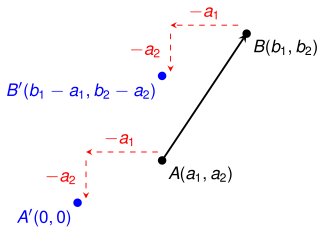
The following diagram summarizes and generalizes our findings.
Let \(\overrightarrow {AB}\) be a vector in \(\RR ^2\), with tail at point \(A(a_1, a_2)\) and head at point \(B(b_1, b_2)\). As we slide \(\overrightarrow {AB}\) into standard position by moving point \(A\) to the origin, point
\(B\) travels along with point \(A\) by undergoing the same horizontal and vertical shifts. We now have an equivalent vector \(\overrightarrow {A'B'}\) in standard
position. The diagram suggests the following formula.
“Head - Tail” Formula in \(\RR ^2\) Suppose a vector’s tail is at point \(A(a_1, a_2)\) and the vector’s head is at \(B(b_1, b_2)\), then
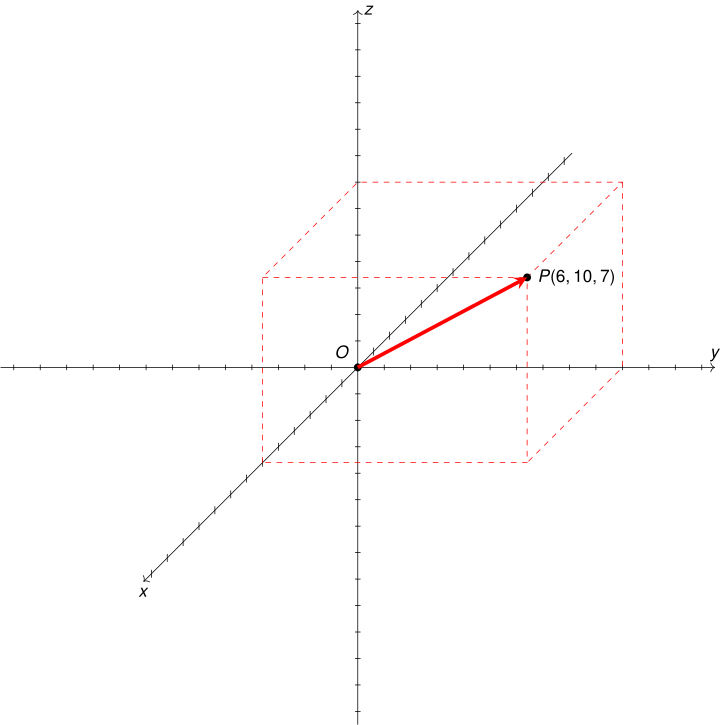
Definitions of standard position and component form for vectors in \(\RR ^3\) are analogous to their counterparts for vectors in
\(\RR ^2\). For example, vector \(\overrightarrow {OP}\) in the figure below, is in standard position and can be written in component form as
\(\overrightarrow {OP}=\begin{bmatrix}6\\10\\7\end{bmatrix}\).
If a vector is not in standard position but the location of its head and tail are known, a three-dimensional version of the “Head -
Tail" formula can be used to express the vector in component form.
“Head - Tail” Formula in \(\RR ^3\) Suppose a vector’s tail is at point \(A(a_1, a_2, a_3)\) and the vector’s head is at \(B(b_1, b_2, b_3)\), then
We cannot see \(\RR ^n\) for \(n>3\), but we can conceptualize it by generalizing what we know about \(\RR ^2\) and \(\RR ^3\). A vector \(\vec {v}\) in standard position
whose head is located at \((v_1, v_2, \ldots ,v_n)\) can be written in component form as \(\vec {v}=\begin{bmatrix}v_1\\ v_2\\ \vdots \\v_n\end{bmatrix}\).
Recall that we defined the zero vector as a vector that has length \(0\) and no direction. In component form, the zero vector is a
vector all of whose components are \(0\).
We conclude this section by stating the generalized “Head - Tail" formula.
“Head - Tail” Formula in \(\RR ^n\) Suppose a vector’s tail is at point \(A(a_1, a_2, \ldots ,a_n)\) and the vector’s head is at \(B(b_1, b_2, \ldots ,b_n)\), then