Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
A vector space is defined as a collection of objects together with operations of addition and scalar multiplication
that follow certain rules (Definition def:vectorspacegeneral of Abstract Vector Spaces). In our study of abstract vector spaces, we
have encountered spaces that appeared very different from each other. Just how different are they? Does \(\mathbb {L}\), a
vector space whose elements have the form \(mx+b\), have anything in common with \(\RR ^2\)? Is \(\mathbb {P}^3\) fundamentally different from
\(\mathbb {M}_{2,2}\)?
To answer these questions, we will have to look beyond the superficial appearance of the elements of a vector space and
delve into its structure. The “structure" of a vector space is determined by how the elements of the vector space interact with
each other through the operations of addition and scalar multiplication.
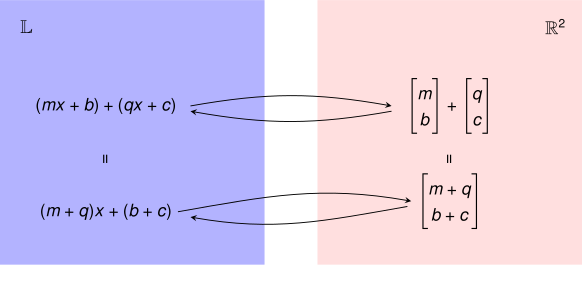
Let us return to the question of what \(\mathbb {L}\) has in common with \(\RR ^2\). Consider two typical elements of \(\mathbb {L}\):
But suppose we get tired of having to write \(x\) down every time. Could we leave off the \(x\) and represent \(mx+b\) by \(\begin{bmatrix}m\\b\end{bmatrix}\)?
If we do this, expressions (eq:iso1), (eq:iso2) and (eq:iso3) would be mimicked by the following expressions involving vectors of
\(\RR ^2\):
It appears that we should be able to switch back and forth between \(\mathbb {L}\) and \(\RR ^2\), translating questions and answers from one space
to the other and back again.
We begin to suspect that \(\mathbb {L}\) and \(\RR ^2\) have the same “structure". Spaces such as \(\mathbb {L}\) and \(\RR ^2\) are said to be isomorphic. This term is
derived from the Greek “iso," meaning “same," and “morphe," meaning “form." The term captures the idea that isomorphic
vector spaces have the same structure. Before we present a precise definition of the term, we need to better understand what
we mean by “switching back and forth" between spaces. The following Exploration will help us formulate this vague notion in
terms of transformations.
Recall that the set of all polynomials of degree \(2\) or less, together with polynomial addition and scalar multiplication, is a
vector space, denoted by \(\mathbb {P}^2\). Let \(\mathcal {B}=\{1, x, x^2\}\). You should do a quick mental check that \(\mathcal {B}\) is a basis of \(\mathbb {P}^2\).
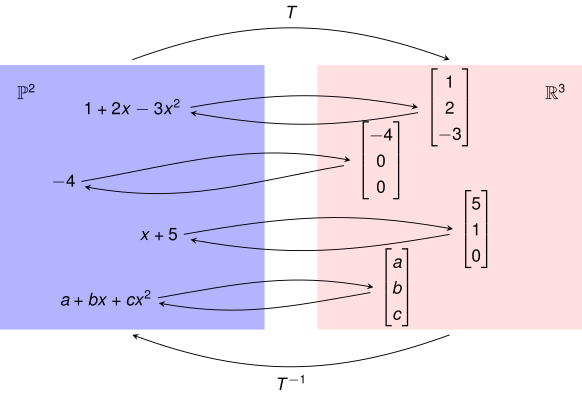
Define a transformation \(T:\mathbb {P}^2\rightarrow \RR ^3\) by \(T(a+bx+cx^2)=\begin{bmatrix}a\\b\\c\end{bmatrix}\). You may have recognized \(T\) as the transformation that maps each element of \(\mathbb {P}^2\) to its coordinate
vector with respect to the ordered basis \(\mathcal {B}\).
Our goal is to investigate and illustrate what these properties mean for transformation \(T\), and for the relationship between \(\mathbb {P}^2\) and
\(\RR ^3\).
First, observe that \(T\) being one-to-one and onto establishes “pairings" between elements of \(\mathbb {P}^2\) and \(\RR ^3\) in such a way that every
element of one vector space is uniquely matched with exactly one element of the other vector space, as shown in the diagram
below.
Second, the fact that \(T\) (and \(T^{-1}\)) are linear will allow us to translate questions related to linear combinations in one of the vector
spaces to equivalent questions in the other vector space, then translate answers back to the original vector space. To make
this statement concrete, consider the following problem:
Easy. But suppose for a moment that we did not know how to add polynomials, or that we found the process extremely
difficult, or maybe instead of \(\mathbb {P}^2\) we had another vector space that we did not want to deal with.
It turns out that we can use \(T\) and \(T^{-1}\) to answer the addition question. We will start by applying \(T\) to \(p_1(x)\) and \(p_2(x)\) separately:
This maneuver allows us to avoid the addition question in \(\mathbb {P}^2\) and answer the question in \(\RR ^3\) instead. We use \(T^{-1}\) to translate the
answer back to \(\mathbb {P}^2\):
Invertible linear transformations, such as transformation \(T\) of Exploration init:isomorph,
are useful because they preserve the structure of interactions between elements as we move back and forth between two
vector spaces, allowing us to answer questions about one vector space in a different vector space. In particular, any question
related to linear combinations can be addressed in this fashion. This includes questions concerning linear independence,
span, basis and dimension.
Let \(V\) and \(W\) be vector spaces. If there exists an invertible linear transformation \(T:V\rightarrow W\) we say that \(V\) and \(W\) are isomorphic and write \(V\cong W\). The
invertible linear transformation \(T\) is called an isomorphism.
It is worth pointing out that if \(T:V\rightarrow W\) is an isomorphism, then \(T^{-1}:W\rightarrow V\), being linear and invertible, is also an isomorphism.
Our earlier discussion suggests that \(\mathbb {L}\cong \RR ^2\). We postpone the proof until Theorem ex:coordmapiso.
Exploration init:isomorph shows that \(\mathbb {P}^2\cong \RR ^3\).
Show that \(\mathbb {M}_{2,2}\) and \(\mathbb {P}^3\) are isomorphic.
We will start by finding a plausible candidate for an isomorphism. Define \(T:\mathbb {M}_{2,2}\rightarrow \mathbb {P}^3\)
by
We conclude that \(T\) is an isomorphism, and \(\mathbb {M}_{2,2}\cong \mathbb {P}^3\).
Isomorphism \(T\) in Example ex:isomorphexample1 establishes the fact that \(\mathbb {M}_{2,2}\cong \mathbb {P}^3\). However, there is nothing
special about \(T\), as there are many other isomorphisms from \(\mathbb {M}_{2,2}\) to \(\mathbb {P}^3\). Just for fun, try to verify that each of the following is an
isomorphism.
In Exploration we made good use of a transformation that maps every element of \(\mathbb {P}^2\) to its coordinate vector in \(\RR ^3\). We observed
that this transformation is linear and invertible, therefore it is an isomorphism. The following example generalizes this
result.
Let \(V\) be an \(n\)-dimensional vector space, and let \(\mathcal {B}\) be an ordered basis for \(V\). Then \(T:V\rightarrow \RR ^n\) given by \(T(\vec {v})=[\vec {v}]_{\mathcal {B}}\) is an isomorphism.
We leave the proof of this result to the reader. (See Practice Problem .)
Properties of Isomorphic Vector Spaces and Isomorphisms
In this section we will illustrate properties of isomorphisms with specific examples. Formal proofs of properties will be
presented in the next section.
In Exploration we defined a transformation \(T:\mathbb {P}^2\rightarrow \RR ^3\) by \(T(a+bx+cx^2)=\begin{bmatrix}a\\b\\c\end{bmatrix}\). We later observed that \(T\) is an isomorphism. We will now examine the effect
of \(T\) on two different bases of \(\mathbb {P}^2\).
Let \(\mathcal {B}_1=\{1, x, x^2\}\) and \(\mathcal {B}_2=\{x, 1+x, x+x^2\}\). (Recall that \(\mathcal {B}_2\) is a basis of \(\mathbb {P}^2\) by Example ?? of Bases and Dimension of Abstract Vector Spaces.)
It is easy to verify that \(\begin{bmatrix}0\\1\\0\end{bmatrix}, \begin{bmatrix}1\\1\\0\end{bmatrix}, \begin{bmatrix}0\\1\\1\end{bmatrix}\) are linearly independent and span \(\RR ^3\), therefore the images of the elements of \(\mathcal {B}_2\) from a basis of
\(\RR ^3\).
We can try any number of bases of \(\mathbb {P}^2\) and we will find that the image of each basis of \(\mathbb {P}^2\) is a basis of \(\RR ^3\). In general, we have the
following result:
An isomorphism maps a basis of the domain to a basis of the codomain. (We will state this result more
formally as Theorem 16 in the next section.)
Isomorphisms preserve bases, but more generally, they preserve linear independence.
If \(T:V\rightarrow W\) is an isomorphism, then the subset \(\{\vec {v_1}, \vec {v}_2,\ldots ,\vec {v}_n\}\)
of \(V\) is linearly independent if and only if \(\{T(\vec {v_1}), T(\vec {v}_2),\ldots ,T(\vec {v}_n)\}\) is linearly independent in \(W\). (We will state and prove this result as Theorem 18.)
Let \(V\) be a vector space, and let \(\mathcal {B}=\{\vec {v}_1, \vec {v}_2, \vec {v}_3, \vec {v}_4\}\) be an ordered basis of \(V\). Let
Are \(\vec {w}_1, \vec {w}_2, \vec {w}_3\) linearly independent?
We could approach this question head-on by considering the vector equation
\[a\vec {w}_1+b\vec {w}_2+c\vec {w}_3=\vec {0}\]
to see if the only solution is the trivial one. (See Practice Problem .)
Instead, we will use isomorphisms. Observe that we do not know anything about \(V\) aside from the fact that it has four basis
vectors. Vectors \(\vec {w}_1\), \(\vec {w}_2\), \(\vec {w}_3\) are given in terms of these basis vectors. This should give us an idea for constructing an isomorphism
between \(V\) and \(\RR ^4\). Consider \(T:V\rightarrow \RR ^4\) such that \(T(\vec {w})=[\vec {w}]_{\mathcal {B}}\). Then
By Theorem 6, \(T\) is an isomorphism. This means that \(\vec {w}_1\), \(\vec {w}_2\), \(\vec {w}_3\) are linearly independent if and only if their coordinate vectors are
linearly independent. There are multiple ways of determining whether
We see that the rank of the matrix is \(2\). We conclude that the column vectors are not linearly independent. Thus, the vectors \(\vec {w}_1\), \(\vec {w}_2\)
and \(\vec {w}_3\) are not linearly independent.
Proofs of Isomorphism Properties
Recall that a transformation \(T\) is one-to-one provided that
\[T(\vec {v}_1)=T(\vec {v}_2)\]
implies that
\[\vec {v}_1=\vec {v}_2\]
We will show that images of linearly independent vectors under one-to-one linear transformations are linearly
independent.
Let \(T:V\rightarrow W\) be a one-to-one linear transformation. Suppose \(\{\vec {v}_1,\ldots ,\vec {v}_n\}\) is linearly independent in \(V\). Then \(\{T(\vec {v}_1),\ldots ,T(\vec {v}_n)\}\) is linearly independent in \(W\).
By assumption, \(\{\vec {v}_1,\ldots ,\vec {v}_n\}\) is linearly independent. Therefore \(a_i=0\) for \(1\leq i\leq n\).
Recall that a transformation \(T\) is onto provided that every vector of the codomain of \(T\) is the image of some vector in the domain
of \(T\).
We will show that an onto linear transformation maps sets that span the domain to sets that span the codomain.
Let \(T:V\rightarrow W\) be an onto linear transformation. Suppose \(V=\mbox {span}(\vec {v}_1,\ldots ,\vec {v}_n)\). Then \(W=\mbox {span}(T(\vec {v}_1),\ldots ,T(\vec {v}_n))\).
Suppose \(\vec {w}\) is an element of \(W\). To show that \(\{T(\vec {v}_1),\ldots ,T(\vec {v}_n)\}\) spans \(W\), we will express \(\vec {w}\) as a linear combination of \(T(\vec {v}_1),\ldots ,T(\vec {v}_n)\).
Because \(T\) is onto, \(\vec {w}=T(\vec {v})\) for some \(\vec {v}\) in \(V\). But \(V=\mbox {span}(\vec {v}_1,\ldots ,\vec {v}_n)\). Therefore, \(\vec {v}=a_1\vec {v}_1+\ldots +a_n\vec {v}_n\) for some scalar coefficients \(a_1,\ldots ,a_n\). By linearity, we have:
Thus, \(\vec {w}\) is in the span of \(T(\vec {v}_1),\ldots ,T(\vec {v}_n)\).
We will now combine the results of Theorem 12 and Theorem 14 to obtain a result about the effect of isomorphisms on a
basis.
Let \(T:V\rightarrow W\) be an isomorphism. Suppose \(\mathcal {B}_V=\{\vec {v}_1,\ldots ,\vec {v}_n\}\) is a basis for \(V\). Then \(\{T(\vec {v}_1),\ldots ,T(\vec {v}_n)\}\) is a basis for \(W\).
Left to the reader. (See Practice Problem )
Suppose \(T:V\rightarrow W\) is an isomorphism, then the subset \(\{\vec {v_1}, \vec {v}_2,\ldots ,\vec {v}_n\}\) of \(V\) is linearly independent if and only if \(\{T(\vec {v_1}), T(\vec {v}_2),\ldots ,T(\vec {v}_n)\}\) is linearly independent in \(W\).
We have already proved one direction of this this “if and only if" statement as Theorem 12. To prove the other direction,
suppose that \(T(\vec {v_1}), T(\vec {v}_2),\ldots ,T(\vec {v}_n)\) are linearly independent vectors in \(W\). We need to show that this implies that \(\vec {v_1}, \vec {v}_2,\ldots ,\vec {v}_n\) are linearly independent in \(V\).
Observe that if \(T\) is an isomorphism, then \(T^{-1}:W\rightarrow V\) is also an isomorphism. Thus, by Theorem 12, \(T^{-1}(T(\vec {v_1})), T^{-1}(T(\vec {v}_2)),\ldots ,T^{-1}(T(\vec {v}_n))\) are linearly independent. But this
means that \(\vec {v_1}, \vec {v}_2,\ldots ,\vec {v}_n\) are linearly independent.
Let \(U\), \(V\) and \(W\) be vector spaces. Suppose that \(T_1:U\rightarrow V\) and \(T_2:V\rightarrow W\) are isomorphisms. Then \(T_2\circ T_1:U\rightarrow W\) is an isomorphism.
The proof is left to the reader. (See Practice Problem .)
Finite-dimensional Vector Spaces
Let \(V\) and \(W\) be finite-dimensional vector spaces. Then
\[V\cong W\quad \text {if and only if}\quad \mbox {dim}(V)=\mbox {dim}(W)\]
First, assume that \(V\cong W\). Then there exists an isomorphism \(T:V\rightarrow W\). Suppose \(\mbox {dim}(V)=n\) and let \(\{\vec {v}_1,\vec {v}_2,\ldots ,\vec {v}_n\}\) be a basis for \(V\). By Theorem 16\(\{T(\vec {v}_1),\ldots ,T(\vec {v}_n)\}\) is a basis for \(W\).
Therefore \(\mbox {dim}(W)=n\).
Conversely, suppose \(\mbox {dim}(V)=\mbox {dim}(W)=n\), and let \(\mathcal {B}=\{\vec {v}_1,\vec {v}_2,\ldots ,\vec {v}_n\}\), \(\mathcal {C}=\{\vec {w}_1,\vec {w}_2,\ldots ,\vec {w}_n\}\) be bases for \(V\) and \(W\), respectively.
Define a linear transformation \(T:V\rightarrow W\) by \(T(\vec {v}_i)=\vec {w}_i\) for \(1\leq i\leq n\). To show that \(T\) is an isomorphism, we need to prove that \(T\) is one-to-one and
onto.
Suppose \(T(\vec {u}_1)=T(\vec {u}_2)\) for some vectors \(\vec {u}_1\), \(\vec {u}_2\) in \(V\). We know that
But \(\vec {w}_1,\vec {w}_2,\ldots ,\vec {w}_n\) are linearly independent, so \(a_i-b_i=0\) for all \(1\leq i\leq n\). Therefore \(a_i=b_i\) for all \(1\leq i\leq n\). We conclude that \(\vec {u}_1=\vec {u}_2\).
We now show that \(T\) is onto. Suppose that \(\vec {w}\) is an element of \(W\). Then \(\vec {w}=c_1\vec {w}_1+\ldots +c_n\vec {w}_n\) for some scalars \(c_i\)’s. But then
We conclude that \(\vec {w}\) is an image of an element of \(V\), so \(T\) is onto.
From this theorem follows an important corollary that shows why we spent so much time trying to understand \(\RR ^n\) in this
course.
Every \(n\)-dimensional vector space is isomorphic to \(\RR ^n\).
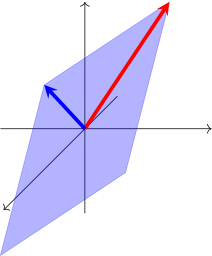
The span of any two linearly independent vectors in \(\RR ^3\) is isomorphic to \(\RR ^2\).
\(\mathbb {P}^2\ncong \RR ^2\)
Recall that \(\mbox {dim}(\mathbb {P}^2)=3\). Since \(\mbox {dim}(\mathbb {P}^2)=3\neq 2=\mbox {dim}(\RR ^2)\), we conclude that \(\mathbb {P}^2\) is not isomorphic to \(\RR ^2\).
Practice Problems
Prove that transformation \(T\) of Exploration is one-to-one and onto.
Let \(V\) be a vector space, and suppose \(\mathcal {B}=\{\vec {v}_1, \vec {v}_2, \vec {v}_3, \vec {v}_4, \vec {v}_5\}\) is a basis for \(V\). What can we conclude about \(V\)? Check ALL that apply.
We cannot
conclude anything about \(V\) because we don’t know what \(V\) is.\(V\cong \RR ^5\)\(V\cong \mathbb {P}^5\)\(V\cong \RR ^4\)\(V\cong \mathbb {P}^4\)\(V\cong \mathbb {M}_{5,5}\)
Which of the followng statements are true? Check ALL that apply.