Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
When we first introduced vectors we learned to represent them using component notation. If \(\vec {u}=\begin{bmatrix}2\\5\end{bmatrix}\) we know that the head of \(\vec {u}\) is
located at the point \((2, 5)\). But there is another way to look at the component form. Observe that \(\vec {u}\) can be expressed as a linear
combination of the standard unit vectors \(\vec {i}\) and \(\vec {j}\):
In fact, any vector \(\vec {v}=\begin{bmatrix}a\\b\end{bmatrix}\) of \(\RR ^2\) can be written as a linear combination of \(\vec {i}\) and \(\vec {j}\):
This gives us an alternative way of interpreting the component notation:
\[\left [\begin{array}{c} a\\b \end{array}\right ] \begin{array}{c} \longleftarrow \\ \longleftarrow \end{array} \begin{array}{c} \mbox {coefficient in front of $\vec {i}$}\\\mbox {coefficient in front of $\vec {j}$} \end{array}\]
We say that \(a\) and \(b\) are coordinates of \(\vec {v}\) with respect to \(\{\vec {i}, \vec {j}\}\), and \(\begin{bmatrix}a\\b\end{bmatrix}\) is said to be the coordinate vector for \(\vec {v}\) with respect to \(\{\vec {i}, \vec {j}\}\). Every
vector \(\vec {v}\) of \(\RR ^2\) can be thus represented using \(\vec {i}\) and \(\vec {j}\). Moreover, such representation in terms of \(\vec {i}\) and \(\vec {j}\) is unique for each vector,
meaning that we will never have two different coordinate vectors representing the same vector. We will refer to \(\{\vec {i}, \vec {j}\}\) as a basis of
\(\RR ^2\).
The order in which the basis elements are written matters. For example, \(\vec {u}\) is represented by the coordinate vector \(\begin{bmatrix}2\\5\end{bmatrix}\) with respect
to \(\{\vec {i}, \vec {j}\}\), but changing the basis to \(\{\vec {j}, \vec {i}\}\) would change the coordinate vector to \(\begin{bmatrix}5\\2\end{bmatrix}\).
\[\left [\begin{array}{c} 5\\2 \end{array}\right ] \begin{array}{c} \longleftarrow \\ \longleftarrow \end{array} \begin{array}{c} \mbox {coefficient in front of the first basis element }\\\mbox {coefficient in front of the second basis element} \end{array}\]
Clearly, standard unit vectors \(\vec {i}\) and \(\vec {j}\) are very convenient, but other vectors can also be used in place of \(\vec {i}\) and \(\vec {j}\) to represent
\(\vec {u}\).
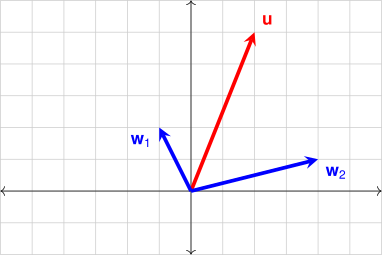
The diagram below shows \(\vec {u}\) together with vectors \(\vec {w}_1\) and \(\vec {w}_2\).
It is easy to see that
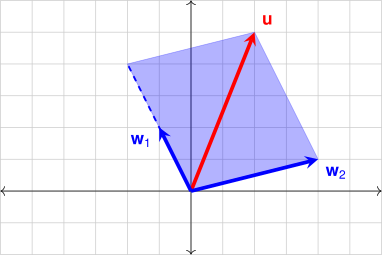
\[\vec {u}=2\vec {w}_1+\vec {w}_2\]
as shown below.
If we declare \(\{\vec {w}_1, \vec {w}_2\}\) to be a basis of \(\RR ^2\), then we can say that the coordinate vector for \(\vec {u}\) with respect to \(\{\vec {w}_1, \vec {w}_2\}\) is \(\begin{bmatrix}2\\1\end{bmatrix}\) .
\[\left [\begin{array}{c} 2\\1 \end{array}\right ] \begin{array}{c} \longleftarrow \\ \longleftarrow \end{array} \begin{array}{c} \mbox {coefficient in front of the first basis element }\\\mbox {coefficient in front of the second basis element} \end{array}\]
What Constitutes a Basis?
In the previous section we had used the term basis without defining it. Now is the time to pause and think about what we want
a basis to do. Let’s focus on \(\RR ^n\) and subspaces of \(\RR ^n\). What we establish here will easily generalize to other vector
spaces.
Based on our previous discussion, given any vector \(\vec {v}\) of \(\RR ^n\) (or a subspace \(V\) of \(\RR ^n\)), we want to be able to write a coordinate vector
for \(\vec {v}\) with respect to the given basis of \(\RR ^n\) (or \(V\)). Based on this condition, we will require that basis vectors span \(\RR ^n\) (or
\(V\)).
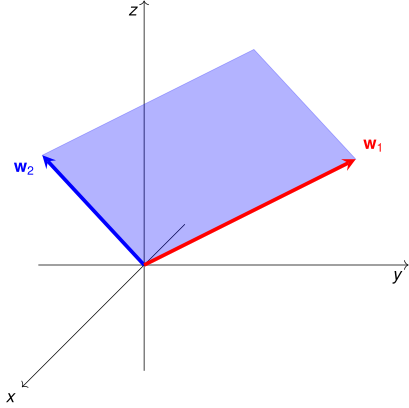
For example, consider \(\vec {w}_1\) and \(\vec {w}_2\) shown below.
The set \(\{\vec {w}_1, \vec {w}_2\}\) cannot be a basis for \(\RR ^3\) because \(\vec {w}_1\) and \(\vec {w}_2\) span a plane in \(\RR ^3\), and any vector not in that plane cannot be written as a linear
combination of \(\vec {w}_1\) and \(\vec {w}_2\).
On the other hand, the plane spanned by \(\vec {w}_1\) and \(\vec {w}_2\) is a subspace of \(\RR ^3\). Because every vector in that plane can be written as a linear
combination of \(\vec {w}_1\) and \(\vec {w}_2\), the set \(\{\vec {w}_1, \vec {w}_2\}\) can potentially be a basis for the plane, provided that the set satisfies our second
requirement.
Our second requirement is that for a fixed basis of \(\RR ^n\) (or \(V\)), the coordinate vector for each \(\vec {v}\) in \(\RR ^n\) (or \(V\)) should be unique. Uniqueness
of representation in terms of the basis elements will play an important role in our future study of functions that map vector
spaces to vector spaces.
The following theorem shows that the uniqueness requirement is equivalent to the requirement that the basis vectors be
linearly independent.
Suppose \(\{\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\}\) is a spanning set for a subspace \(V\) of \(\RR ^n\). Then every element \(\vec {v}\) of \(V\) has a unique representation as a linear combination
of \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\) if and only if the vectors \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\) are linearly independent.
Suppose that every \(\vec {v}\) in \(V\) can be expressed as a unique linear combination of \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\). This means that \(\vec {0}\) has a unique representation as
a linear combination of \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\). But
is a representation of \(\vec {0}\) in terms of \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\). Since we are assuming that such a representation is unique, we conclude that there is no
other. This means that the vectors \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\) are linearly independent.
Conversely, suppose that vectors \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\) are linearly independent. An arbitrary element \(\vec {v}\) of \(V\) can be expressed as a linear
combination of \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\):
Because we assumed that \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\) are linearly independent, we must have
\[a_1-b_1=0,\, a_2-b_2=0,\,\ldots ,\,a_p-b_p=0\]
so that
\[a_1=b_1,\, a_2=b_2,\,\ldots ,\,a_p=b_p\]
This proves the representation of \(\vec {v}\) in terms of \(\vec {w}_1, \vec {w}_2,\ldots ,\vec {w}_p\) is unique.
Use \(V=\mbox {span}(\mathcal {S})\), where \(\mathcal {S}=\left \{\begin{bmatrix}5\\2\\4\end{bmatrix},\begin{bmatrix}4\\1\\1\end{bmatrix},\begin{bmatrix}-3\\0\\2\end{bmatrix}\right \}\) to illustrate why a set of linearly dependent vectors cannot be used as a basis for a subspace by
showing that linearly dependent vectors fail to ensure uniqueness of coordinate vectors for vectors in \(V\).
We will
first show that the elements of \(\mathcal {S}\) are linearly dependent. Let \(A\) be a matrix whose columns are the vectors in
\(\mathcal {S}\).
This tells us that there are infinitely many nontrivial linear relations among the elements of \(\mathcal {S}\). Letting \(t=1\) gives us one such
nontrivial relation.
The set \(\mathcal {S}\) is linearly dependent. As a result, coordinate vectors for elements of \(V\) are not unique and we do not want to use \(\mathcal {S}\) as a
basis for \(V\).
Definition of a Basis
A set \(\mathcal {S}\) of vectors is called a basis of \(\RR ^n\) (or a basis of a subspace \(V\) of \(\RR ^n\)) provided that
1.
\(\mbox {span}(\mathcal {S})=\RR ^n\) (or \(V\))
2.
\(\mathcal {S}\) is linearly independent.
The standard unit vectors \(\vec {e}_1, \ldots ,\vec {e}_n\) are linearly independent and span \(\RR ^n\). Thus \(\{\vec {e}_1, \ldots ,\vec {e}_n\}\) is a basis of \(\RR ^n\).
The set \(\{\vec {e}_1, \ldots ,\vec {e}_n\}\) is called the standard basis of \(\RR ^n\).
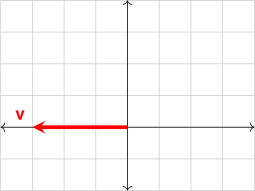
Bases are not unique. For example, we know that vectors \(\vec {i}\) and \(\vec {j}\) form the standard basis of \(\RR ^2\). But, as we discussed in Example
??
, vectors
Any linearly independent spanning set in \(\RR ^n\) (or a subspace of \(\RR ^n\)) is a basis of \(\RR ^n\) (or the subspace). The plural form of the word
basis is bases. It is easy to see that \(\RR ^n\) and its subspaces each has infinitely many bases.
Let \(V=\mbox {span}\left (\begin{bmatrix}-2\\1\\3\end{bmatrix},\begin{bmatrix}2\\-4\\1\end{bmatrix}\right )\). The set
is a basis for \(V\) because the two vectors in \(\mathcal {B}\) are linearly independent and span \(V\). Find the coordinate vector for \(\vec {v}=\begin{bmatrix}2\\-10\\9\end{bmatrix}\) with respect to \(\mathcal {B}\).
We need to express \(\begin{bmatrix}2\\-10\\9\end{bmatrix}\) as a linear combination of the elements of \(\mathcal {B}\). To this end, we need to solve the vector
equation:
The coefficient in front of the first basis vector is \(2\), the coefficient in front of the second basis vector is \(3\). This means that the
coordinate vector for \(\begin{bmatrix}2\\-10\\9\end{bmatrix}\) with respect to \(\mathcal {B}\) is \(\begin{bmatrix}2\\3\end{bmatrix}\).
It may seem strange to you that the coordinate vector for a vector in \(\RR ^3\) only has two components. But remember that subspace \(V\)
is a plane. When viewed as a vector in the plane, it makes sense that the coordinate vector for \(\begin{bmatrix}2\\-10\\9\end{bmatrix}\) only requires two
components. This issue is related to the question of dimension, which will be addressed in Bases and Dimension.
To construct the coordinate vector for \(\begin{bmatrix}2\\-10\\9\end{bmatrix}\) with respect to \(\mathcal {B}\), we had to be mindful of the order of the elements in \(\mathcal {B}\). Ordinarily, the
order of elements in a set is irrelevant, and the basis
When dealing with coordinate vectors, however, the order of the elements dictates the order of the components of the
coordinate vector coefficients. If we switch the order of the elements in \(\mathcal {B}\), the coordinate vector becomes \(\begin{bmatrix}3\\2\end{bmatrix}\). For this reason,
when we come back to studying coordinate vectors in more detail, we will use the term ordered basis to avoid confusion.
Practice Problems
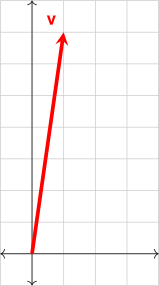
Let \(\mathcal {B}=\left \{\begin{bmatrix}1\\1\end{bmatrix},\begin{bmatrix}-1\\2\end{bmatrix}\right \}\) be a basis for \(\RR ^2\). Find the coordinate vector for \(\vec {v}\) with respect to \(\mathcal {B}\).
Let \(\mathcal {B}=\left \{\begin{bmatrix}1\\1\end{bmatrix},\begin{bmatrix}-1\\2\end{bmatrix}\right \}\) be a basis for \(\RR ^2\). Find the coordinate vector for \(\vec {v}\) with respect to \(\mathcal {B}\).
Let \(\mathcal {B}=\left \{\begin{bmatrix}1\\-1\\3\end{bmatrix},\begin{bmatrix}2\\1\\-1\end{bmatrix}\right \}\) be a basis for \(\mbox {span}\left (\begin{bmatrix}1\\-1\\3\end{bmatrix},\begin{bmatrix}2\\1\\-1\end{bmatrix}\right )\). Find the coordinate vector for \(\begin{bmatrix}-4\\-2\\2\end{bmatrix}\) with respect to \(\mathcal {B}\).
Suppose \(\mathcal {B}=\left \{\begin{bmatrix}1\\1\\1\end{bmatrix},\begin{bmatrix}1\\0\\1\end{bmatrix}, \vec {w}\right \}\) is a basis for \(\RR ^3\). Find \(\vec {w}\) if the coordinate vector for \(\begin{bmatrix}-2\\-7\\4\end{bmatrix}\) is \(\begin{bmatrix}-1\\2\\-3\end{bmatrix}\).