Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
In the last section we considered properties a set of vectors should possess in order to be used to define a
“good” coordinate system for a plane. Let \(S\) be a set of vectors in the plane. We have already established that in
order to use vectors in \(S\) to define the axes of a “good” coordinate system, vectors in \(S\) must span the plane.
This would guarantee that every vector in the plane can be written as a linear combination of elements of
\(S\).
In addition, we observed that we want each vector in the plane to be represented as a unique linear combination of elements
of \(S\). This gives us motivation to consider the question of uniqueness. We will now step away from coordinate systems in the
plane and turn to this question in a more general setting.
Let \(\vec {v}_1, \vec {v}_2,\dots ,\,\vec {v}_k\) be vectors of \(\RR ^n\). Let \(V=\text {span}(\vec {v}_1, \vec {v}_2,\dots ,\,\vec {v}_k)\). Then every vector in \(V\) can be written as a linear combination of \(\vec {v}_1, \vec {v}_2,\dots ,\,\vec {v}_k\) in at least one way. Our
interest here is in spanning sets where each vector in \(V\) has exactly one representation as a linear combination of
\(\vec {v}_1, \vec {v}_2,\dots ,\,\vec {v}_k\).
We are looking for a condition on the set \(\{\vec {v}_1, \vec {v}_2,\dots ,\,\vec {v}_k\}\) that guarantees that this representation is unique. This amounts to showing that \(a_i=b_i\) for
each \(i\). Taking all terms to the left side gives us
So the condition that guarantees uniqueness is that all coefficients \((a_i-b_i)\) must be zero. This motivates the following
definition.
Linear Independence Let \(\vec {v}_1, \vec {v}_2,\ldots ,\vec {v}_k\) be vectors of \(\RR ^n\). We say that the set \(\{\vec {v}_1, \vec {v}_2,\ldots ,\vec {v}_k\}\) is linearly independent if the only solution to
If, in addition to the trivial solution, any non-trivial solutions (not all \(c_1, c_2,\ldots ,c_k\) are zero) exist, then we say that the set \(\{\vec {v}_1, \vec {v}_2,\ldots ,\vec {v}_k\}\) is linearly
dependent.
The trivial solution \(c_1=c_2=\ldots =c_k=0\) is always a solution to \(c_1\vec {v}_1+c_2\vec {v}_2+\ldots +c_p\vec {v}_k=\vec {0}\) because \(0\vec {v}_1+0\vec {v}_2+\ldots +0\vec {v}_k=\vec {0}\). So, when checking for linear independence, the question is not whether
the trivial solution is a solution, but whether it is the ONLY solution.
Given a set of vectors \(X=\{\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\}\) we can now ask the following questions:
1.
Are the vectors in \(X\) linearly dependent according to Definition def:linearindependence?
2.
Can we write one element of \(X\) as a linear combination of the others?
3.
Does \(X\) contain redundant vectors?
It turns out that these questions are equivalent. In other words, if the answer to one of them is “YES", the answer to the other
two is also “YES". Conversely, if the answer to one of them is “NO", then the answer to the other two is also “NO". We will start
by illustrating this idea with an example, then conclude this section by formally proving the equivalency in Theorem th:lindeplincombofother.
What can we say about the following sets of vectors in light of Remark remark:LinIndEquiv?
Using the linear combination in (eq:ex1lincomb) and the argument of Exploration exp:redundantVecs2, we conclude that \(\begin{bmatrix}2\\-3\end{bmatrix}\) is redundant in
This shows that \(c_1=c_2=0\) is the only solution. Therefore the two vectors are linearly independent.
Furthermore, we cannot write one of the vectors as a linear combination of the other. (Do you see that the only way this would
be possible with a set of two vectors is if they were scalar multiples of each other?)
Finally, we observe that removing either vector would change the span from a plane in \(\RR ^3\) to a line in \(\RR ^3\), so the answer to all three
questions in Remark remark:LinIndEquiv is “NO".
Let \(\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\) be a set of vectors in \(\RR ^n\) containing two or more vectors. The following conditions are equivalent.
1.
\(\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\) are linearly dependent.
2.
One of \(\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\) can be expressed as a linear combination of the others.
3.
The set \(\{\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\}\) contains redundant vectors.
has a non-trivial solution. In other words at least one of the constants, say \(c_j\), does not equal zero. This allows us to solve for
\(\vec {v}_j\):
(Do you see why it was important to have one of the constants nonzero?) This shows that \(\vec {v}_j\) may be expressed as a linear
combination of the other vectors.
th:lindeplincombofother_b\(\implies \)th:lindeplincombofother_c First, suppose \(\vec {v}_j\) is a linear combination of \(\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\). We will show that \(\vec {v}_j\) is redundant by showing that
To show equality of the two spans we will pick a vector in the left span and show that it is also an element of the span on the
right. Then, we will pick a vector in the right span and show that it is also an element of the span on the left, and we will
conclude that the sets are equal.
Observe that if \(\vec {w}\) is in \(\mbox {span}\left (\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_{j-1},\vec {v}_{j+1},\dots ,\vec {v}_k\right )\), then it has to be in \(\mbox {span}\left (\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\right )\). (Why?)
Now suppose \(\vec {w}\) is in \(\mbox {span}\left (\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\right )\). We need to show that \(\vec {w}\) is also in \(\mbox {span}\left (\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_{j-1},\vec {v}_{j+1},\dots ,\vec {v}_k\right )\).
This shows that \(\vec {w}\) is in \(\mbox {span}\left (\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_{j-1},\vec {v}_{j+1},\dots ,\vec {v}_k\right )\). We now have
Since the span contains ALL possible linear combinations of \(\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_k\), we may choose \(\vec {w}\) such that
\(a_j\neq 0\).
By assumption, \(\vec {w}\) is also in \(\mbox {span}\left (\vec {v}_1,\vec {v}_2,\dots ,\vec {v}_{j-1},\vec {v}_{j+1},\dots ,\vec {v}_k\right )\). Therefore, we can express \(\vec {w}\) as a linear combination
Recall that we ensured that \(a_j\neq 0\). This implies that we have a non-trivial solution to Equation eq:LinIndepDefRepeated.
These three parts of the proof show that if one of the conditions is true, all three must be true. It is a logical consequence that
if one of the three conditions is false, all three must be false.
Geometry of Linearly Dependent and Linearly Independent Vectors
Theorem 6 gives us a convenient ways of looking at linear dependence/independence geometrically. When looking at two or
more vectors, we ask, “can one of the vectors be written as a linear combination of the others?" We can also ask, “is one
of the vectors redundant?” If the answer to either of these questions is “YES", then the vectors are linearly
dependent.
A Set of Two Vectors
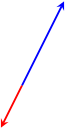
Two vectors are linearly dependent if and only if one is a scalar multiple of the other. Two nonzero linearly dependent vectors
may look like this:
or like this:
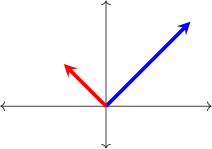
Two linearly independent vectors will look like this:
A Set of Three Vectors
Given a set of three nonzero vectors, we have the following possibilities:
(Linearly Dependent Vectors) The three vectors are scalar multiples of each other.
(Linearly Dependent Vectors) Two of the vectors are scalar multiples of each other.
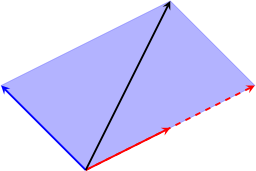
(Linearly Dependent Vectors) One vector can be viewed as the diagonal of a parallelogram determined by scalar
multiples of the other two vectors. All three vectors lie in the same plane.
(Linearly Independent Vectors) A set of three vectors is linearly independent if the vectors do not lie in the same plane.
For example, vectors \(\vec {i}\), \(\vec {j}\) and \(\vec {k}\) are linearly independent.
In a set of two vectors, the only way one could be redundant is if they are scalar multiples of each other.
(True or False?) Any set containing the zero vector is linearly dependent.
TRUE FALSE
Can the zero vector be
removed from the set without changing the span?
(True or False?) A set containing five vectors in \(\RR ^2\) is linearly dependent.
TRUE FALSE
If we rewrite Equation 1 for five
vectors in \(\RR ^2\) as a system of equations, how many equations and unknowns will it have? What does this imply about the number
of solutions?
what (if anything) can we conclude about linear independence of vectors \(\vec {v}_1, \vec {v}_2, \vec {v}_3\)?
The vectors are linearly independent The
vectors are linearly dependent There is not enough information given to make a determination
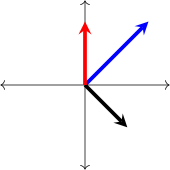
Are the vectors in the diagram linearly dependent or independent?
The vectors are linearly independent The vectors are
linearly dependent There is not enough information given to make a determination
Are the vectors in the diagram linearly dependent or independent?
The vectors are linearly independent The vectors are
linearly dependent There is not enough information given to make a determination
Suppose \(\{\vec {v}_{1}, \dots , \vec {v}_{m}\}\) is a linearly independent set in \(\RR ^n\), and that \(\vec {v}_{m+1}\) is not in \(\mbox {span}\left (\vec {v}_{1}, \dots , \vec {v}_{m}\right )\). Prove that \(\{\vec {v}_{1}, \dots , \vec {v}_{m}, \vec {v}_{m+1}\}\) is also linearly independent.
Suppose \(\{{\vec {u}},{\vec {v}}\}\) is a linearly independent set of vectors. Prove that the set \(\{\vec {u} -\vec {v}, \vec {u}+2\vec {v}\}\) is also linearly independent.
Suppose \(\{{\vec {u}},{\vec {v}}\}\) is a linearly independent set of vectors in \(\RR ^3\). Is the following set dependent or independent \(\{\vec {u} -\vec {v}, \vec {u}+2\vec {v}, \vec {u}+\vec {v}\}\)? Prove your claim.