Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
In Augmented Matrix Notation and Elementary Row Operations, we learned to write linear systems in augmented matrix form
and use elementary row operations to transform an augmented matrix to row-echelon form and the reduced row-echelon form
in order to solve linear systems.
Recall that a matrix (or augmented matrix) is in row-echelon form if:
All entries below each leading entry are \(0\).
Each leading entry is in a column to the right of the leading entries in the rows above it.
All rows of zeros, if there are any, are located below non-zero rows.
A matrix in row-echelon form is said to be in reduced row-echelon form if it has the following additional properties
Each leading entry is a \(1\)
All entries above each leading \(1\) are \(0\)
Matrices in row-echelon form and reduced row-echelon form are “convenient" because their corresponding systems of
equations are easy to solve.
In this module we turn to the question of existence and uniqueness of the two echelon forms. Can every matrix (augmented
matrix) be carried to a row-echelon form? If so, is the row-echelon form unique? Can every matrix be reduced to a reduced
row-echelon form? If so, is the reduced row-echelon form unique? The answers we find will have long-lasting
implications.
Note that the elementary row operations that lead to (1) were not prescribed. We may employ row-operations in a different
manner and obtain a different matrix in row-echelon form. For example, suppose for some reason we had begun by switching
the first and third rows.
Do you think it is possible to start with (2) and obtain the same reduced row-echelon form? Try to justify your
response. If possible, find the elementary row operations that take (2) to the reduced row-echelon form in
(3).
You will be asked to fill in the elementary row operations in Practice Problem ??.
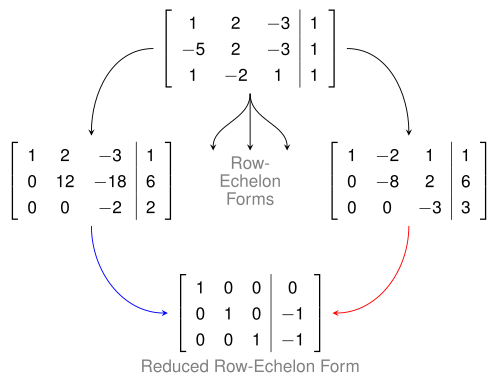
Our observations in Exploration are summarized in the following diagram.
We observed that a row-echelon form associated with a matrix is not unique. In contrast, we also saw how different
sequences of elementary row operations lead to the same solution set and the same reduced row-echelon form. It turns out
that the reduced row-echelon form of a matrix is unique.
The reduced row-echelon form of a matrix is unique.
A proof of this result can be found in [Yuster].
The reduced row-echelon form of a matrix is an instance of a row-echelon form of the matrix. While a given
matrix may have multiple row-echelon forms, all row-echelon forms will share one characteristic: the number of
nonzero rows in a row-echelon form of the given matrix will be the same. We will prove this result in Theorem
??
.
Gaussian and Gauss-Jordan Elimination
Gaussian Elimination The process of using the elementary row operations on a matrix to transform it into row-echelon form is
called Gaussian Elimination.
As we saw in the previous section, it is possible to follow different sequences of row operations to arrive at various
row-echelon forms. However, it was not clear whether it is always possible to find a row-echelon form. The following algorithm
takes any matrix (or augmented matrix) and transforms it into row-echelon form:
Gaussian Algorithm Let \(A\) be an \(m\times n\)
matrix.
Set \(i=1\) initially.
Step 1. If \(A\) consists entirely of zeros, stop; \(A\) is already in row-echelon form.
Step 2. Otherwise, find the first column from the left containing a nonzero entry in row \(i\) or below row \(i\). This
column will be called a pivot column. Go down the pivot column, beginning with row \(i\). Pick the topmost nonzero
entry and call it \(a\). If \(a\) is not in row \(i\), switch rows so that \(a\) moves to row \(i\). Now \(a\) is the leading entry in its row. We
will also refer to \(a\) as a pivot.
Step 3. By subtracting multiples of the row containing \(a\) from rows below it, make each entry below \(a\) zero.
Step 4. Set \(i=i+1\). If \(i>m\) then stop; \(A\) is in row-echelon form.
Repeat steps 1–4 on the matrix consisting of the remaining rows. When the process stops, \(A\) will be in row echelon form.
Gaussian Algorithm guarantees that every matrix will have a row-echelon form.
Use the Gaussian Algorithm to find a row-echelon form of \(A\) if
Following Step 2, we choose the first entry, \(2\), as our pivot. We then perform step 3, using the top row to get zeros in all entries
below the \(2\).
The first row is now complete, and we repeat the process on the rows below it. We identify \(3\) as a pivot entry in the second
column and move the row containing \(3\) to be directly below the first completed row. We then use the \(3\) to make each entry below
the \(3\) a zero.
This time the algorithm terminates since row 3 and row 4 are zero rows.
Gauss-Jordan Elimination The process of using the elementary row operations on a matrix to transform it into reduced
row-echelon form is called Gauss-Jordan elimination.
Given a matrix in row-echelon form, it is easy to bring it the reduced row-echelon form. For example, continuing with Example
4, we can start where we left off and compute \(\mbox {rref}(A)\). From our earlier computations we have:
The following modification to the Gaussian Algorithm produces the reduced row-echelon form of a matrix. This algorithm
guarantees the existence of the reduced row-echelon form.
Gauss-Jordan Algorithm Let \(A\) be an \(m\times n\) matrix. Follow the steps of the Gaussian Algorithm but modify Step 2 to create leading \(1's\)
by multiplying the row containing \(a\) by \(\frac {1}{a}\).
When the Gaussian Algorithm terminates, subtract multiples of the rows containing leading \(1's\) from the rows above to make all
entries above the pivots zero.
Use the Gauss-Jordan Algorithm to solve the system
We convert the reduced row-echelon form to a system of equations and find the solution. The last equation contributes
nothing to the system so we omit writing it down.
\[\begin{array}{ccccccccc} x & &&+&3z&= &2 \\ & &y&-&2z&=&1 \end{array}\]
The solution is
\[x=2-3t,\quad y=1+2t,\quad z=t\]
The Gauss-Jordan Algorithm guarantees the existence of the reduced row-echelon form for all matrices.
When doing computations by hand, however, the algorithm may not always be the optimal method of finding a
row-echelon form or the reduced row-echelon form because the procedure often leads to fractions early in the
process. The following video shows how to arrive at the same reduced row-echelon form for the matrix in
Example 8 without doing any fraction arithmetic. You will see that we still employ row operations, but in a different
order.
The video highlights the fact that regardless of what sequence of elementary row operations we take to arrive at the reduced
row-echelon form, the end result is the same.
Rank
As stated in Theorem 1, the reduced row-echelon form of a matrix \(A\) is uniquely determined by \(A\). That is, no matter which series
of row operations is used to transform \(A\) to its reduced row-echelon matrix, the result will always be the same matrix. In
contrast, this is not true for row-echelon matrices: different sequences of row operations can transform the same matrix \(A\) to
different row-echelon matrices. However, it is true that the number \(r\) of nonzero rows must be the same in each of these
row-echelon matrices, as we will see in Theorem ??. Hence, the number \(r\) depends only on \(A\) and not on the way in which \(A\) is
carried to row-echelon form.
Matrices (1) and (2) of Exploration are both row-echelon forms of \(A\). Both matrices have three nonzero rows. The same is true
for \(\mbox {rref}(A)\).
The rank of matrix \(A\), denoted by \(\mbox {rank}(A)\), is the number of nonzero rows that remain after we reduce \(A\) to row-echelon form by
elementary row operations.
Because the row-echelon form has two nonzero rows, \(\mbox {rank}(A) = 2\).
Suppose a system of \(m\) equations in \(n\) variables is consistent, and that the rank of the coefficient matrix is \(r\).
1.
The set of solutions involves exactly \(n - r\) parameters, corresponding to \(n-r\) free variables.
2.
If \(r < n\), the system has infinitely many solutions.
3.
If \(r = n\), the system has a unique solution.
The fact that the rank of the coefficient matrix is \(r\) means that there are exactly \(r\) leading variables in the coefficient matrix,
and hence exactly \(n - r\) nonleading variables. The nonleading variables are called free variables. All free variables
are assigned parameters, so the set of solutions involves exactly \(n - r\) parameters. Hence if \(r < n\), there is at least one
parameter, and so infinitely many solutions. If \(r = n\), there are no parameters and the resulting solution is unique.
Theorem 14 shows that, for any system of linear equations, exactly three possibilities exist:
1.
Unique solution. This occurs when every variable is a leading variable.
2.
Infinitely many solutions. This occurs when the system is consistent and there is at least one nonleading
variable, so at least one parameter is involved.
3.
No solution. This occurs when a row \(\left [\begin{array}{cccc|c} 0&0&\ldots &0&1 \end{array}\right ]\) appears in the row-echelon form. Such a row corresponds to an equation
with no solutions. (See Example ??.)
Practice Problems
Follow the indicated steps of the Gauss-Jordan algorithm to transform the matrix to its reduced row-echelon form. Steps will
unfold automatically as you enter correct answers.
The following reduction steps do not follow the algorithm but are easier for a human to carry out because they use fewer
fractions. Follow the indicated steps to transform the matrix to its reduced row-echelon form. Steps will unfold automatically as
you enter correct answers.
Suppose a linear system has \(4\) equations and \(5\) unknowns. Which of the following is NOT a possibility?
The system has a
unique solution The system has no solutions The system has infinitely many solutions
Suppose \(A\) is a matrix such that \(\mbox {rref}(A)\) has \(5\) leading \(1's\). What do we know to be true about \(A\)? Select ALL that apply.
\(\mbox {rank}(A)=5\)\(A\)
has at least \(25\) entriesAny row-echelon form of \(A\) will have exactly \(5\) nonzero rowsSome row-echelon forms
of \(A\) may have more than \(5\) nonzero rowsSome row-echelon forms of \(A\) may have fewer than \(5\) nonzero rows
In this problem we will consider how the rank of the coefficient matrix associated with a linear system compares to the rank
of the augmented matrix associated with the system.
1.
Explain why the rank of the augmented matrix has to be greater than or equal to the rank of the coefficient
matrix.
2.
Prove that for a consistent system the rank of the coefficient matrix will be the same as the rank of the
augmented matrix.
3.
Give an example of an inconsistent system for which the rank of the augmented matrix is greater than the rank
of the coefficient matrix.
4.
Can the rank of an augmented matrix be greater than the number of variables?
5.
Is the following statement true?
“If the rank of the augmented matrix associated with a linear system is greater than the rank of the coefficient
matrix, then the system is inconsistent."
W. Keith Nicholson, Linear Algebra with Applications, Lyryx 2018, Open Edition, p 15-17.
Bibliography
[Yuster] Thomas Yuster, The Reduced Row Echelon Form of a Matrix is Unique: a Simple Proof, Mathematics Magazine, vol.
57, no. 2 (Mar. 1984), pp. 93-94.