Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
Often an exact solution to a problem in applied mathematics is difficult or impossible to obtain. However, it is usually just as
useful to find an approximation to a solution. In particular, finding “linear approximations" is a powerful technique in applied
mathematics. One basic case is the situation where a system of linear equations has no solution, and it is desirable to find a
“best approximation" to a solution to the system.
We begin by defining the “best approximation” in a natural way, and showing that computing the best approximation reduces
to solving a related system of linear equations called the normal equations. Next, we demonstrate a common application
where a collection of data points is approximated by a line (or a curve). We conclude this section by showing
that \(QR\)-factorization provides us with a more efficient way to solve the normal equations and compute the best
approximation.
Consider the matrix equation \(A\vec {x}=\vec {b}\). A quick examination of the last two rows should convince you that this equation has no
solutions. In other words, \(\vec {b}\) is not in the span of the columns of \(A\).
If \(\vec {z}\) were an exact solution to \(A\vec {x}=\vec {b}\), then \(\vec {b}-A\vec {z}\) would be \(\vec {0}\). Since the equation does not have a solution, we will attempt to
find the next best thing to a solution by finding \(\vec {z}\) such that \(\norm {\vec {b}-A\vec {z}}\) is as small as possible. The quantity \(\norm {\vec {b}-A\vec {z}}\) is called the
error.
The following GeoGebra interactive will help you understand the geometry behind finding \(\vec {z}\).
RIGHT-CLICK and DRAG to rotate the image for a better view.
Record your best guess for \(\vec {z}\) – you will have a chance to check your answer in Example 2.
What did you discover about the geometry of minimizing \(\norm {\vec {b}-A\vec {z}}\)? Select all that apply.
\(\vec {z}\) is orthogonal to the plane spanned by the columns of \(A\).\(\norm {\vec {b}-A\vec {z}}\) is orthogonal to \(\text {col}(A)\).\(\vec {b}-A\vec {z}\) is orthogonal to \(\text {col}(A)\).\(A\vec {z}\) is orthogonal to \(\text {col}(A)\).\(A\vec {z}\) is an
orthogonal projection of \(\vec {b}\) onto \(\text {col}(A)\).
Our geometric observations will help us develop a method for finding \(\vec {z}\) .
Suppose \(A\) is an \(m\times n\) matrix, and \(\vec {b}\) is a column vector in \(\RR ^m\). Consider the matrix equation \(A\vec {x}=\vec {b}\). If this equation does not have a solution, we
can attempt to find a best approximation by finding \(\vec {z}\) which minimizes the error, \(\norm {\vec {b}-A\vec {z}}\). The expression \(\norm {\vec {b}-A\vec {z}}\) is also sometimes called the
residual. The error (or the residual) is given in terms of a vector norm. Recall that our definition of the norm involves the sum
of squares of the vector components. When we minimize the norm, we minimize the sum of squares. This is why the
method we are describing is often referred to as least squares. We will explore this idea further later in this
section.
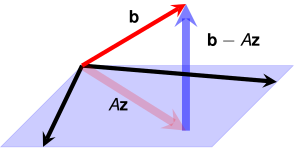
In the case when \(\text {col}(A)\) is a subspace of \(\RR ^3\), we can see geometrically that \(\vec {z}\) is the best approximation if and only if \(A\vec {z}\) is an orthogonal
projection of \(\vec {b}\) onto \(\text {col}(A)\), and the error is the magnitude of \(\vec {b}-A\vec {z}\), as shown below.
What we observed above, holds in general. We will use this fact to find \(\vec {z}\).
Every vector in \(\text {col}(A)\) can be written in the form \(A\vec {x}\) for some \(\vec {x}\) in \(\RR ^m\). Our goal is to find \(\vec {z}\) such that \(A\vec {z}\) is the orthogonal projection of \(\vec {b}\) onto \(\text {col}(A)\). By
Corollary ??, every vector \(A\vec {x}\) in \(\text {col}(A)\) is orthogonal to \(\vec {b}-A\vec {z}\).
Since \(\vec {b}-A\vec {z}\) is normal to the subspace \(\text {col}(A)\), we call the system of linear equations in (??) the normal equations for\(\vec {z}\). If \(A^TA\) is invertible,
then we can write
Compare this answer to your guess in Exploration . If your guess was correct, nice job! If your guess was different, try setting \(\vec {z}\)
to the correct answer and use the GeoGebra interactive in Exploration to examine the geometry of the problem.
We now come back to the question of when \(A^TA\) is invertible.
If columns of matrix \(A\) are linearly independent, then \(A^TA\) is invertible.
Let \(A\) be a matrix with linearly independent columns. We will show that \(\left (A^TA\right )\vec {x}=\vec {0}\) has only the trivial solution. For \(\vec {x}\), a solution of \(A^TA\vec {x}=\vec {0}\), we have
The average number \(g\) of goals per game scored by a hockey player seems to be related linearly to two factors: the number \(x_1\) of
years of experience and the number \(x_2\) of goals in the preceding 10 games. The data on the following page were collected on
four players. Find the linear function \(g=a_0+a_1x_1+a_2x_2\) that best fits the data.
Hence the best-fitting function is \(g=0.14+0.09x_1+0.08x_2\).
Application of Least Squares to Curve Fitting
In Curve Fitting, we discussed how to fit a function to a set of data points, so that the graph of the function passes through
each of the points. We also discussed why doing so is sometimes impossible (two points lie one above the
other), and may not even be desirable (overfitting). In this section we will learn how to approximate a collection
of data points with a line (or a curve) that fits the “trend" of the points. We will start with data that fit a linear
pattern.
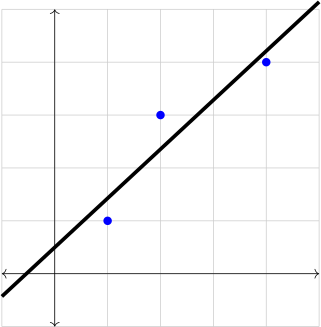
Consider the points \((1,1)\), \((2, 3)\) and \((4,4)\). These points do not lie on a straight line, but they have a general upward linear trend. (Typically
there would be many more points to consider, but we will limit our exploration to what we can do by hand.) Our goal is to find a
line that fits these points as closely as possible.
We are looking for a function \(f\) of the form \(f(x)=ax+b\) such that the following infeasible system is satisfied as closely as
possible
According to our computations, the line that best fits the data is given by
\[f(x)=\frac {13}{14}x+\frac {1}{2}\]
Let’s take a look.
We found this fit by minimizing \(\norm {\vec {b}-A\vec {z}}\). We will now investigate the meaning of this expression in relation to the line and the
data points.
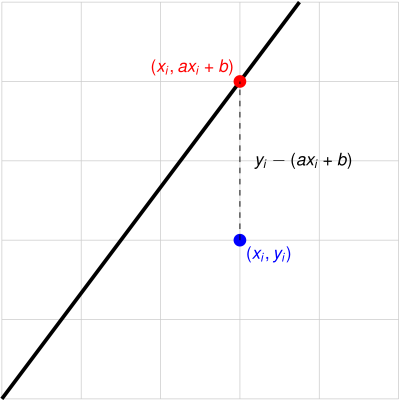
Minimizing \(\norm {\vec {b}-A\vec {z}}\) also minimizes \(\norm {\vec {b}-A\vec {z}}^2\). Therefore, what we have minimized is the sum of squares of the vertical distances between the
data points and the line. The following GeoGebra interactive will help you explore this idea.
In Exploration we discovered that \(\norm {\vec {b}-A\vec {z}}^2\) is the sum of squares of vertical distances between the given data points and the proposed
line. By minimizing \(\norm {\vec {b}-A\vec {z}}\), we minimize the sum of squares of vertical distances. This observation holds in general. Given a
collection of points \((x_1, y_1), (x_2, y_2),\dots ,(x_n, y_n)\), finding a linear function of the form \(f(x)=ax+b\) that best fits the points we would find a best solution to the
system
Find a linear function of best fit for the given set of data points. Examine how well your line fits the points by typing the
equation of the line into the Desmos window.
Find a linear function of best fit for the given set of data points. Examine how well your line fits the points by typing the
equation of the line into the Desmos window.
\[(-2, 3), (-1,1), (0,0), (1, -2), (2, -4)\]
\[f(x)=\answer {-1.7}x+\answer {-0.4}\]
Use Octave to find the least squares approximating quadratic function for the following data points.