Je bent je ingevulde velden bij deze pagina aan het verwijderen. Ben je zeker dat je dit wilt doen?
You are erasing your filled-in fields on this page. Are you sure that is what you want?
Nieuwe Versie BeschikbaarNew Version Available
Er is een update van deze pagina. Als je update naar de meest recente versie, verlies je mogelijk je huidige antwoorden voor deze pagina. Hoe wil je verdergaan ?
There is an updated version of this page. If you update to the most recent version, then your current progress on this page will be erased. Regardless, your record of completion will remain. How would you like to proceed?
Existence of the Inverse of a Linear Transformation
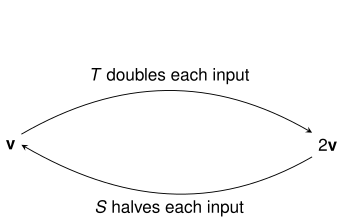
In Exploration ep:inverse of Composition and Inverses of Linear Transformations we examined a linear transformation \(T:\RR ^2\rightarrow \RR ^2\) that doubles all
input vectors, and its inverse \(S:\RR ^2\rightarrow \RR ^2\), that halves all input vectors. We observed that the composite functions \(S\circ T\) and \(T\circ S\) are both identity
transformations. Diagrammatically, we can represent \(T\) and \(S\) as follows:
This gives us a way of thinking about an inverse of \(T\) as a transformation that “undoes" the action of \(T\) by “reversing" the mapping
arrows. We will now use these intuitive ideas to understand which linear transformations are invertible and which are
not.
Given an arbitrary linear transformation \(T:V\rightarrow W\), “reversing the arrows" may not always result in a transformation. Recall that
transformations are functions. The figures below show two ways in which our attempt to “reverse" \(T\) may fail to produce a
function.
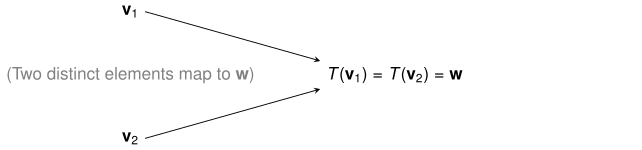
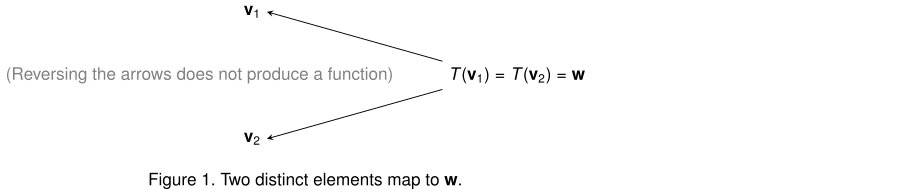
First, if two distinct vectors \(\vec {v}_1\) and \(\vec {v}_2\) map to the same vector \(\vec {w}\) in \(W\), then reversing the arrows gives us a mapping that is clearly not
a function.
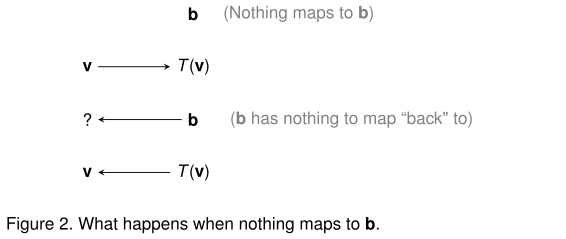
Second, observe that our definition of an inverse of \(T:V\rightarrow W\) requires that the domain of the inverse transformation be \(W\). (Definition def:inverse,
Composition and Inverses of Linear Transformations) If there is a vector \(\vec {b}\) in \(W\) that is not an image of any vector in \(V\), then \(\vec {b}\) cannot
be in the domain of an inverse transformation.
We now illustrate these potential issues with specific examples.
Let \(T:\RR ^2\rightarrow \RR ^2\) be a linear transformation whose standard matrix is
\[\begin{bmatrix}1&1\\2&2\end{bmatrix}\]
Does \(T\) have an inverse? Show that multiple vectors of the domain map to \(\vec {0}\) in the codomain.
The matrix \(\begin{bmatrix}1&1\\2&2\end{bmatrix}\) is not invertible, so \(T\) does not have an inverse.
We now dig a little deeper to get additional insights into why \(T\) does not have an inverse. Observe that all vectors of the form \(\begin{bmatrix}k\\-k\end{bmatrix}\)
map to \(\vec {0}\). To verify this, use matrix multiplication:
This shows that there are infinitely many vectors that map to \(\vec {0}\). So, “reversing the arrows" would not result in a function. (See
Figure 1)
Let \(T:\RR ^2\rightarrow \RR ^3\) be a linear transformation whose standard matrix is
\[\begin{bmatrix}1&0\\0&1\\2&0\end{bmatrix}\]
Does \(T\) have an inverse? Show that there exists a vector \(\vec {b}\) in \(\RR ^3\) such that no vector of \(\RR ^2\) maps to \(\vec {b}\).
The matrix \(\begin{bmatrix}1&0\\0&1\\2&0\end{bmatrix}\) is not invertible (it’s
not even a square matrix!), so \(T\) does not have an inverse.
We now get another insight into why \(T\) is not invertible. To find a vector \(\vec {b}\) such that no vector of \(\RR ^2\) maps to \(\vec {b}\), we need to find \(\vec {b}\) for
which the matrix equation
Equation (ex:matrix) has a solution if and only if \(b_3-2b_1=0\). Since we do not want (ex:matrix) to have a solution, all we need to do is pick values \(b_1\), \(b_2\) and \(b_3\)
such that \(b_3-2b_1\neq 0\). Let \(\vec {b}=\begin{bmatrix}1\\1\\1\end{bmatrix}\). Then no element of \(\RR ^2\) maps to \(\vec {b}\). This shows that we cannot “reverse the arrows" in an attempt to produce an
inverse of \(T\). (See Figure 2)
Our next goal is to develop vocabulary that would allow us to discuss issues illustrated in Figures \(1\) and \(2\).
One-to-one Linear Transformations
Figure \(1\) gave us a diagrammatic representation of a transformation that maps two distinct elements, \(\vec {v}_1\) and \(\vec {v}_2\)
to the same element \(\vec {w}\), making it impossible for us to “reverse the arrows" in an attempt to find the inverse
transformation. Based on this example, it is reasonable to conjecture that for a transformation to be invertible, the
transformation must be such that each output is the image of exactly one input. Such transformations are called
one-to-one.
One-to-One A linear transformation \(T:V\rightarrow W\) is one-to-one if
The transformation in Figure \(1\) is not one-to-one because \(\vec {v}_1\) and \(\vec {v}_2\) map to the same vector \(\vec {w}\), (i.e. \(T(\vec {v}_1)=T(\vec {v}_2)\)), yet the diagram suggests that
\(\vec {v}_1\neq \vec {v}_2\).
Transformation \(T\) in Example 1 is not one-to-one.
We can use any two vectors of the form \(\begin{bmatrix}k\\-k\end{bmatrix}\) to make our case.
In other words, we have more than one vector that maps to the zero vector.
Example 6 provides us with an important insight. Recall that the collection of all vectors that map to zero under a linear
transformation constitute the kernel of the linear transformation. (See Image and Kernel of a Linear Transformation) It is clear
that when \(\text {ker}(T)\neq \{\vec {0}\}\) the transformation is not one-to-one. This implication goes the other way as well. In Problem you will show that a
linear transformation \(T\) is one-to-one if and only if \(\text {ker}(T)=\{\vec {0}\}\).
Prove that the transformation in Example 3 is one-to-one.
It is clear that \(\begin{bmatrix}1\\0\\2\end{bmatrix}\) and \(\begin{bmatrix}0\\1\\0\end{bmatrix}\) are linearly independent. Therefore, we must have \(x_1-y_1=0\) and \(x_2-y_2=0\). But then \(x_1=y_1\) and \(x_2=y_2\), so
Since transformation in Example 3 is one-to-one but not invertible we can conjecture that being one-to-one is a necessary, but
not a sufficient condition for a linear transformation to have an inverse. We will consider the other necessary condition
next.
“Onto" Linear Transformations
Figure \(2\) makes a convincing case that for a transformation to be invertible every element of the codomain must have
something mapping to it. Transformations such that every element of the codomain is an image of some element of the
domain are called onto.
Onto A linear transformation \(T:V\rightarrow W\) is onto if for every element \(\vec {w}\) of \(W\), there exists an element \(\vec {v}\) of \(V\) such that \(T(\vec {v})=\vec {w}\).
No element of \(\RR ^2\) maps to \(\begin{bmatrix}1\\1\\1\end{bmatrix}\).
Prove that the linear transformation \(T:\RR ^2\rightarrow \RR ^2\) whose standard matrix is
\[A=\begin{bmatrix}1&0\\2&1\end{bmatrix}\]
is onto.
Let \(\vec {b}\) be an element of the codomain (\(\RR ^2\)). We need to find \(\vec {x}\) in the domain (\(\RR ^2\)) such that \(T(\vec {x})=\vec {b}\). Observe that \(A\) is invertible,
and
\[A^{-1}=\begin{bmatrix}1&0\\-2&1\end{bmatrix}\]
Let \(\vec {x}=\begin{bmatrix}1&0\\-2&1\end{bmatrix}\vec {b}\), then
Prove that the linear transformation \(T:\RR ^3\rightarrow \RR ^2\) induced by
\[A=\begin{bmatrix}1&1&-1\\2&3&-1\end{bmatrix}\]
is onto.
Let \(\vec {b}\) be an element of \(\RR ^2\). We need to show that there exists \(\vec {x}\) in \(\RR ^3\) such that \(T(\vec {x})=A\vec {x}=\vec {b}\). Observe that
This means that \(A\vec {x}=\vec {b}\) has a solution (in fact, it has infinitely many solutions) for every \(\vec {b}\) in \(\RR ^2\). Therefore every \(\vec {b}\) in \(\RR ^2\) is an image of some
\(\vec {x}\) in \(\RR ^3\). We conclude that \(T\) is onto.
We will now show that \(T\) is one-to-one. Suppose
\[T(\vec {u})=T(\vec {v})\]
for some \(\vec {u}\) and \(\vec {v}\) in \(V\). Vectors \(\vec {u}\) and \(\vec {v}\) are in the span of \(\begin{bmatrix}1\\0\\0\end{bmatrix}\) and \(\begin{bmatrix}1\\1\\1\end{bmatrix}\), so
This implies that \(a=c\) which, in turn, implies \(b=d\). This gives us \(\vec {u}=\vec {v}\), and we conclude that \(T\) is one-to-one.
Next we will show that \(T\) is onto. The key observation is that vectors \(\begin{bmatrix}1\\1\end{bmatrix}\) and \(\begin{bmatrix}0\\1\end{bmatrix}\) span \(\RR ^2\). This means that given a vector \(\vec {v}\) in \(\RR ^2\), we can
write \(\vec {v}\) as \(\vec {v}=a\begin{bmatrix}1\\1\end{bmatrix}+b\begin{bmatrix}0\\1\end{bmatrix}\). But this means that \(\vec {v}=T\left (a\begin{bmatrix}1\\0\\0\end{bmatrix}+b\begin{bmatrix}1\\1\\1\end{bmatrix}\right )\) We conclude that \(T\) is onto.
Existence of Inverses
Let \(V\) and \(W\) be vector spaces, and let \(T:V\rightarrow W\) be a linear transformation. Then \(T\) has an inverse if and only if \(T\) is one-to-one and onto.
We will first assume that \(T\) is one-to-one and onto, and show that there exists a transformation \(S:W\rightarrow V\) such that \(S\circ T=\id _V\) and \(T\circ S=\id _W\). Because \(T\) is
onto, for every \(\vec {w}\) in \(W\), there exists \(\vec {v}\) in \(V\) such that \(T(\vec {v})=\vec {w}\). Moreover, because \(T\) is one-to-one, vector \(\vec {v}\) is the only vector that maps to \(\vec {w}\). To
stress this, we will say that for every \(\vec {w}\), there exists \(\vec {v}_{\vec {w}}\) such that \(T(\vec {v}_{\vec {w}})=\vec {w}\). (Since every \(\vec {v}\) maps to exactly one \(\vec {w}\), this notation makes sense
for elements of \(V\) as well.) We can now define \(S:W\rightarrow V\) by \(S(\vec {w})=\vec {v}_{\vec {w}}\). Then
Definition ?? of Composition and Inverses of Linear Transformations refers to \(S\) as an inverse of \(T\), implying that
there may be more than one such transformation \(S\). We will now show that if such a transformation \(S\) exists, it is
unique. This will allow us to refer to it as the inverse of \(T\) and to start using \(T^{-1}\) to denote the unique inverse of
\(T\).
If \(T\) is a linear transformation, and \(S\) is an inverse of \(T\). Then \(S\) is unique.
Let \(T:V\rightarrow W\) be a linear transformation. If \(S\) is an inverse of \(T\), then \(S\) satisfies
Show that \(T\) is a linear transformation that has an inverse.
You will need to demonstrate that \(T\) is one-to-one and onto.
Let \(V=\text {span}\left (\begin{bmatrix}1\\0\\1\end{bmatrix}, \begin{bmatrix}0\\1\\0\end{bmatrix}\right )\). Define a linear transformation \(T:V\rightarrow \RR ^2\) by
 Linear Algebra: An Interactive Introduction