 PreCalculus
- Verberg vooruitgang Hide progress Toon vooruitgang Show progress
- Verwijder je antwoorden (op deze pagina) Remove your answers (on this page)
PreCalculusIn this section, we revisit our friends the Conic Sections which we began studying in Section IntrotoConics. Our first task is to formalize the notion of rotating axes so this subsection is actually a follow-up to Example rotationmatrixex in Section MatArithmetic. In that example, we saw that the graph of \(y = \frac {2}{x}\) is actually a hyperbola.
More specifically, the graph of \(y = \frac {1}{x}\) is the hyperbola obtained by rotating the graph of \(x^2-y^2=4\) counter-clockwise through a \(45^{\circ }\) angle. Armed with polar coordinates, we can generalize the process of rotating axes as shown below.
Consider the \(x\)- and \(y\)-axes below along with the dashed \(x'\)- and \(y'\)-axes obtained by rotating the \(x\)- and \(y\)-axes counter-clockwise through an angle \(\theta \) and consider the point \(P(x,y)\). The coordinates \((x,y)\) are rectangular coordinates and are based on the \(x\)- and \(y\)-axes.
Suppose we wished to find rectangular coordinates based on the \(x'\)- and \(y'\)-axes. That is, we wish to determine \(P(x',y')\). While this seems like a formidable challenge, it is nearly trivial if we use polar coordinates.
Consider the angle \(\phi \) whose initial side is the positive \(x'\)-axis and whose terminal side contains the point \(P\). We relate \(P(x,y)\) and \(P(x',y')\) by converting them to polar coordinates.

Converting \(P(x,y)\) to polar coordinates with \(r > 0\) yields \(x = r\cos (\theta + \phi )\) and \(y = r\sin (\theta + \phi )\). To convert the point \(P(x',y')\) into polar coordinates, we first match the polar axis with the positive \(x'\)-axis, choose the same \(r>0\) (since the origin is the same in both systems) and get \(x' = r\cos (\phi )\) and \(y' = r\sin (\phi )\).
Using the sum formulas for sine and cosine, we have
Similarly, using the sum formula for sine we get \(y = x'\sin (\theta ) + y'\cos (\theta )\). These equations enable us to easily convert points with \(x'y'\)-coordinates back into \(xy\)-coordinates. They also enable us to easily convert equations in the variables \(x\) and \(y\) into equations in the variables in terms of \(x'\) and \(y'\).
If we want equations which enable us to convert points with \(xy\)-coordinates into \(x'y'\)-coordinates, we need to solve the system
for \(x'\) and \(y'\). Perhaps the cleanest way to solve this system is to write it as a matrix equation. Using the machinery developed in Section MatMethods, we write the above system as the matrix equation \(AX' = X\) where
Since \(\det (A) = (\cos (\theta ))(\cos (\theta )) - (-\sin (\theta ))(\sin (\theta )) = \cos ^{2}(\theta ) + \sin ^{2}(\theta ) = 1\), the determinant of \(A\) is not zero so \(A\) is invertible and \(X' = A^{-1}X\). Using the formula given in Equation 2by2inverse with \(\det (A) = 1\), we find
so that
From which we get \(x' = x \cos (\theta ) + y\sin (\theta )\) and \(y'=- x \sin (\theta ) + y\cos (\theta )\). To summarize,
We put the formulas in Theorem rotatecoordinatesthm to good use in the following example.
If \(P(x,y) = (2,-4)\) then \(x=2\) and \(y=-4\). Using these values for \(x\) and \(y\) along with \(\theta = \frac {\pi }{3}\), Theorem rotatecoordinatesthm gives \(x' = x \cos (\theta ) + y \sin (\theta ) = 2 \cos \left (\frac {\pi }{3}\right ) + (-4)\sin \left (\frac {\pi }{3}\right )\) which simplifies to \(x' = 1-2\sqrt {3}\).
Similarly, \(y' = -x\sin (\theta ) + y\cos (\theta ) = (-2)\sin \left (\frac {\pi }{3}\right ) + (-4)\cos \left (\frac {\pi }{3}\right )\) which gives \(y' = -\sqrt {3}-2 = -2-\sqrt {3}\). Hence \(P(x',y') = \left (1-2\sqrt {3}, -2-\sqrt {3}\right )\).
To check our answer algebraically, we convert \(P(x',y') = \left (1-2\sqrt {3},-2-\sqrt {3}\right )\) back into \(x\) and \(y\) coordinates using the formulas in Theorem rotatecoordinatesthm. We get
Similarly, using \(y = x'\sin (\theta ) + y'\cos (\theta )\), we obtain \(y = -4\) as required.
To check our answer graphically, we sketch in the \(x'\)-axis and \(y'\)-axis to see if the new coordinates \(P(x',y') = \left (1-2\sqrt {3},-2-\sqrt {3}\right ) \approx (-2.46,-3.73)\) seem reasonable. Our graph is below.

To convert the equation \(21x^2+10xy\sqrt {3}+31y^2=144\) to an equation in the variables \(x'\) and \(y'\), we substitute \(x = x' \cos \left (\frac {\pi }{3}\right ) - y' \sin \left (\frac {\pi }{3}\right ) = \frac {x'}{2} - \frac {y'\sqrt {3}}{2}\) and \(y = x'\sin \left (\frac {\pi }{3}\right ) + y'\cos \left (\frac {\pi }{3}\right ) = \frac {x'\sqrt {3}}{2} + \frac {y'}{2}\).
While this is by no means a trivial task, it is nothing more than a hefty dose of Intermediate Algebra. While we leave most of the details to the reader, a good starting point is to verify:
To our surprise and delight, the equation \(21x^2+10xy\sqrt {3}+31y^2=144\) in \(xy\)-coordinates reduces to \(36(x')^2 + 16(y')^2 = 144\), or \(\frac {(x')^2}{4} + \frac {(y')^2}{9} = 1\) in \(x'y'\)-coordinates.
That is, the curve is an ellipse centered at \((0,0)\) with vertices along the \(y'\)-axis with (\(x'y'\)-coordinates) \((0, \pm 3)\) and whose minor axis has endpoints with (\(x'y'\)-coordinates) \((\pm 2, 0)\) as seen below.

Thanks to the elimination of the \(xy\)’ term from the equation \(21x^2+10xy\sqrt {3}+31y^2=144\) in Example rotatedaxesex1 number rotatedellipseex, we were able to graph the equation on the \(x'y'\)-plane using what we know from Section Ellipses.
It is natural to wonder if, given an equation of the form \(Ax^2 + Bxy +Cy^2 + Dx + Ey + F = 0\), with \(B \neq 0\), is there an angle \(\theta \) so that if we rotate the \(x\) and \(y\)-axes counter-clockwise through that angle \(\theta \), the equation in the rotated variables \(x'\) and \(y'\) contains no \(x'y'\) term.
To find out, we make the usual substitutions \(x = x' \cos (\theta ) - y' \sin (\theta )\) and \(y = x'\sin (\theta ) + y'\cos (\theta )\) into the equation \(Ax^2 + Bxy +Cy^2 + Dx + Ey + F = 0\) and set the coefficient of the \(x'y'\) term equal to \(0\).
Terms containing \(x'y'\) in this expression will come from the first three terms of the equation: \(Ax^2\), \(Bxy\) and \(Cy^2\). We leave it to the reader to verify that
The contribution to the \(x'y'\)-term from \(Ax^2\) is \(-2A\cos (\theta ) \sin (\theta )\), from \(Bxy\) it is \(B \left (\cos ^{2}(\theta )-\sin ^2(\theta )\right )\), and from \(Cy^2\) it is \(2C \cos (\theta ) \sin (\theta )\). Equating the \(x'y'\)-term to \(0\), we get
From this, we get \(B \cos (2\theta ) = (A-C)\sin (2\theta )\). Our goal is to solve for \(\theta \) in terms of \(A\), \(B\) and \(C\).
Since we are assuming \(B \neq 0\), we can divide both sides of this equation by \(B\). To solve for \(\theta \) we would like to divide both sides of the equation by \(\sin (2\theta )\), provided of course that we have assurances that \(\sin (2\theta ) \neq 0\).
If \(\sin (2\theta ) = 0\), then we would have \(B \cos (2\theta ) = 0\), and since \(B \neq 0\), this would force \(\cos (2\theta ) = 0\). Since no angle \(\theta \) can have both \(\sin (2\theta ) = 0\) and \(\cos (2\theta ) = 0\), we can safely assume \(\sin (2\theta ) \neq 0\).
Hence, we get \(\frac {\cos (2\theta )}{\sin (2\theta )} = \frac {A-C}{B}\), or \(\cot (2\theta ) = \frac {A-C}{B}\). We have just proved the following theorem.
We put Theorem rotatedconicthm to good use in the following example.
Since the equation \(5x^2+26xy+5y^2-16x\sqrt {2}+16y\sqrt {2}-104 = 0\) is already given to us in the form required by Theorem rotatedconicthm, we identify \(A = 5\), \(B = 26\) and \(C = 5\) so that \(\cot (2\theta ) = \frac {A-C}{B} = \frac {5-5}{26} = 0\).
This means \(\cot (2\theta ) = 0\) which gives \(\theta = \frac {\pi }{4} + \frac {\pi }{2} k\) for integers \(k\). We choose \(\theta = \frac {\pi }{4}\) so that our rotation equations are \(x = \frac {x' \sqrt {2}}{2} -\frac {y' \sqrt {2}}{2}\) and \(y = \frac {x' \sqrt {2}}{2} + \frac {y' \sqrt {2}}{2}\). The reader should verify that
Making the other substitutions, we get that \(5x^2+26xy+5y^2-16x\sqrt {2}+16y\sqrt {2}-104 = 0\) reduces to \(18(x')^2-8(y')^2+32y'-104 = 0\), or \(\frac {(x')^2}{4} -\frac {(y'-2)^2}{9} = 1\).
Hence, we have a hyperbola centered at the \(x'y'\)-coordinates \((0,2)\) opening in the \(x'\) direction with vertices \((\pm 2,2)\) (in \(x'y'\)-coordinates) and asymptotes \(y' = \pm \frac {3}{2} x' + 2\). We graph this equation below.

From \(16x^2+24xy+9y^2 +15x-20y = 0\), we get \(A = 16\), \(B=24\) and \(C = 9\) so that \(\cot (2\theta ) = \frac {7}{24}\). Since this isn’t one of the values of the common angles, we will need to use inverse functions.
Ultimately, we need to find \(\cos (\theta )\) and \(\sin (\theta )\), which means we have two options. If we use the arccotangent function immediately, after the usual calculations we get \(\theta = \frac {1}{2} \text {arccot}\left (\frac {7}{24}\right )\). To get \(\cos (\theta )\) and \(\sin (\theta )\) from this, we would need to use half angle identities.
Alternatively, we can start with \(\cot (2\theta ) = \frac {7}{24}\), use a double angle identity, and then go after \(\cos (\theta )\) and \(\sin (\theta )\). We adopt the second approach.
From \(\cot (2\theta ) = \frac {7}{24}\), we have \(\tan (2\theta ) = \frac {24}{7}\). Using the double angle identity for tangent, we have \(\frac {2\tan (\theta )}{1-\tan ^{2}(\theta )} = \frac {24}{7}\), which gives \(24 \tan ^{2}(\theta ) + 14 \tan (\theta ) - 24=0\).
Factoring, we get \(2(3\tan (\theta )+4)(4\tan (\theta )-3) = 0\) which gives \(\tan (\theta ) = -\frac {4}{3}\) or \(\tan (\theta ) = \frac {3}{4}\). While either of these values of \(\tan (\theta )\) satisfies the equation \(\cot (2\theta ) = \frac {7}{24}\), we choose \(\tan (\theta ) = \frac {3}{4}\), since this produces an acute angle, \(\theta = \arctan \left (\frac {3}{4}\right )\).
To find the rotation equations, we need \(\cos (\theta ) = \cos \left (\arctan \left (\frac {3}{4}\right )\right )\) and \(\sin (\theta ) = \sin \left (\arctan \left (\frac {3}{4}\right )\right )\). Using the techniques developed in Section TheInverseTrigonometricFunctions we get \(\cos (\theta ) = \frac {4}{5}\) and \(\sin (\theta ) = \frac {3}{5}\).
Our rotation equations are \(x = x' \cos (\theta ) - y' \sin (\theta ) = \frac {4x'}{5} - \frac {3y'}{5}\) and \(y = x' \sin (\theta ) + y'\cos (\theta ) = \frac {3x'}{5} + \frac {4y'}{5}\).
As usual, we now substitute these quantities into \(16x^2+24xy+9y^2 +15x-20y = 0\) and simplify. As a first step, the reader can verify
Once the dust settles, we get \(25(x')^2 - 25y' = 0\), or \(y' = (x')^2\), whose graph is a parabola opening along the positive \(y'\)-axis with vertex \((0,0)\). We graph this equation below.

Note that even though the coefficients of \(x^2\) and \(y^2\) were both positive numbers in parts rotatedhyperbolaex and rotatedparabolaex of Example graphrotatedconicex, the graph in part rotatedhyperbolaex turned out to be a hyperbola and the graph in part rotatedparabolaex worked out to be a parabola.
Whereas during our study of the conic sections, we could easily pick out which conic section we were dealing with based on the presence (or absence) of quadratic terms and their coefficients, Example graphrotatedconicex demonstrates the situation is much more complicated when an \(xy\) term is present.
Nevertheless, it is possible to determine which conic section we have by looking at a special, familiar combination of the coefficients of the quadratic terms. We have the following theorem.
Suppose the equation \(Ax^2 + Bxy + Cy^2 + Dx + Ey + F = 0\) describes a non-degenerate conic section.
As you may expect, the quantity \(B^2 - 4AC\) mentioned in Theorem conicclassification is called the discriminant of the conic section. While we will not attempt to explain the deep Mathematics which produces this ‘coincidence’, we will at least work through the proof of Theorem conicclassification mechanically to show that it is true.
First note that if the coefficient \(B=0\) in the equation \(Ax^2 + Bxy + Cy^2 + Dx + Ey + F = 0\), Theorem conicclassification reduces to the result presented in Exercise conicsclassificationnoxytermex in Section Hyperbolas.
Hence, we proceed under the assumption that \(B \neq 0\). We rotate the \(xy\)-axes counter-clockwise through an angle \(\theta \) which satisfies \(\cot (2\theta ) = \frac {A-C}{B}\) to produce an equation with no \(x'y'\)-term in accordance with Theorem rotatedconicthm: \(A'(x')^2 +C(y')^2 + Dx' + Ey' + F'= 0\).
In this form, we can invoke Exercise conicsclassificationnoxytermex in Section Hyperbolas once more using the product \(A'C'\). Our goal is to find the product \(A'C'\) in terms of the coefficients \(A\), \(B\) and \(C\) in the original equation.
We substitute \(x = x' \cos (\theta ) - y' \sin (\theta )\) \(y = x'\sin (\theta ) + y'\cos (\theta )\) into \(Ax^2 + Bxy + Cy^2 + Dx + Ey + F = 0\). After gathering like terms, the coefficient \(A'\) on \((x')^2\) and the coefficient \(C'\) on \((y')^2\) are
In order to make use of the condition \(\cot (2\theta ) = \frac {A-C}{B}\), we rewrite our formulas for \(A'\) and \(C'\) using the power reduction formulas. After some regrouping, we get
Next, we try to make sense of the product
We break this product into pieces. First, we use the difference of squares to multiply the ‘first’ quantities in each factor to get
Next, we add the product of the ‘outer’ and ‘inner’ quantities in each factor to get
The product of the ‘last’ quantity in each factor is \((B\sin (2\theta ))(- B\sin (2\theta )) = -B^2\sin ^2(2\theta )\).
Putting all of this together yields
From \(\cot (2\theta ) = \frac {A-C}{B}\), we get \(\frac {\cos (2\theta )}{\sin (2\theta )} = \frac {A-C}{B}\), or \((A-C)\sin (2\theta )=B\cos (2\theta )\).
Using this substitution twice along with the Pythagorean Identity \(\cos ^{2}(2\theta ) = 1 - \sin ^{2}(2\theta )\) we get:
Hence, \(B^2 - 4AC = -4 A'C'\), so the quantity \(B^2 - 4AC\) has the opposite sign of \(A'C'\). The result now follows by applying Exercise conicsclassificationnoxytermex in Section Hyperbolas.
Here, we revisit the conic sections from a more unified perspective starting with a ‘new’ definition below.
The line \(L\) is called the directrix of the conic section, the point \(F\) is called a focus of the conic section, and the constant \(e\) is called the eccentricity of the conic section.
We have seen the notions of focus and directrix before in the definition of a parabola, Definition paraboladefn. There, a parabola is defined as the set of points equidistant from the focus and directrix, giving an eccentricity \(e = 1\) according to Definition focusdirectrixeccentrityconic.
We have also seen the concept of eccentricity before. It was introduced for ellipses in Definition ellipseeccentricity in Section Ellipses, and later extended to hyperbolas in Exercise hyperbolaeccentricity in Section Hyperbolas. There, \(e\) was also defined as a ratio of distances, though in these cases the distances involved were measurements from the center to a focus and from the center to a vertex.
One way to reconcile the ‘old’ ideas of focus, directrix and eccentricity with the ‘new’ ones presented in Definition focusdirectrixeccentrityconic is to derive equations for the conic sections using Definition focusdirectrixeccentrityconic and compare these parameters with what we know from our previous experience with the conics.
We begin by assuming the conic section has eccentricity \(e\), a focus \(F\) at the origin and that the directrix is the vertical line \(x = -d\) as in the figure below.
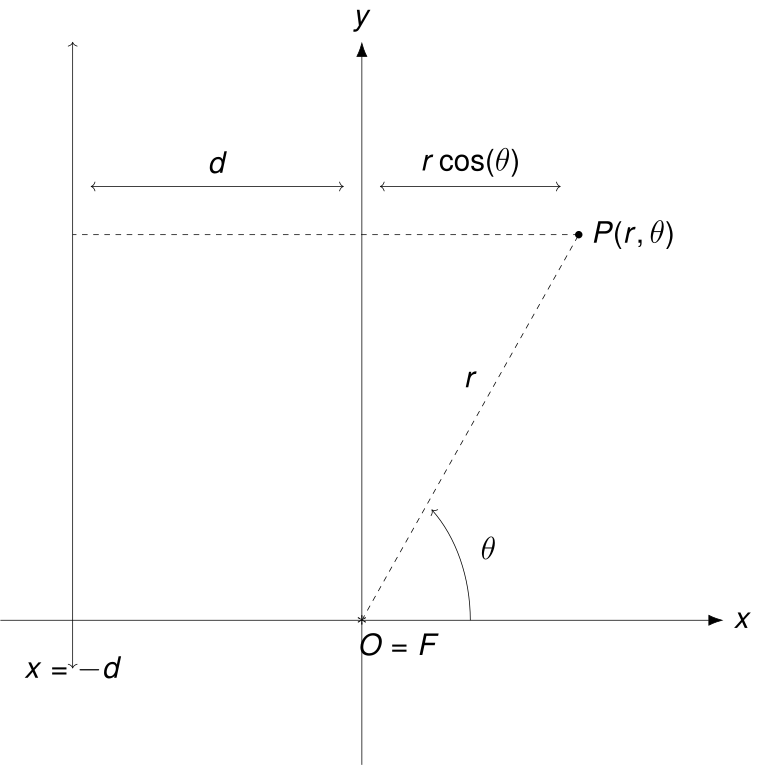
Using a polar coordinate representation \(P(r,\theta )\) for a point on the conic with \(r > 0\), we get
so that \(r = e(d+r\cos (\theta ))\). Solving this equation for \(r\), yields
At this point, we convert the equation \(r = e(d+r\cos (\theta ))\) back into a rectangular equation in the variables \(x\) and \(y\). If \(e > 0\), but \(e\neq 1\), the usual conversion process outlined in Section PolarCoordinates gives
If \(0 < e < 1\), then \(0< 1-e^2 < 1\) and, hence, \((1-e^2)^2 < 1-e^2\). We leave it to the reader to show that this means we have the equation of an ellipse centered at \(\left (\frac {e^2 d}{1-e^2}, 0\right )\) with major axis along the \(x\)-axis.
Using the notation from Section Ellipses, we have \(a^2 = \frac {e^2 d^2}{\left (1-e^2\right )^2}\) and \(b^2 = \frac {e^2 d^2}{1-e^2}\), so the major axis has length \(\frac {2ed}{1-e^2}\) and the minor axis has length \(\frac {2ed}{\sqrt {1-e^2}}\).
Moreover, we find that one focus is \((0,0)\) and working through the formula given in Definition ellipseeccentricity gives the eccentricity to be \(e\), as required.
If \(e > 1\), then \(1 - e^2 < 0\) but \((1-e^2)^2 > 0\) so the equation generates a hyperbola with center \(\left (\frac {e^2 d}{1-e^2}, 0\right )\) whose transverse axis lies along the \(x\)-axis.
Since such hyperbolas have the form \(\frac {(x-h)^2}{a^2} -\frac {y^2}{b^2} = 1\), we need to take the opposite reciprocal of the coefficient of \(y^2\) to find \(b^2\).
Doing this, we obtain \(a^2 = \frac {e^2 d^2}{\left (1-e^2\right )^2} = \frac {e^2d^2}{\left (e^2-1\right )^2}\) and \(b^2 = -\frac {e^2 d^2}{1-e^2} = \frac {e^2d^2}{e^2-1}\), so the transverse axis has length \(\frac {2ed}{e^2-1}\) and the conjugate axis has length \(\frac {2ed}{\sqrt {e^2-1}}\).
Additionally, we verify that one focus is at \((0,0)\), and the formula given in Exercise hyperbolaeccentricity in Section Hyperbolas gives the eccentricity is \(e\) in this case as well.
If \(e=1\), the equation \(r = \frac {ed}{1-e\cos (\theta )}\) reduces to \(r = \frac {d}{1-\cos (\theta )}\) which translates to \(y^2 = 2d\left (x + \frac {d}{2}\right )\).
The equation \(y^2 = 2d\left (x + \frac {d}{2}\right )\) describes a parabola with vertex \(\left (-\frac {d}{2}, 0\right )\) opening to the right.
In the language of Section Parabolas, \(4p = 2d\) so \(p = \frac {d}{2}\), the focus is \((0,0)\), the focal diameter is \(2d\) and the directrix is \(x = -d\), as required.
Hence, we have shown that in all cases, our ‘new’ understanding of ‘conic section’, ‘focus’, ‘eccentricity’ and ‘directrix’ as presented in Definition focusdirectrixeccentrityconic correspond with the ‘old’ definitions we’ve seen previously.
Before we summarize our findings, we note that in order to arrive at our general equation of a conic \(r = \frac {ed}{1-e\cos (\theta )}\), we assumed that the directrix was the line \(x = -d\) for \(d > 0\).
We could have just as easily chosen the directrix to be \(x = d\), \(y = -d\) or \(y = d\). As the reader can verify, in these cases we obtain the forms \(r = \frac {ed}{1+e\cos (\theta )}\), \(r = \frac {ed}{1-e\sin (\theta )}\) and \(r = \frac {ed}{1+e\sin (\theta )}\), respectively.
The key thing to remember is that in any of these cases, the directrix is always perpendicular to the major axis of an ellipse and it is always perpendicular to the transverse axis of the hyperbola.
For parabolas, knowing the focus is \((0,0)\) and the directrix also tells us which way the parabola opens.
We have established the following theorem.
In each case above, \((0,0)\) is a focus of the conic and the number \(e\) is the eccentricity of the conic.
We test out Theorem polarformofconicsthm in the next example.
From \(r = \frac {4}{1-\sin (\theta )}\), we first note \(e =1\) which means we have a parabola on our hands.
Since \(ed = 4\), we have \(d=4\) and given the form of the equation, the directrix at \(y = -4\).
Since the focus is at \((0,0)\), we know that the vertex is located at the point (in rectangular coordinates) \((0,-2)\) and must open upwards.
With \(d=4\), we have a focal diameter of \(2d = 8\), so the parabola contains the points \((\pm 4, 0)\).
Putting all this together, we graph \(r = \frac {4}{1-\sin (\theta )}\) below.

We first rewrite \(r = \frac {12}{3 - \cos (\theta )}\) in the form found in Theorem polarformofconicsthm, namely \(r = \frac {4}{1 - (1/3) \cos (\theta )}\).
Since \(e = \frac {1}{3}\) satisfies \(0 < e < 1\), we know that the graph of this equation is an ellipse.
Since \(ed= 4\), we have \(d = 12\) and, based on the form of the equation, the directrix is \(x = -12\).
Hence, the ellipse has its major axis along the \(x\)-axis, which means we can find the vertices of the ellipse by finding where the ellipse intersects the \(x\)-axis.
Since \(r(0) = 6\) and \(r(\pi ) = 3\), our vertices are the rectangular points \((-3,0)\) and \((6,0)\).
The center of the ellipse is the midpoint of the vertices, which in this case is \(\left (\frac {3}{2}, 0\right )\).
We know one focus is \((0,0)\), which is \(\frac {3}{2}\) from the center \(\left (\frac {3}{2}, 0\right )\) and this allows us to find the other focus \((3, 0)\), even though we are not asked to do so.
Finally, we know from Theorem polarformofconicsthm that the length of the minor axis is \(\frac {2ed}{\sqrt {1-e^2}} =\) \(\frac {4}{\sqrt {1-(1/3)^2}}\) \(= 6\sqrt {3}\) which means the endpoints of the minor axis are \(\left (\frac {3}{2}, \pm 3\sqrt {2}\right )\).
We now have everything we need to graph \(r = \frac {12}{3 - \cos (\theta )}\) below.

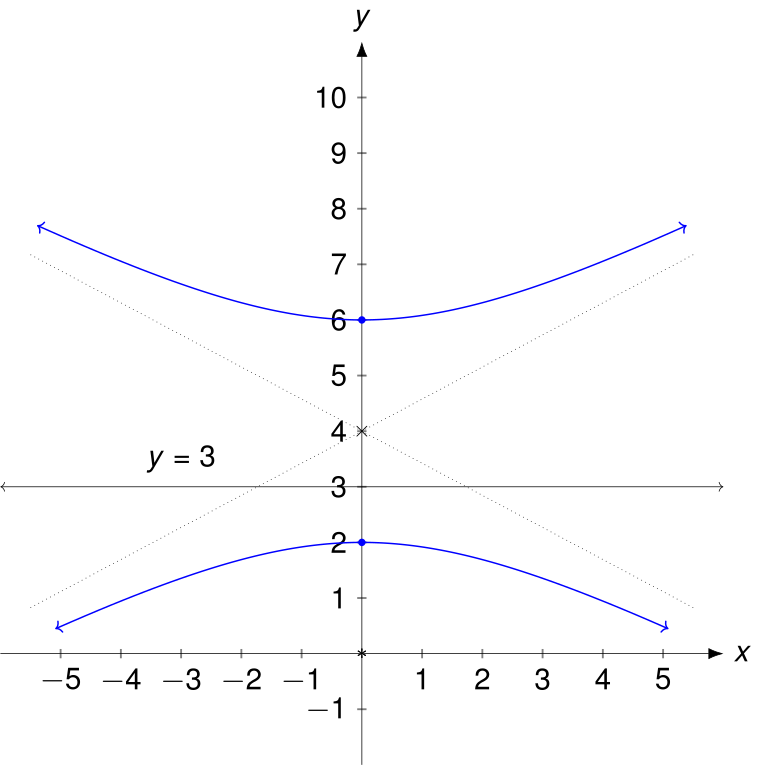
From \(r = \frac {6}{1 + 2\sin (\theta )}\) we get \(e = 2 > 1\) so the graph is a hyperbola.
Since \(ed = 6\), we get \(d=3\), and from the form of the equation, we know the directrix is \(y = 3\).
Hence, the transverse axis of the hyperbola lies along the \(y\)-axis, so we can find the vertices by looking where the hyperbola intersects the \(y\)-axis.
We find \(r\left ( \frac {\pi }{2} \right ) = 2\) and \(r\left (\frac {3\pi }{2}\right ) = -6\). These two points correspond to the rectangular points \((0,2)\) and \((0,6)\) which puts the center of the hyperbola at \((0,4)\).
Since one focus is at \((0,0)\), \(4\) units away from the center, we know the other focus is at \((0,8)\).
According to Theorem polarformofconicsthm, the conjugate axis has a length of \(\frac {2ed}{\sqrt {e^2-1}} = \frac {(2)(6)}{\sqrt {2^2-1}} = 4 \sqrt {3}\). This together with the location of the vertices give the slopes of the asymptotes as: \(\pm \frac {2}{2\sqrt {3}} = \pm \frac {\sqrt {3}}{3}\).
Since the center of the hyperbola is \((0,4)\), the asymptotes are \(y = \pm \frac {\sqrt {3}}{3} x + 4\).
Using all of our work, we graph the hyperbola below.
In light of Section rotationaxes, the reader may wonder what the rotated form of the conic sections would look like in polar form.
We know from Exercise polargraphtransformations in Section PolarGraphs that replacing \(\theta \) with \((\theta - \phi )\) in an expression \(r = f(\theta )\) rotates the graph of \(r = f(\theta )\) counter-clockwise by an angle \(\phi \).
For instance, to graph \(r = \frac {4}{1-\sin \left (\theta - \frac {\pi }{4}\right )}\) all we need to do is rotate the graph of \(r = \frac {4}{1-\sin \left (\theta \right )}\), which we obtained in Example polarconicgraphex number polarparabola, counter-clockwise by \(\frac {\pi }{4}\) radians, as shown below.

Using rotations, we can greatly simplify the form of the conic sections presented in Theorem polarformofconicsthm, since any three of the forms given there can be obtained from the fourth by rotating through some multiple of \(\frac {\pi }{2}\).
Moreover, since rotations do not affect lengths, all of the formulas for lengths Theorem polarformofconicsthm remain intact.
The formula in Theorem mostgeneralpolarformconic below captures all the conic sections that have a focus at \((0,0)\). It also includes circles centered at the origin by extending the concept of eccentricity to include \(e=0\).
While substituting \(e=0\) into the equation given in Theorem mostgeneralpolarformconic quickly reduces to a circle centered at the origin, the reader is best advised to think about this idea in light of Definition ellipseeccentricity in Section Ellipses.